
Introduction
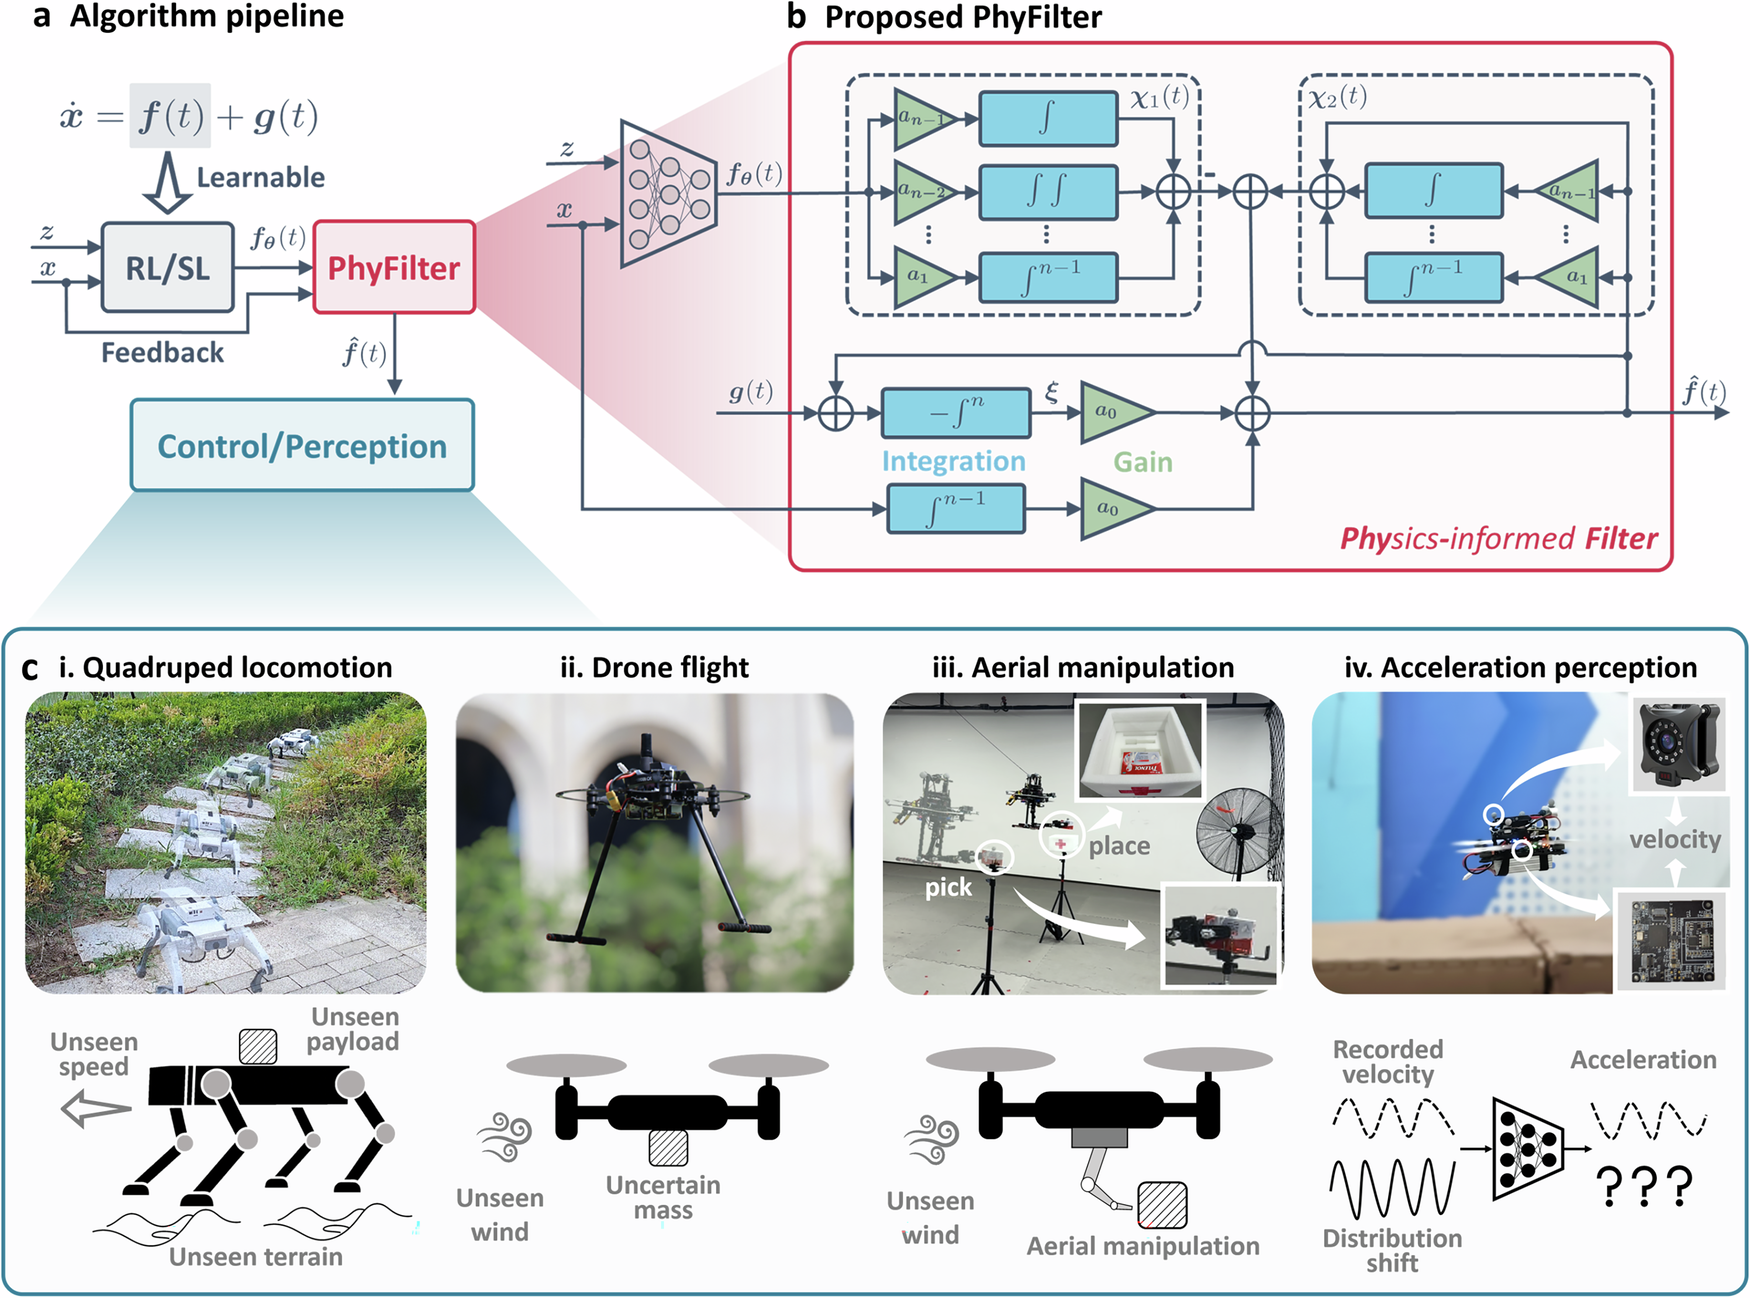
A paper published in npj Robotics on September 4 proposes PhyFilter. The method adds a physics-based correction to the output of an existing learned model when the robot encounters conditions outside its training distribution.
The authors test it across quadruped locomotion, drone flight, aerial manipulation and acceleration estimation. They report real-time execution on an STM32F765 at 500 Hz in the aerial cases.
Source review date recorded for this article September 14, 2026.
The correction sits outside the learned policy
PhyFilter uses known differential structure plus live state feedback to estimate a residual correction. The paper presents it as a plug-in module that can work with pretrained policies without retraining the network.
That architecture supports before-and-after comparisons under the same disturbance.
Tests include conditions excluded from training
The reported experiments include terrain, payload and speed changes for locomotion plus wind and mass uncertainty for aerial systems. In one drone experiment, the paper reports mean absolute tracking error reductions of 30.22% relative to SEER-I and 50.17% relative to the baseline under combined mass and wind uncertainty.
For aerial manipulation, the authors report a maximum manipulation error of 2.5 cm under 5 m/s wind and 0.3 kg mass uncertainty, with average and variance improvements of 23.99% and 55.04% over baseline. These are paper results under the stated tests, not universal guarantees.
Small processors are relevant for deployment
Running at 500 Hz on an STM32F765 shows that the correction equations fit on a resource-constrained controller in the tested setup.
Deployment still needs bounds for bad sensors, incorrect physical parameters and actuator saturation.
Limitations and missing information
- The paper's claims apply to its tested systems and disturbance ranges.
- The Nature article carries its own reuse license for figures and third-party material.
Conclusion
PhyFilter is a useful example of combining learned policies with explicit robot physics when deployment conditions move outside the training set.
Sources and methodology
Share this article
Share the current TechniaHQRobot article page.
Continue reading
Open the latest robotics reporting, Physical AI analysis and hardware notes.