Robotics news

Robotics News

Browse dated robotics reports, deployment analysis and technical guides. Each article states its own topic and publication date.

335 articles

Robotics conferences

IROS 2026 in Pittsburgh runs September 27 through October 1

IROS 2026 runs September 27 through October 1 at the David L. Lawrence Convention Center in Pittsburgh. This guide covers the verified conference details and a practical way to evaluate robotics papers and demos.

Read article
Perceptron Mk1.5 launch visual from Perceptron
Embodied AI models

Perceptron Mk1.5 brings audio, video tracking and tool use to embodied agents

Perceptron Mk1.5 adds native audio, video object tracking, web tools and sub-agents while cutting end-to-end latency by up to 4.7x in company tests.

Read article
Humanoid robot manufacturing

UBTECH's Liuzhou factory targets one humanoid robot every 10 minutes

UBTECH's new Liuzhou plant targets more than 10,000 industrial humanoids per year. We examine takt time, automation and what factory capacity does not prove.

Read article
Humanoid robot market

Unitree appeared in one third of China's August embodied-robot tenders

Public tender data shows Unitree products in 55 procurement orders and 136 mid/full-size robots. We separate research demand from commercial deployment.

Read article
Robotics finance

China is scrutinizing humanoid robot IPOs more closely

Chinese regulators are applying more scrutiny to humanoid robot IPO candidates. We examine revenue quality, state-backed projects and deployment evidence.

Read article
Embodied AI training

Inside Beijing's Shijingshan robot school for real-world humanoid training

Beijing's Shijingshan center links capture, reconstruction, simulation, training, hardware validation and deployment. We map the full data loop.

Read article
Physical AI data

Beijing's cross-embodiment center tries to reuse one human motion across many robots

A Haidian training center records human motion for reuse across different robot bodies. We examine retargeting, calibration and transfer tests.

Read article
Embodied AI standards

China is preparing data standards for embodied AI

China's National Data Administration says it will advance embodied AI data standards. We map the fields that affect reuse, quality and safety.

Read article
Humanoid robot launches

Zhicheng TR6 targets sorting and inspection with multimodal perception

Zhicheng Robot unveiled the full-size TR6 humanoid in Hangzhou with multimodal perception and end-to-end AI for sorting and inspection tasks.

Read article
Robot hands

Recent Chinese dexterous-hand showcases put tactile sensing and force control in focus

Recent INSPIRE and Xynova showcases highlight tactile sensing, force control and factory-oriented manipulation. This guide compares measurements that matter beyond DOF counts.

Read article
Physical AI data

Maniformer MEgo reaches 20,000 devices and one million hours of Physical AI data

Maniformer says 20,000 MEgo devices have produced more than one million hours of real-world data. We examine coverage, transfer value and quality checks.

Read article
Embodied AI models

Spirit AI says general robot brains could reach a new stage in 2027

Spirit AI says general-purpose robot control from verbal instructions could advance in 2027. We examine Moz1, real-world data and the evidence behind the claim.

Read article
AgiBot A3 humanoid robot used as visual context for the A3 Ultra production milestone
Humanoid robot manufacturing

AgiBot's 20,000th robot puts production speed under the microscope

AGIBOT says the 20,000th robot to roll off its production line was an A3 Ultra delivered to Chimelong. This article traces the reported production milestones and keeps production separate from deployment evidence.

Read article
AgiBot humanoid robot representing one part of the multi-model Chimelong robot deployment
Robot deployments

What 300+ AgiBot robots at Chimelong can reveal about public-space robotics

More than 300 AgiBot robots are entering regular work across 100+ interaction points at Chimelong. We map the deployment tests that count.

Read article
Unitree G1 humanoid robot used as visual context for the G1 Plus hardware update
Humanoid robot launches

Unitree G1+ vs G1: hardware changes and battery limits

Compare Unitree's G1 and G1+ hardware: extra neck joints, motor claims, sensing changes and the unchanged published battery rating.

Read article
Unitree G1 humanoid robot shown as visual context for Unitree's UnifoLM world-model research
World models for robotics

Unitree UnifoLM-X2-1.0 turns humanoid fighting into a latency and recovery test

Unitree's UnifoLM-X2-1.0 fighting announcement claims autonomous world-model control. The control mode, latency and repeatability remain unverified.

Read article
Personal robots

PrimeBOT Q1 vs T1: two RMB 19,999 personal robots with different mobility

PrimeBOT's Q1 and T1 both start at RMB 19,999 in China. We compare size, motion, customization, SDK access and the claims buyers should test.

Read article
Video still from the Maxinsights post about egocentric human experience data
Robot training data

Maxinsights Reports 2 Million Hours of Human Experience Data

Maxinsights says it has recorded 2 million hours of egocentric human experience. The figure gives the scale of collection. To judge its value for robot learning, we also need to know which tasks, objects, contacts and recovery attempts those hours contain.

Read article
LinkerBot hand footage in the TechniaHQRobot video compilation
Dexterous robot hands

LinkerBot Robot Hands Put Finger Coordination in Focus

The LinkerBot compilation shared by TechniaHQRobot covers small-part handling, food manipulation and grasps on objects with different shapes. Those tasks draw attention to finger placement, contact and release, as well as how much force a hand can apply.

Read article
HojoAI image accompanying its call for difficult speech samples
Speech recognition for robotics

Hojo-ASR-Multi-V1 and a Test Plan for Everyday Speech

HojoAI is asking for difficult speech samples to test Hojo-ASR-Multi-V1. TechniaHQRobot proposed starting with English and French in the same recording. That is a useful test question, with language support and error handling to check before drawing conclusions.

Read article
Still from Aze Alter's Age of Beyond video shared in the future discussion
Robotics opinion

A Robot Future Needs Evidence Before a Timeline

On September 20, TechniaHQRobot responded skeptically to a future-themed video shared by Elon Musk. The response doubted that such a future would arrive within 50 or even 100 years. Those numbers express an opinion. The exchange supplies no measured basis for a delivery date.

Read article
AGIBOT A3 humanoid robot shown from the front
Human-robot interaction

AGIBOT A3 joins the conversation on stage in Macao

AGIBOT A3 joined celebrities at the Greater Bay Area Film Concert in Macao. AGIBOT describes an exchange in which the robot followed the conversation in real time and coordinated its speech with movements and expressions through WITA-Omni.

Read article
TechniaHQRobot table showing the job records needed to compare industrial robot maintenance costs
Industrial robotics

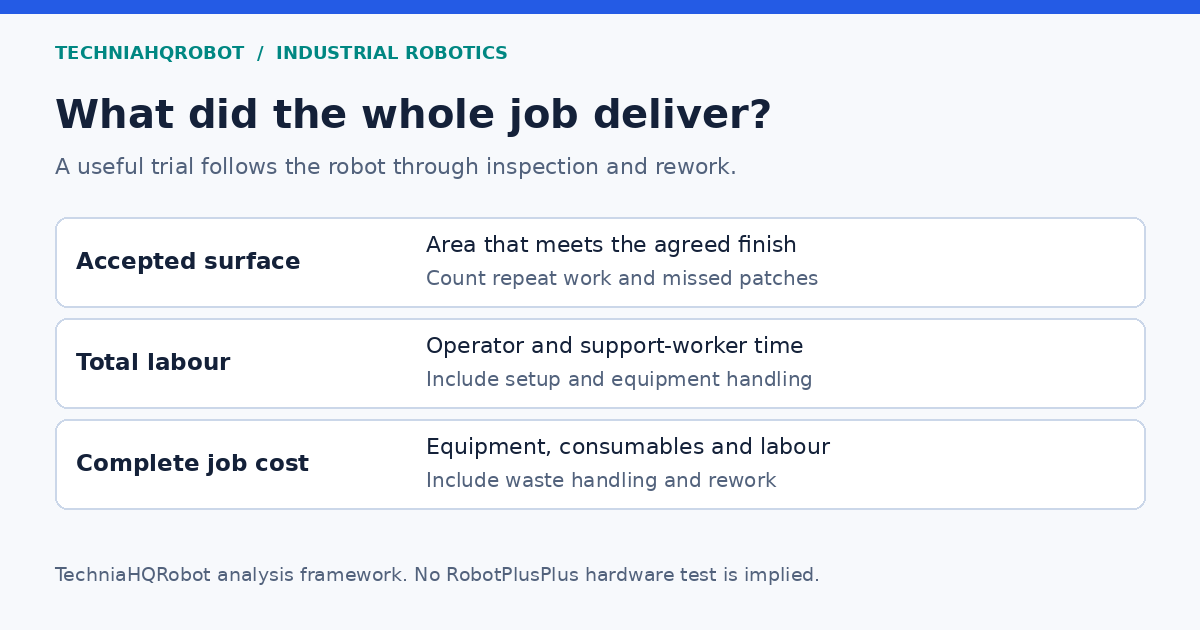
RobotPlusPlus puts its Series C behind work at height

RobotPlusPlus outlines plans for its Series C funding. We trace the announcement dates and examine what its wall-climbing robots mean for industrial maintenance.

Read article
TechniaHQRobot diagram comparing an ideal Digit 5 charge cycle with an assumed six-minute delay
Humanoid robot launches

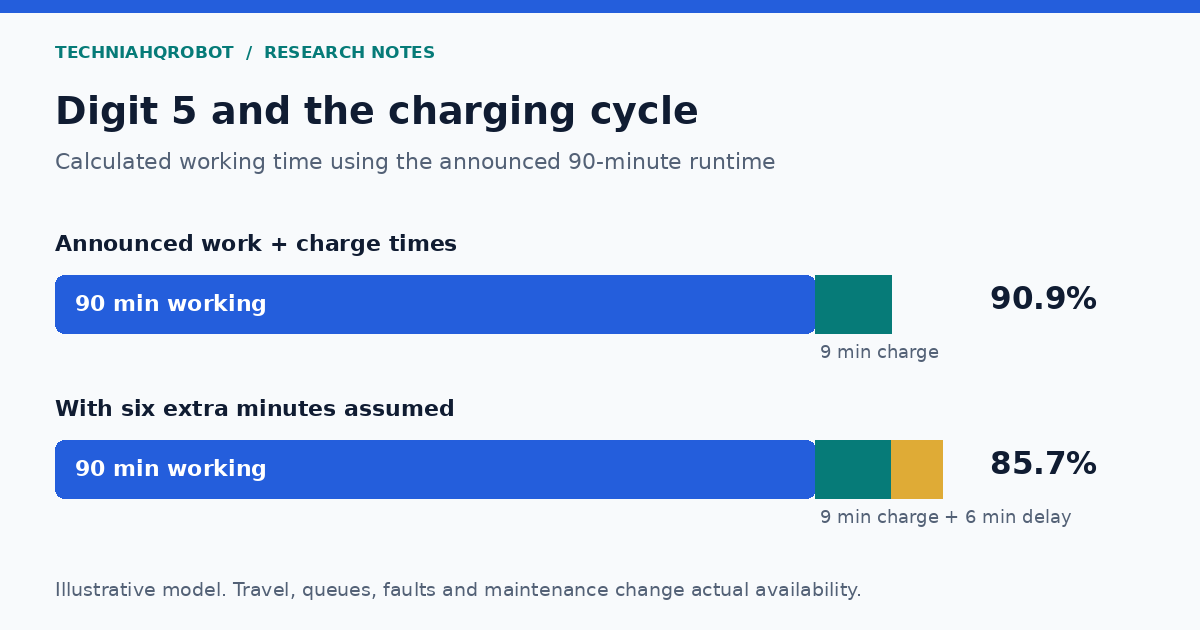
Digit 5 pairs a 50 lb lift with nine-minute charging

Agility Robotics introduces Digit 5 with a 22.7 kg repeated lift and a 90-minute work, nine-minute charge cycle. We examine the duty-cycle claim and its limits.

Read article
Original chart of Dynin-Robotics and pi0.5 success percentages on ordinary and color-ordered cube stacking
Robot learning research

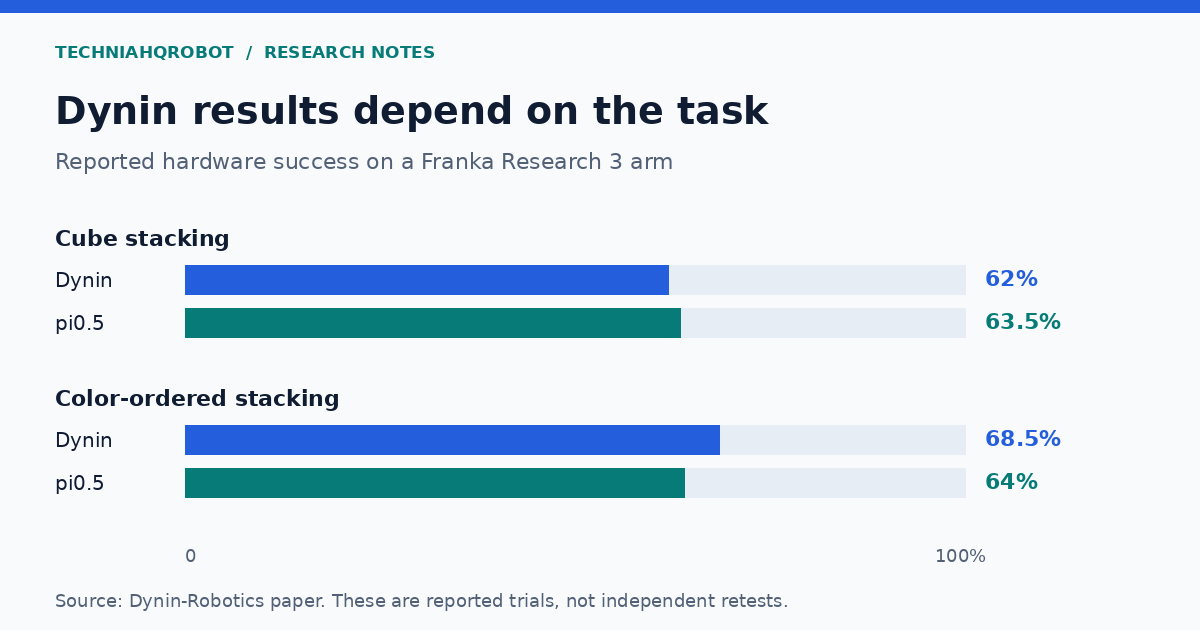
Dynin-Robotics puts diffusion control through four Franka tasks

Dynin-Robotics reports a 78.4 percent average across four real robot tasks. Its task-level results reveal where the diffusion model gains and where it trails other policies.

Read article
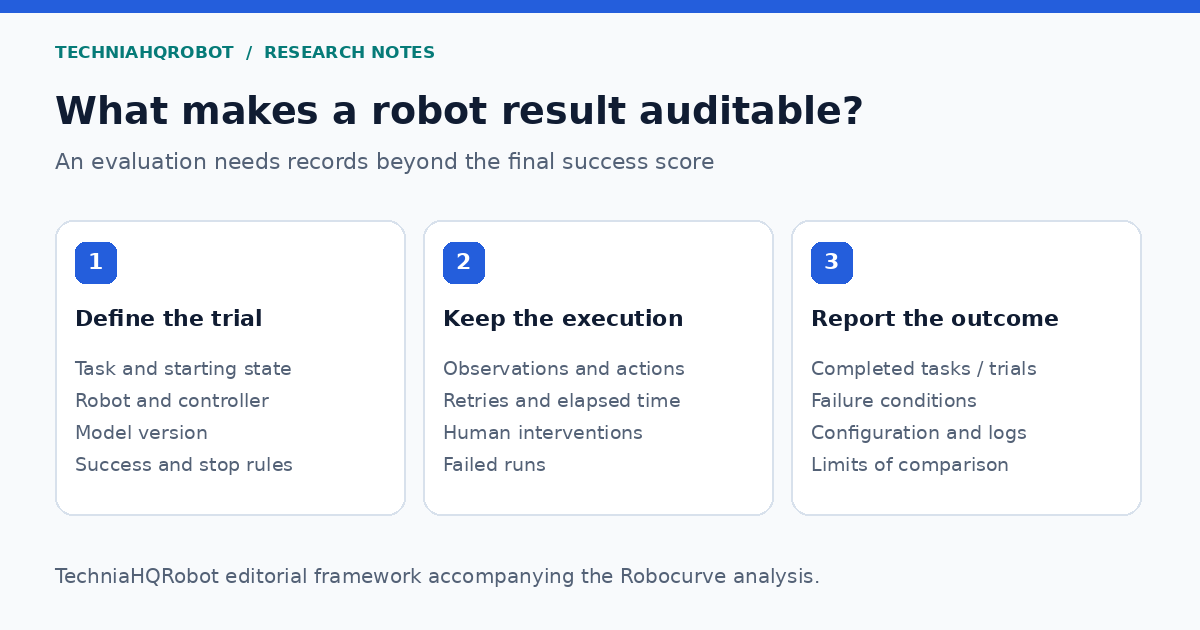
TechniaHQRobot checklist diagram of task conditions, execution records and results for a reproducible robot evaluation
Physical AI evaluation

Robocurve raises $10 million for independent Physical AI evaluation

Robocurve's September 14 seed round funds robot evaluation and open benchmarks. We examine Inspect Robots and what makes a model comparison useful.

Read article
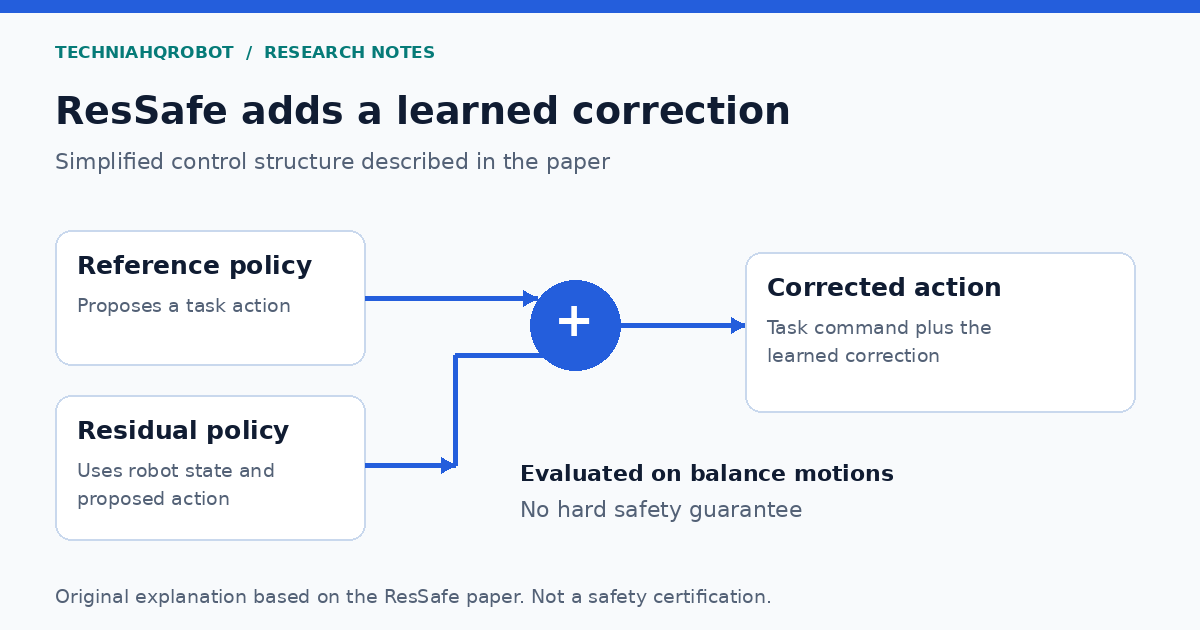
TechniaHQRobot diagram of a reference robot action combined with a learned residual correction
Humanoid control research

ResSafe studies a separate learned correction for humanoid balance

ResSafe adds a residual policy to a humanoid motion controller. The reported hardware trials show fewer falls overall, with important task-level and safety limits.

Read article
Boston Dynamics electric Atlas humanoid robot
Humanoid robotics business

Boston Dynamics IPO looks later as Atlas manufacturing becomes the nearer test

A Hyundai executive says a Boston Dynamics IPO is unlikely in 2027 while Atlas still has to move from limited deployments toward repeatable manufacturing and factory use.

Read article
Unitree G1 humanoid robot
Humanoid foundation models

UnifoLM-WLA-1.0: what its action interface means for robot integration

Read Unitree's released action/state layout: masked hardware slots, action-chunk timing and different leg offsets in the state and action vectors.

Read article
AGIBOT robot performing a real-world manipulation task
World-action models

AGIBOT GE-Act 2.0 tests a world-action model across 100 unseen robot tasks

AGIBOT says GE-Act 2.0 is trained from random initialization on embodied manipulation data then evaluated zero-shot across 100 atomic tasks and two robot embodiments.

Read article
Noetix Scalabot HERON world model research
Robot world models

Noetix HERON predicts how a robot action may change the scene before execution

Noetix Robotics has published HERON-World Model results on WorldArena 1.0 with an overall EWMScore_P of 75.80 and action-conditioned future prediction.

Read article
Compact humanoid robot used as visual context for open-source humanoid research
Open-source humanoids

BRIDGE co-designs humanoid body shape and control around human motion data

BRIDGE is an open-source 88 cm humanoid platform whose authors optimize morphology and control together for retargeting and dynamic motion tracking.

Read article
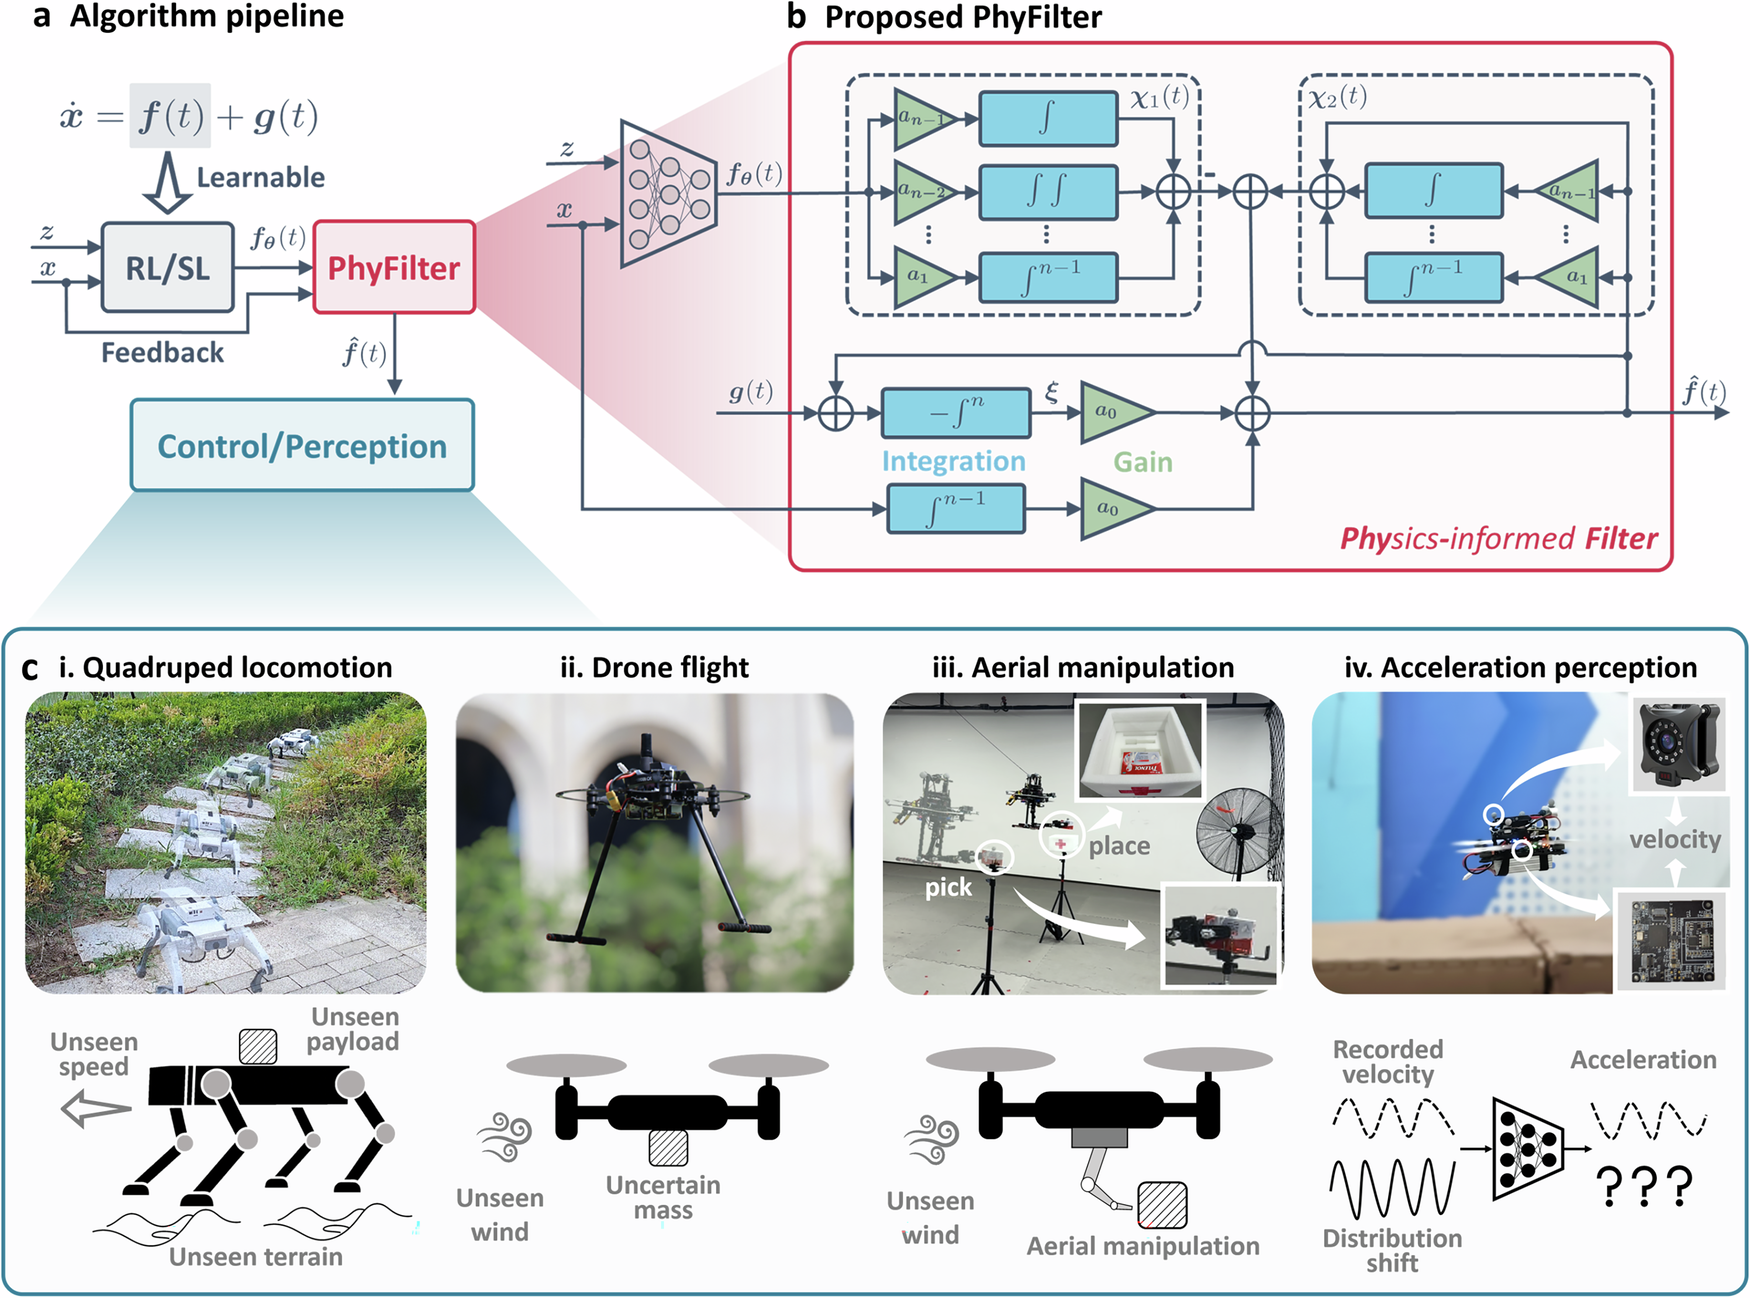
PhyFilter tests across quadruped locomotion and aerial robotics
Robot learning

PhyFilter uses robot physics to correct learned policies when conditions change

A September npj Robotics paper reports a model-agnostic physics filter tested on quadrupeds, drones, aerial manipulation and acceleration estimation under unseen conditions.

Read article
FANUC automated production cell with robot and CNC equipment
Industrial Physical AI

FANUC brings Physical AI into machining and robot cells at IMTS 2026

FANUC's IMTS 2026 program links robot vision, force sensing, CNC systems and AI-driven automation in production cells.

Read article
NVIDIA and Hugging Face acquisition visual
AI infrastructure

NVIDIA's $12.93B Hugging Face deal reaches into open robotics through LeRobot

NVIDIA agreed to acquire Hugging Face for $12.93 billion while saying the platform will remain open across models, clouds and compute providers. Hugging Face also hosts the LeRobot robotics stack.

Read article
Skild AI robot performing a multistep manipulation task
Robot foundation models

Skild S1 learns new multistep robot tasks from one video without task-specific retraining

Skild AI says S1 can use one video demonstration as context for unseen tasks lasting up to 10 minutes without updating model weights.

Read article
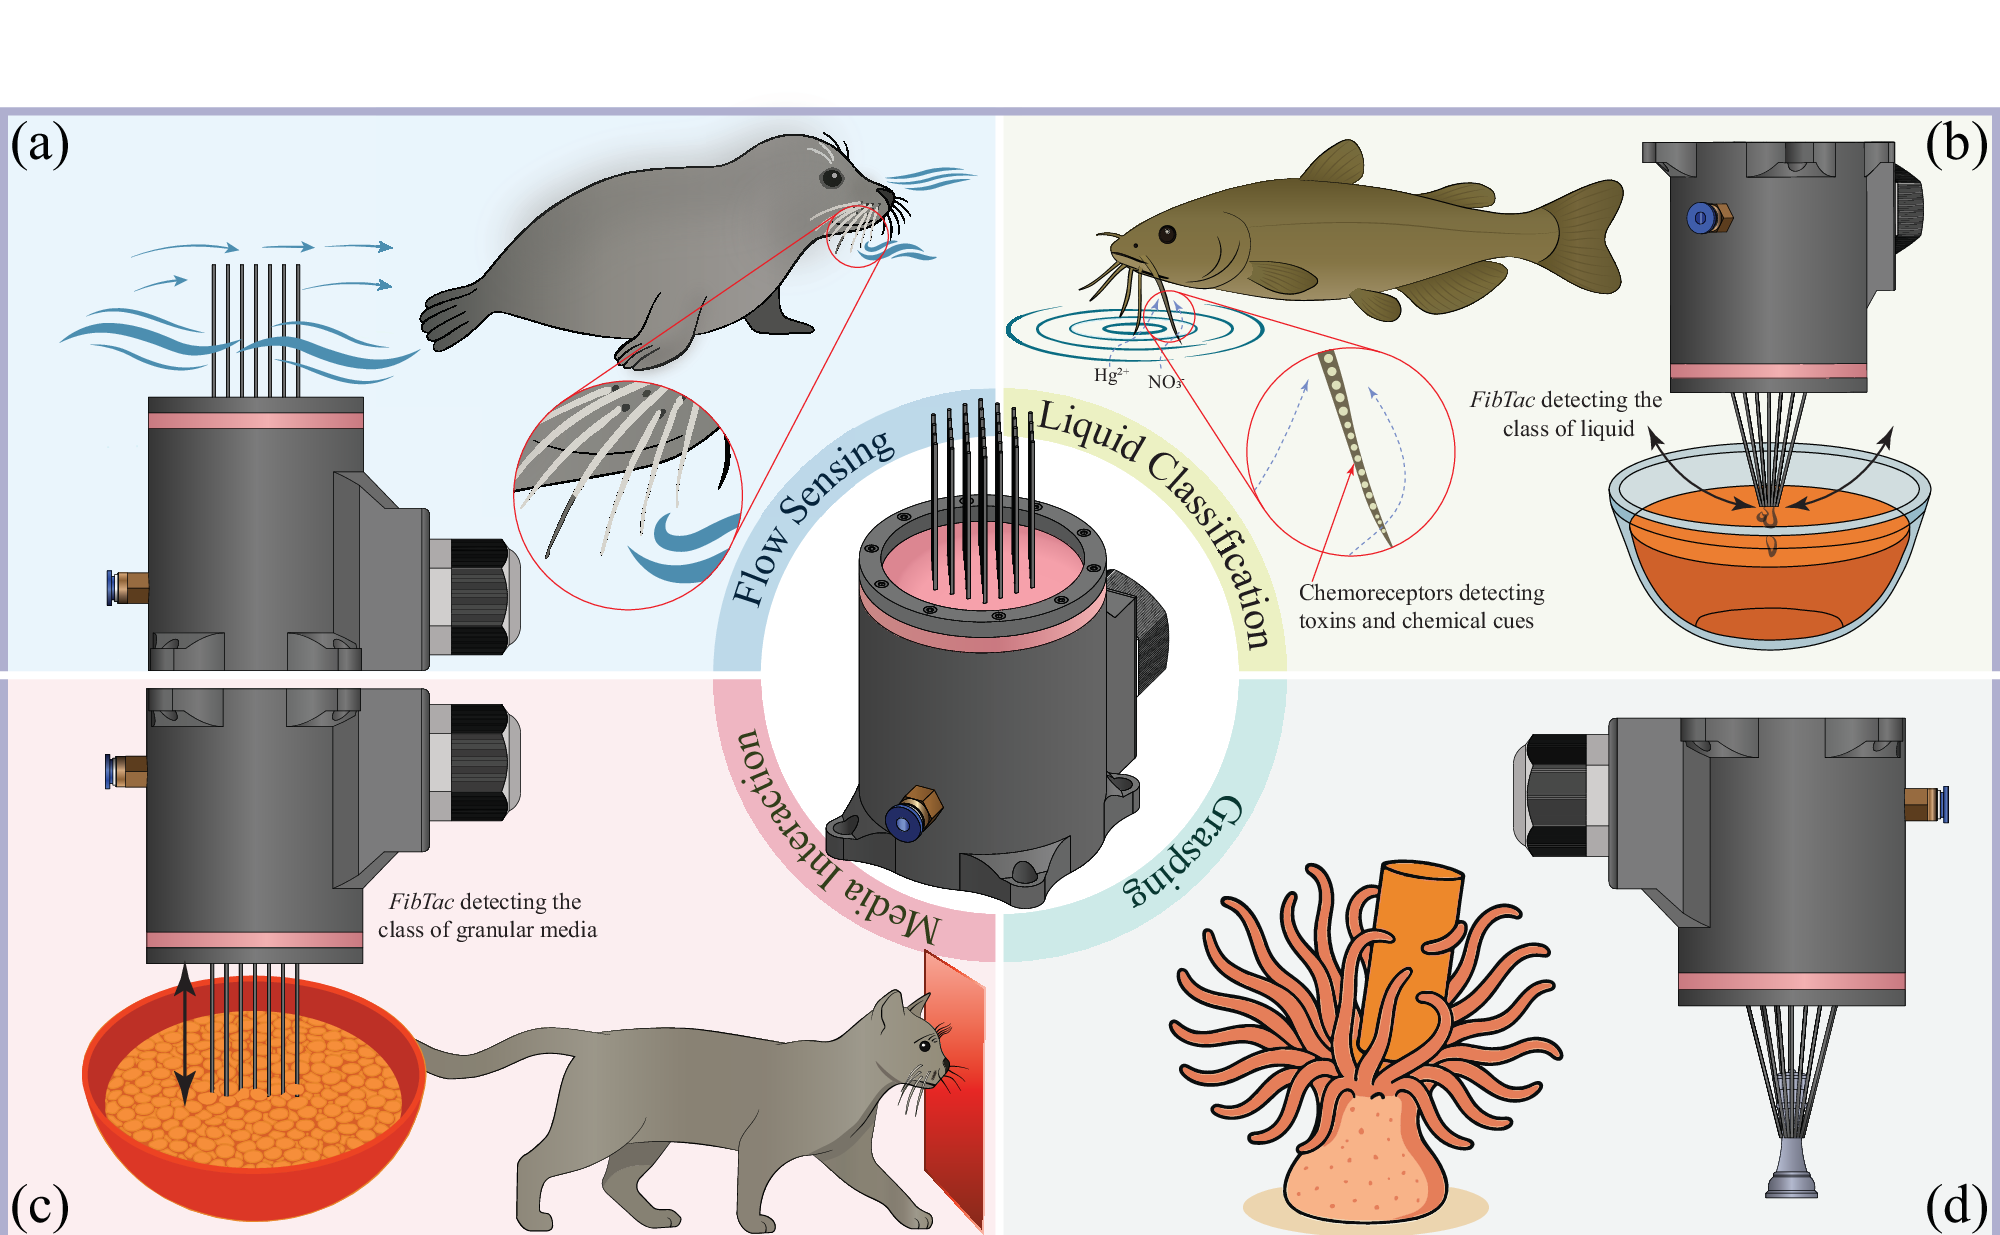
FibTac fiber-based pneumatic gripper with tactile sensing
Tactile robotics

FibTac turns the same soft fibers into a robot gripper and tactile sensor

FibTac combines pneumatic grasping with camera-tracked fiber deformation. The npj Robotics paper reports a 186 gram payload, more than 3,000 actuation cycles and tactile perception tests in air and underwater.

Read article
Contact-rich manipulation experiments with the FWBC-VLA robot
Contact control

FWBC-VLA and the Problem of Knowing Where a Force Comes From

How FWBC-VLA uses joint signals during door opening and wiping, what its wheeled-legged tests show, and how to test force attribution.

Read article
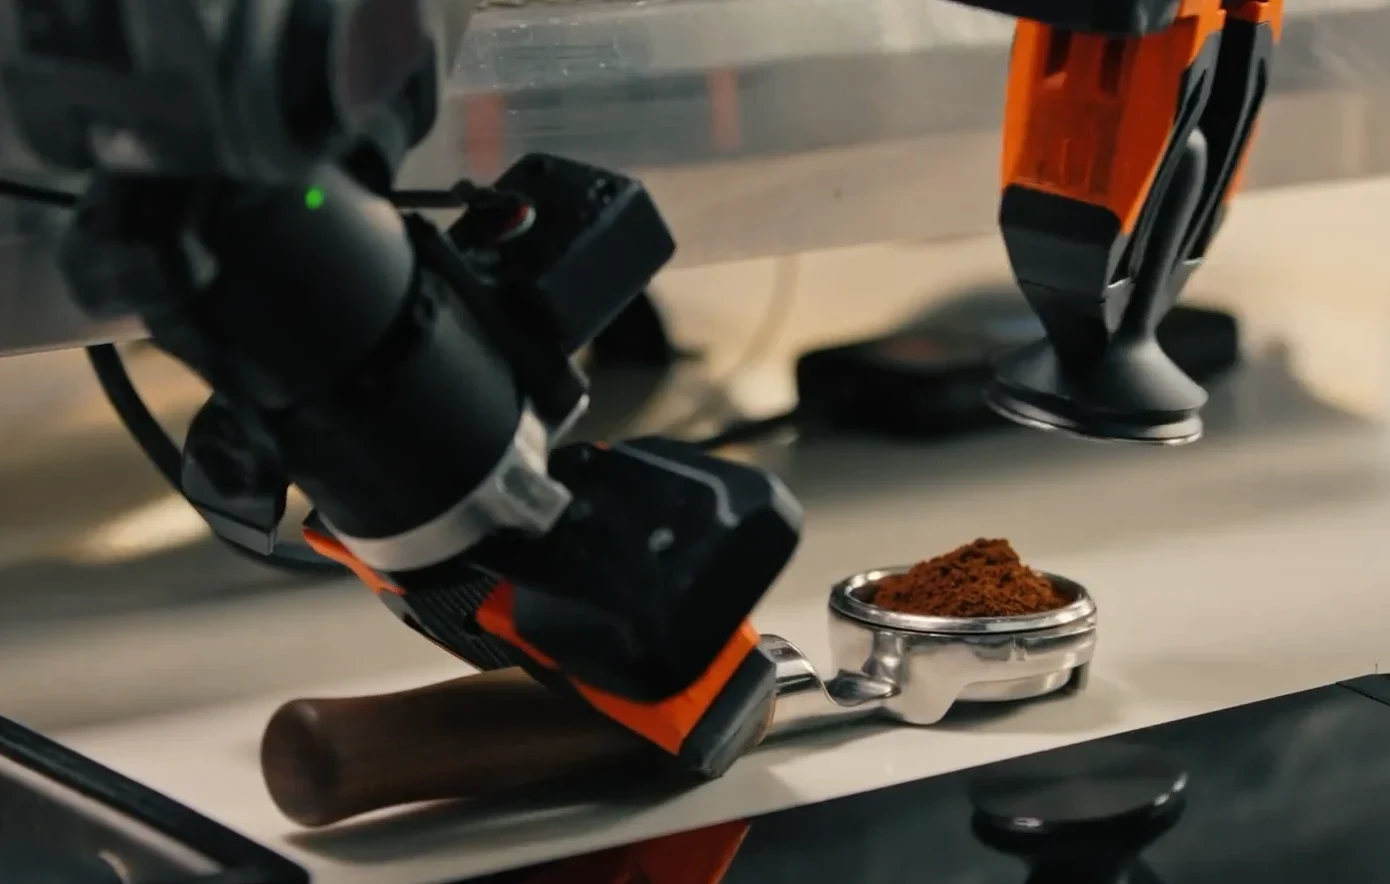
Coffee preparation experiments in the training-time RTC study
Robot policy execution

How Real-Time Chunking Keeps a Robot Moving During VLA Inference

Why action chunks can clash during robot motion, how RTC joins them, and which latency measurements belong in a Physical AI evaluation.

Read article
Language and shortcut-solvability diagnostics from the manipulation benchmark audit
Robot evaluation

What a High Robot Manipulation Benchmark Score Can Hide

A 2026 audit examines shortcuts, statistical evidence and training-data effects in LIBERO, CALVIN, SimplerEnv, RoboCasa and RoboTwin 2.0.

Read article
Unitree G1 reaching experiments from ReactiveBFM
Humanoid motion research

ReactiveBFM Lets a Unitree G1 Replan When the Target Moves

What ReactiveBFM reports about moving-target reaching, recovery and text-conditioned motion, with the simulation score kept separate from physical tests.

Read article
UMI handheld gripper, camera and robot hardware
Robot sensing and data

A Robot Can Miss a Grasp Because Its Camera and Joint Data Disagree on Time

How mismatched camera, proprioception and action timestamps affect grasping, and what to record before training or deploying a robot policy.

Read article
SonicSense robotic hand with fingertip contact microphones
Robot perception research

SonicSense Uses Fingertip Vibrations to Inspect Objects

How a four-finger robot hand uses contact microphones to inspect objects, and which noise, contact and object changes an acoustic sensing test should cover.

Read article
Editorial diagram showing egocentric video reconstructed into a full human body mesh for humanoid robot training
Humanoid robot training data

How GenRobot Turns Egocentric Video Into Whole-Body Robot Training Data

A hand reaching for an object is only one slice of a human action. The feet move, knees bend, weight shifts, the torso stabilizes and both hands coordinate with the object. GenRobot is building a pipeline that reconstructs those missing body signals from egocentric video so they can be used as structured robot-training data.

Read article
AGIBOT WORLD 2026 Theme 3 expert demonstration trajectory for real-world robot reinforcement learning
Embodied AI datasets

AGIBOT WORLD 2026 Theme 3 opens 11,430 real-world robot trajectories for reinforcement learning

AGIBOT WORLD 2026 Theme 3 releases 11,430 real-world robot trajectories across 14 tasks, including successful and failed policy rollouts, human corrections and fine-grained execution annotations for reinforcement learning.

Read article
Humanoid robotics guide

Humanoid Robot Safety Standards in 2026

A practical guide to humanoid robot safety standards for factories service environments testing risk assessment and deployment in 2026.

Read article
Humanoid robotics guide

Humanoid Robot Reliability and MTBF

How to evaluate humanoid robot reliability using operating hours failure rates joint life repair time and task level evidence.

Read article
Humanoid robotics guide

Humanoid Robot Operating Systems Explained

A clear guide to humanoid robot operating systems including real time control hardware abstraction middleware AI services and security.

Read article
Humanoid robotics guide

Humanoid Robot Controller Architecture

A practical map of humanoid control from sensors and state estimation to planners, policies, whole-body control, joint commands and motor drives, with timing and failure points.

Read article
Humanoid robotics guide

Humanoid Cybersecurity: Scope of the Evidence

Review humanoid attack surfaces and software integrity while separating NIST manufacturing testbeds from evidence about a particular humanoid platform.

Read article
Humanoid robotics guide

Humanoid Robot Fleet Management

Open-RMF covers fleet and building coordination. Separate that scope from humanoid skills, version tracking and fleet reliability evidence.

Read article
Humanoid robotics guide

Humanoid Robot Modular Interfaces

A guide to mechanical electrical communication and software interfaces that make humanoid robot modules replaceable and interoperable.

Read article
Humanoid robotics guide

Humanoid Robot Dataset Standards

ISO/CD 26264-1 and China's humanoid dataset project are still in development. Examine their scope without treating it as a finalized data format.

Read article
Humanoid robotics guide

Humanoid Robot Testing Standards

A practical framework for testing humanoid perception planning locomotion manipulation safety reliability and task performance.

Read article
Humanoid robotics guide

Humanoid Robot Energy Efficiency

Battery energy and energy per completed task answer different questions. This note explains why the cited battery-safety standard is not an efficiency test.

Read article
Humanoid robotics guide

Humanoid Robot Thermal Management

Why heat from motors batteries drives and onboard compute can limit humanoid robot duty cycle reliability and sustained performance.

Read article
Humanoid robotics guide

Humanoid Robot Fall Protection

Self-recovery does not establish post-fall condition. This note identifies the evidence missing from claims about humanoid fall protection and inspection.

Read article
Humanoid robotics guide

Humanoid Robot Hand Durability

How to evaluate humanoid hand durability using cycle counts, load profiles, grasp failures, temperature, maintenance records and task-level endurance tests.

Read article
Humanoid robotics guide

Humanoid Robot Joint Reliability

How rotary and linear humanoid joints are evaluated for wear backlash heat torque sensing fatigue and service life.

Read article
Humanoid robotics guide

Humanoid Robot Maintenance Guide

A practical maintenance framework for humanoid robots covering inspections joints hands batteries calibration software logs and spare parts.

Read article
Humanoid robotics guide

Humanoid Calibration: Frames and Validation

Camera frames and independent validation matter in humanoid calibration. This note identifies what the cited documents do and do not establish.

Read article
Humanoid robotics guide

Humanoid Robot Acceptance Testing

Humanoid acceptance depends on the contracted task and customer site. This note distinguishes those questions from the scope of the standards cited.

Read article
Humanoid robotics guide

Humanoid Robot Factory Integration

How to connect a humanoid with MES, WMS, PLCs, safety zones, charging, maintenance, fleet software and production KPIs before a factory deployment.

Read article
Humanoid robotics guide

Humanoid Robot Privacy and Data Governance

How humanoid cameras microphones maps logs and training data create privacy risks in factories homes hospitals and public spaces.

Read article
Humanoid robotics guide

Humanoid Robot OTA Updates and Rollback

How humanoid fleets can update firmware models skills and safety configurations with signing staged rollout validation and rollback.

Read article
Humanoid robotics guide

Humanoid Robot Skill Management

How humanoid robot skills can be packaged versioned validated assigned to robots monitored and rolled back across a fleet.

Read article
Humanoid robotics guide

Humanoid Robot Interoperability

What interoperability means for humanoid fleets across mechanical interfaces communication task APIs infrastructure and safety.

Read article
Humanoid robotics guide

Humanoid Robot Network Latency

How latency jitter packet loss and Quality of Service affect humanoid perception teleoperation fleet control and safe motion.

Read article
Humanoid robotics guide

Humanoid Robot Autonomy Levels

Distinguish remote control, scripted execution and supervised autonomy for a defined humanoid task, with explicit limits on the standards cited.

Read article
Humanoid robotics guide

Humanoid Robot Liability and Insurance

A practical overview of liability evidence contracts software updates incident records and insurance questions for humanoid deployments.

Read article
Humanoid robotics guide

Humanoid Robot EU Regulation

Check the distinct EU machinery, product-liability and high-risk AI dates relevant to humanoid robotics, with source and applicability limits.

Read article
Humanoid robotics guide

Humanoid Robot Simulation Testing

How simulation can test humanoid perception planning control interaction and faults before expensive or risky physical trials.

Read article
Humanoid robotics guide

Humanoid Robot Human Object Handover

How humanoids detect handover intent, regulate grip force, choose release timing and recover from failed transfers, with the measurements needed for useful testing.

Read article
Humanoid robotics guide

Humanoid Robot Incident Reporting

How to document humanoid falls, collisions, dropped objects, unexpected motion and human interventions without guessing causes or inventing failure rates.

Read article
Humanoid robotics guide

Humanoid Robot Deployment Readiness

Assess deployment evidence for a defined humanoid task. The laboratory, pilot and production distinctions here are editorial, not certification levels.

Read article
Momaro mobile manipulation research robot
Robot learning technical guide

Flow Matching for Robot Control

How flow-matching robot policies generate continuous action chunks, differ from diffusion control, use VLA action experts and fail under real-world shifts.

Read article
Shadow Dexterous Hand holding a light bulb
Dexterous manipulation technical guide

Tactile Foundation Models

How tactile foundation models learn reusable touch representations, predict contact and support slip correction, dexterous hands and contact-rich robot control.

Read article
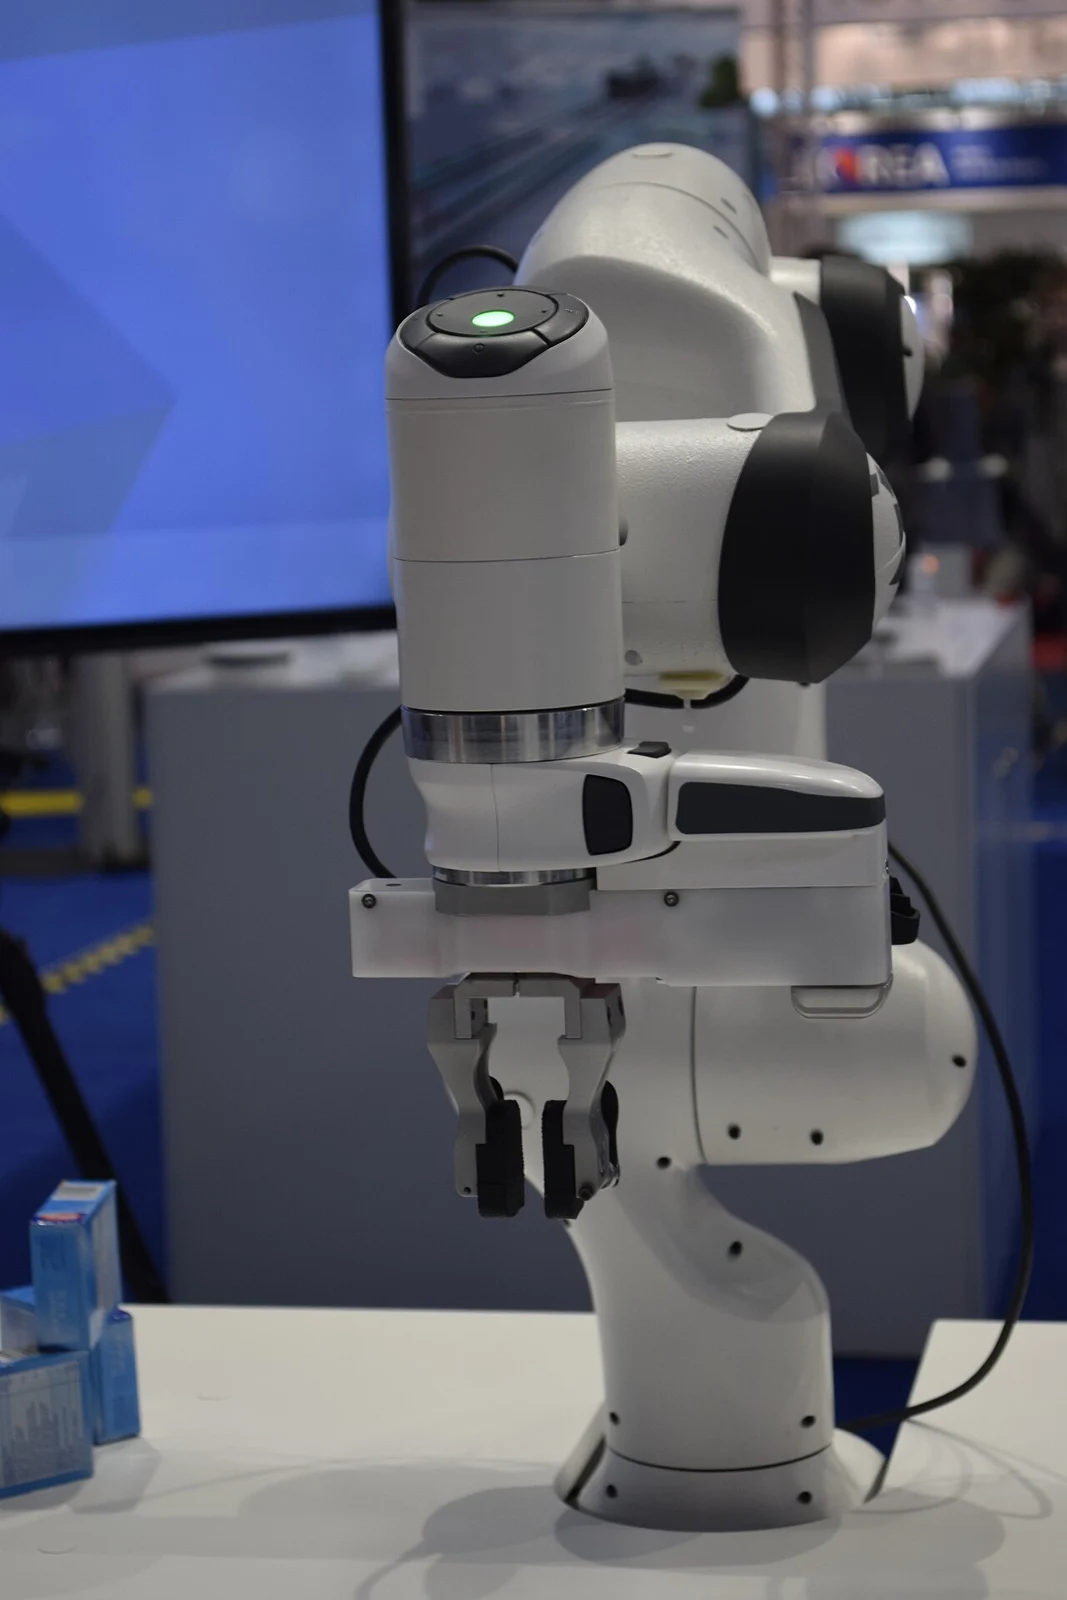
Franka Emika robot arm, viewed from the side
Physical AI safety technical guide

Robot Policy Uncertainty Estimation

How robots estimate action uncertainty, detect distribution shift, calibrate confidence and trigger safe retries, human intervention or controller fallbacks.

Read article
The National Speed Skating Oval in Beijing
Humanoid robotics event archive

World Humanoid Robot Games 2025 Results With 500+ Robots and 487 Matches

Archive of the inaugural World Humanoid Robot Games in Beijing with 280 teams, more than 500 robots, 26 events, 487 matches, rules and verified results.

Read article
Unitree G1 humanoid robot on display
Humanoid robotics business

Unitree's $900M IPO Was 8,000× Oversubscribed. What Are Investors Actually Buying?

Unitree's Shanghai IPO drew retail demand more than 8,000 times the shares initially available. Here is what the valuation, proceeds, revenue and robotics risks actually mean.

Read article
The National Speed Skating Oval, venue for the World Humanoid Robot Games
Humanoid robotics event

World Humanoid Robot Games 2026: results and autonomy rules

Reported 2026 humanoid Games results, the limits of the 2025 comparison, differing autonomy rules and what the dataset announcement establishes.

Read article
A humanoid reaching for a watering can in Google DeepMind's Gemini Robotics 2 demonstration
Physical AI model

Gemini Robotics 2 Google Now Controls a Humanoid From Feet to Fingertips

Google DeepMind Gemini Robotics 2 extends VLA control from tabletop manipulation to full humanoid motion and dexterous hands. Here is what the demos prove and what remains difficult.

Read article
A robot handling a baseball glove in Google DeepMind's Gemini Robotics ER 2 demonstration
Embodied reasoning

Gemini Robotics ER 2 The High-Level Brain Coordinating Robots as a Team

Gemini Robotics ER 2 sits above low-level robot control, watching video, choosing tools, tracking task progress and coordinating multiple robots. This is what its architecture changes.

Read article
An Intel RealSense L515 lidar depth camera
Spatial AI

Spatial Intelligence Why 3D Reasoning May Be the Missing Layer in Robotics

Spatial intelligence gives robots explicit structure for distance, geometry, occlusion and physical interaction. It may become the bridge between vision-language models, world models and reliable action.

Read article
PR2 research robot with grasping hands
Robot learning

Zero-Shot Robotics Can Physical AI Work on Tasks It Never Trained On?

Zero-shot is one of robotics most abused labels. This guide separates unseen objects, tasks, scenes, embodiments and sim-to-real deployment so the claim becomes measurable.

Read article
Willow Garage PR2 robot holding a book
Embodied AI memory

Robot Memory Why a Humanoid Can Forget a Task After Its Arm Blocks the Camera

Robots need memory when task-critical information disappears from the current camera frame. This guide compares short-term visual memory, episodic memory, semantic memory and compressed VLA history.

Read article
An engineer working on NASA's A-PUFFER rover
Embodied AI research

Self-Evolving Embodied AI Can a Robot Improve After Deployment Without Full Retraining?

Self-evolving embodied AI aims to update memory, task strategy, world prediction, embodiment models and policies from ongoing experience. The promise is large; the safety and verification problem is larger.

Read article
Dobot Magician robot arms in a laboratory
Robot learning architecture

Robot Skills vs VLA Models Should Competence Live in Weights or Executable Code?

Robot learning is splitting between end-to-end policies stored in model weights and agents that compose executable skills. The practical winner may be a hybrid with learned motor control and auditable task-level code.

Read article
Cloth manipulation experiments from the Universal Manipulation Interface project
Humanoid manipulation

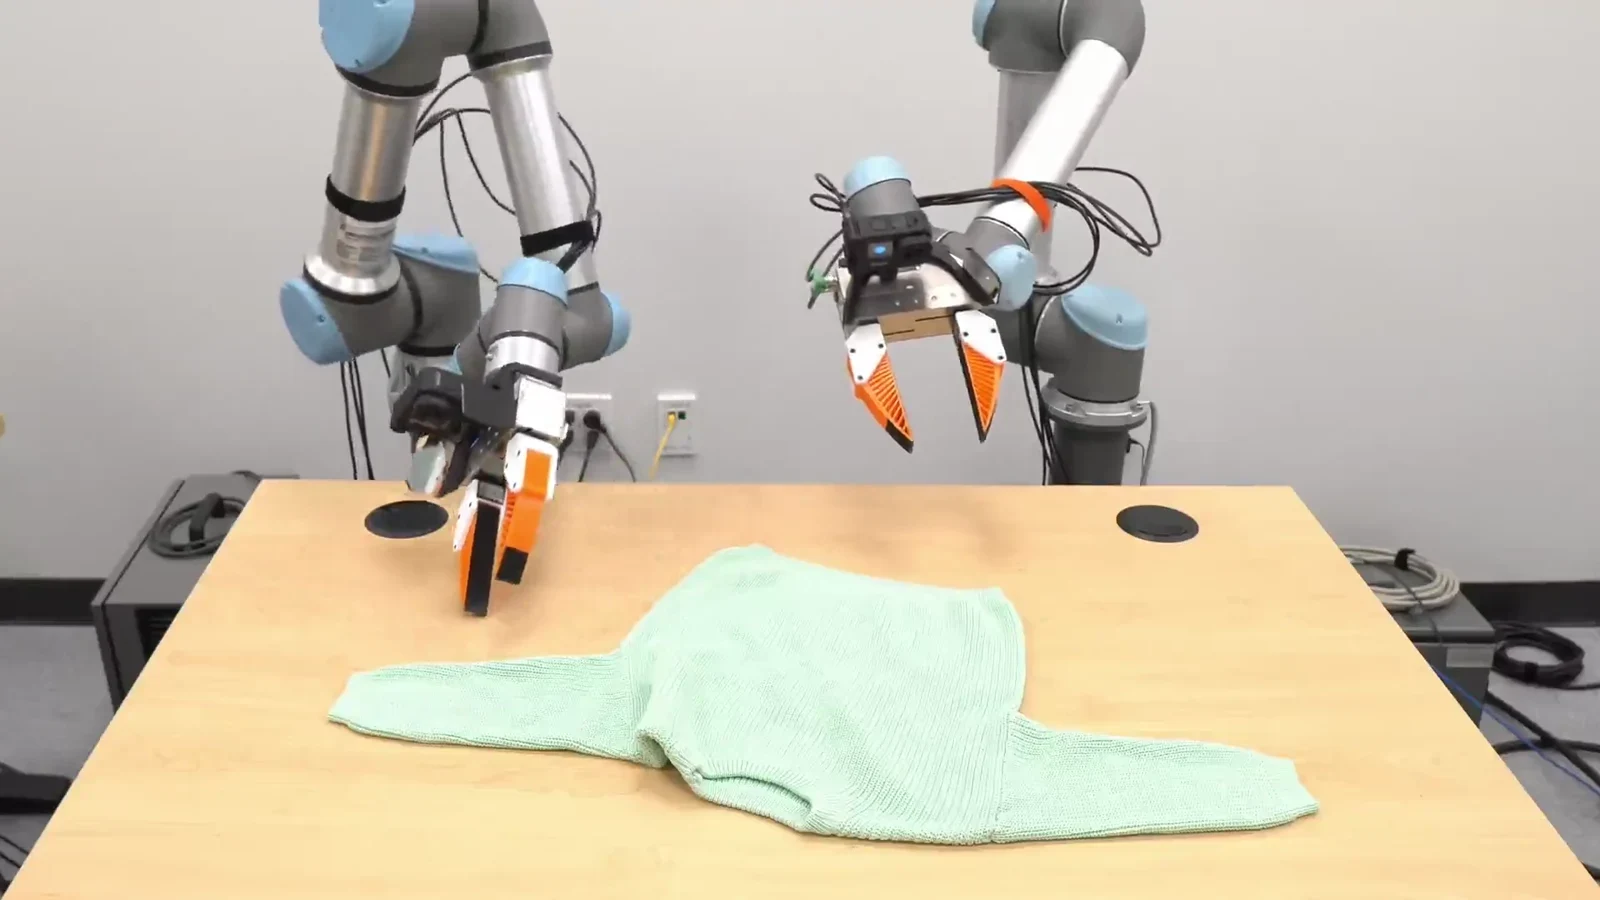
Why Folding Laundry Is Still a Brutal Test for Humanoid Robots

Fabric exposes the weaknesses of robot perception and manipulation deformable state, self-occlusion, friction, bimanual coordination and expensive resets. This is why laundry remains a serious robotics stress test.

Read article
A swarm of Kilobots
Multi-robot systems

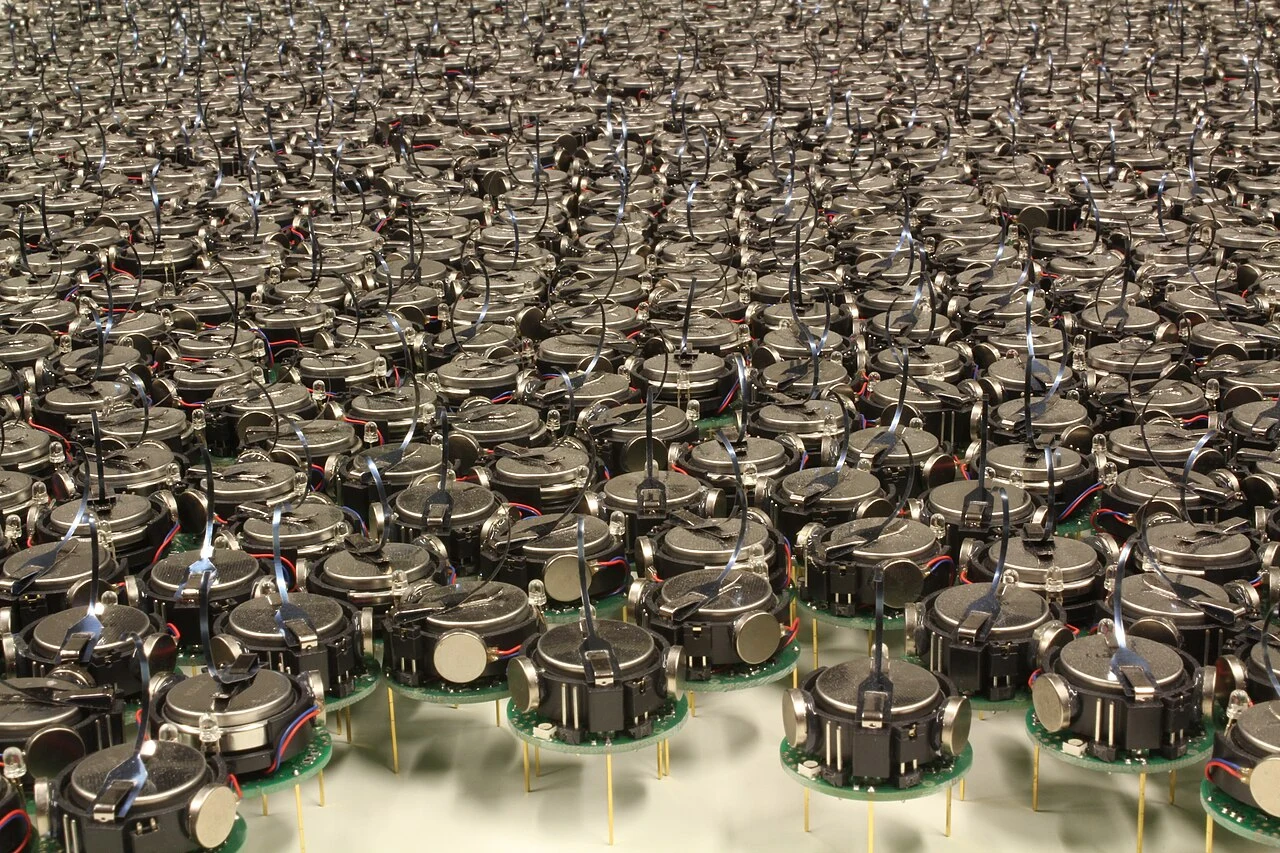
Multi-Robot AI What Changes When Robots Share Tasks, Memory and Failures?

Multi-robot AI moves beyond fleet dispatch toward shared world state, progress and skills. The gain is specialization and parallelism; the price is coordination, communication and failure propagation.

Read article
A Baxter robot learning an object handover from a human demonstration
World models and physics

Physics-Informed AI Why Realistic Video Is Not Enough to Train Robots

A robot world model can generate a convincing video and still violate contact, gravity or object dynamics. Physics-aligned AI tries to make predicted futures useful for control, not only visually plausible.

Read article
Unitree Robotics headquarters in Hangzhou
Robotics finance

China Humanoid Robot IPOs After Unitree’s Listing and New Scrutiny

Unitree is now public in Shanghai while other Chinese humanoid companies face tighter IPO scrutiny over valuation, recurring revenue and dependence on state-backed projects.

Read article
PAL Robotics TIAGo++ mobile robot with two arms
Robot autonomy

Long-Horizon Robot Tasks Why Success Collapses as the Number of Steps Grows

Robots can master individual skills and still fail long workflows. This guide explains compounding error, partial observability, progress tracking, verification and recovery architectures for multi-step tasks.

Read article
Dobot Magician arms manipulating colored blocks
Agentic robotics

Agentic Robotics The Layer That Plans, Checks, Recovers and Calls Robot Skills

Agentic robotics puts a deliberative layer above low-level control so a robot can decompose goals, call bounded skills, verify outcomes, use memory and recover. It is orchestration, not direct motor control.

Read article
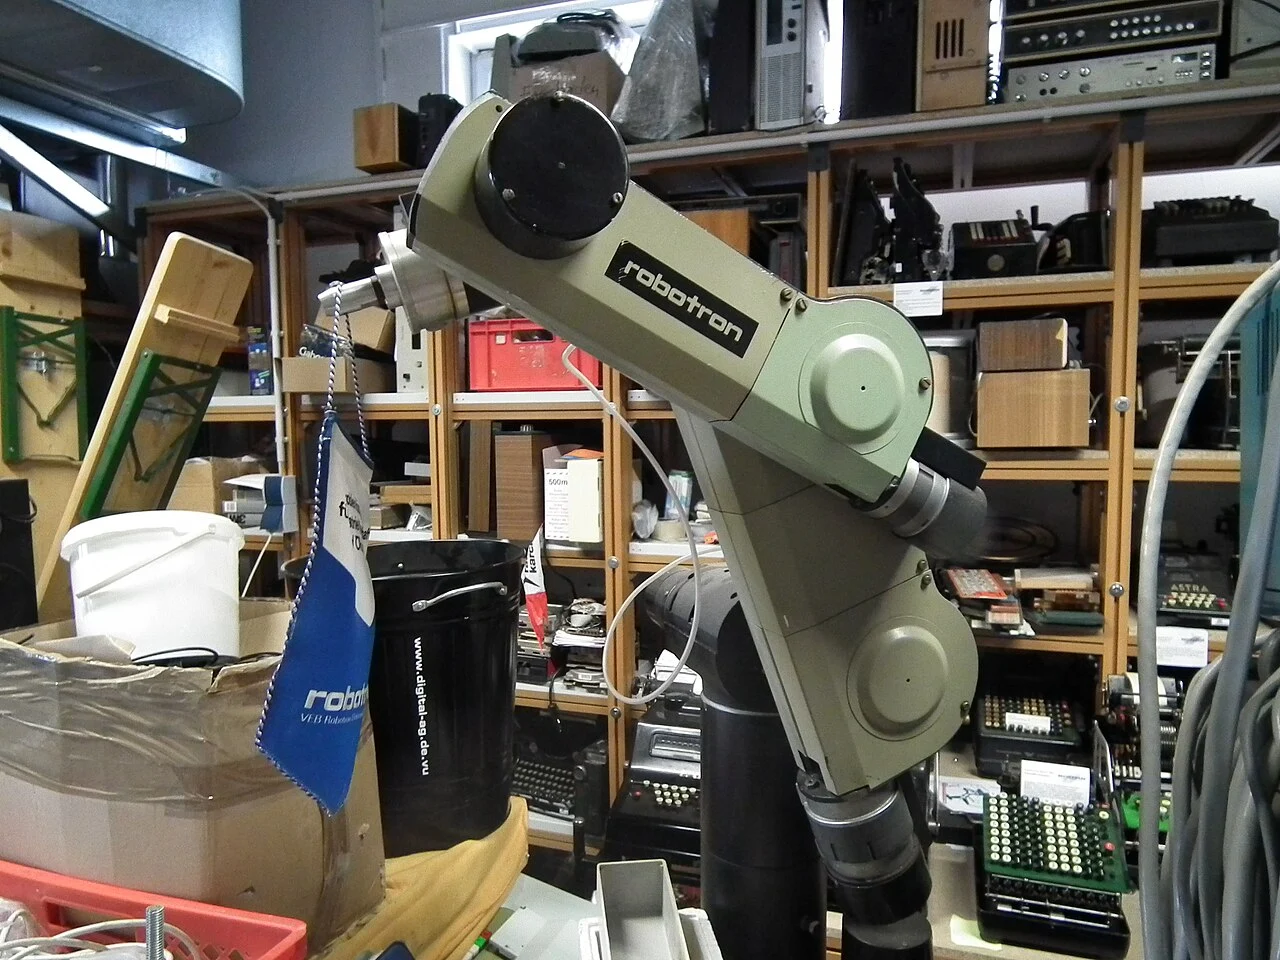
An industrial robot arm on display
Robotics

Industrial Robotic Arms The Specs That Matter Before You Buy

Industrial robotic arms explained types, payload, reach, repeatability, tooling, safety, integration cost and the specs that determine a successful cell.

Read article
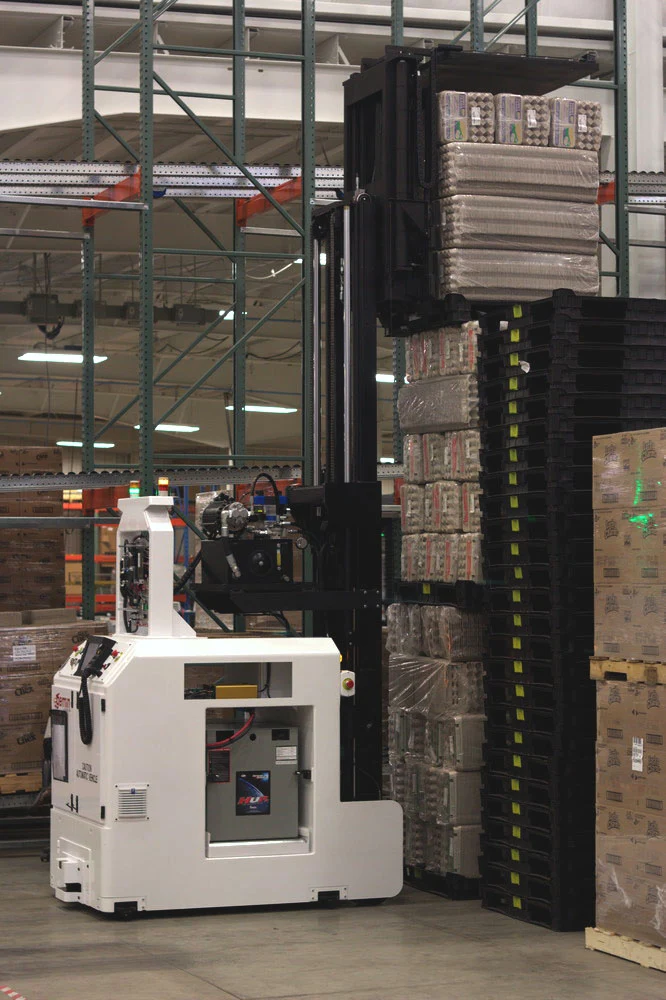
An automated forklift transporting goods
Robotics

AGV Navigation Systems Which Method Fits the Factory?

Compare AGV navigation systems magnetic tape, QR codes, laser reflectors and LiDAR SLAM, including infrastructure, docking, failure modes and selection.

Read article
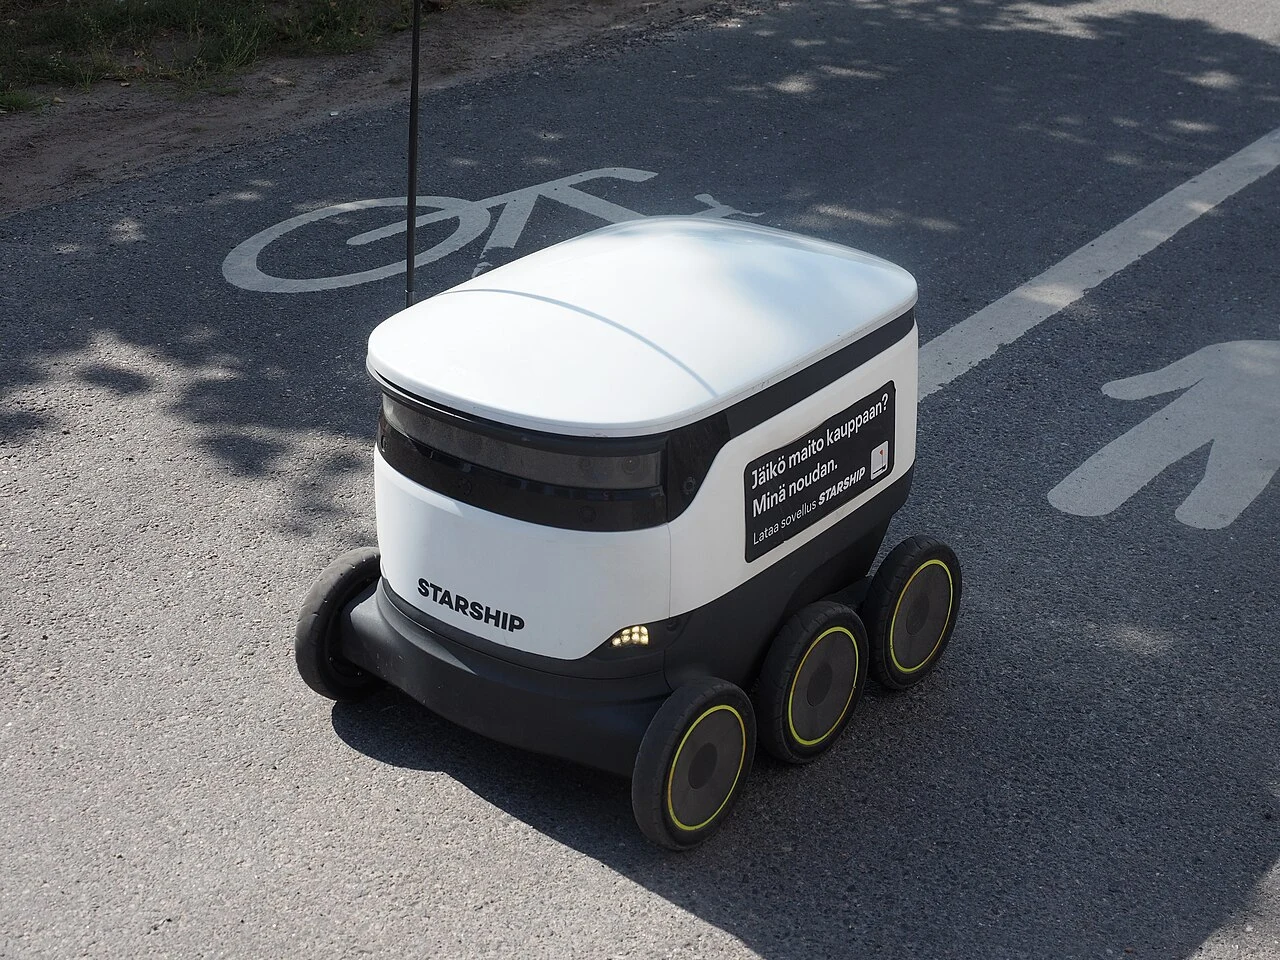
A Starship delivery robot in Espoo, Finland
Robotics

Robots as a Service When Renting Automation Beats Buying It

Robots as a Service explained pricing models, uptime, integration costs, support, data rights, contract clauses and when RaaS beats buying automation.

Read article
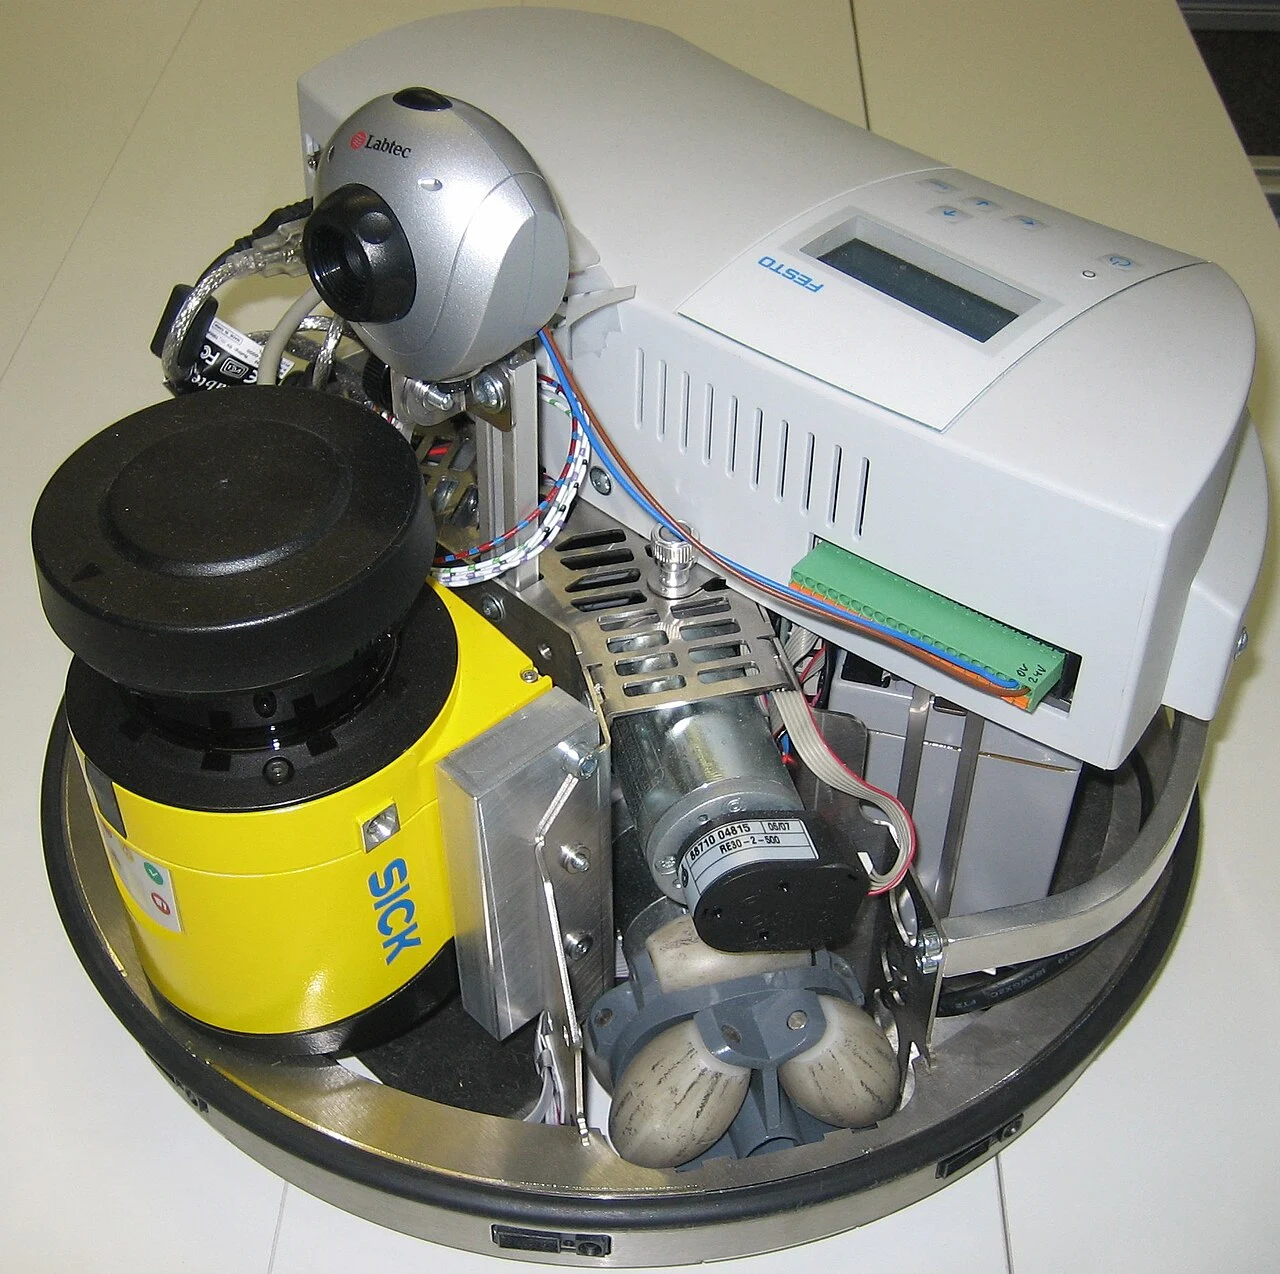
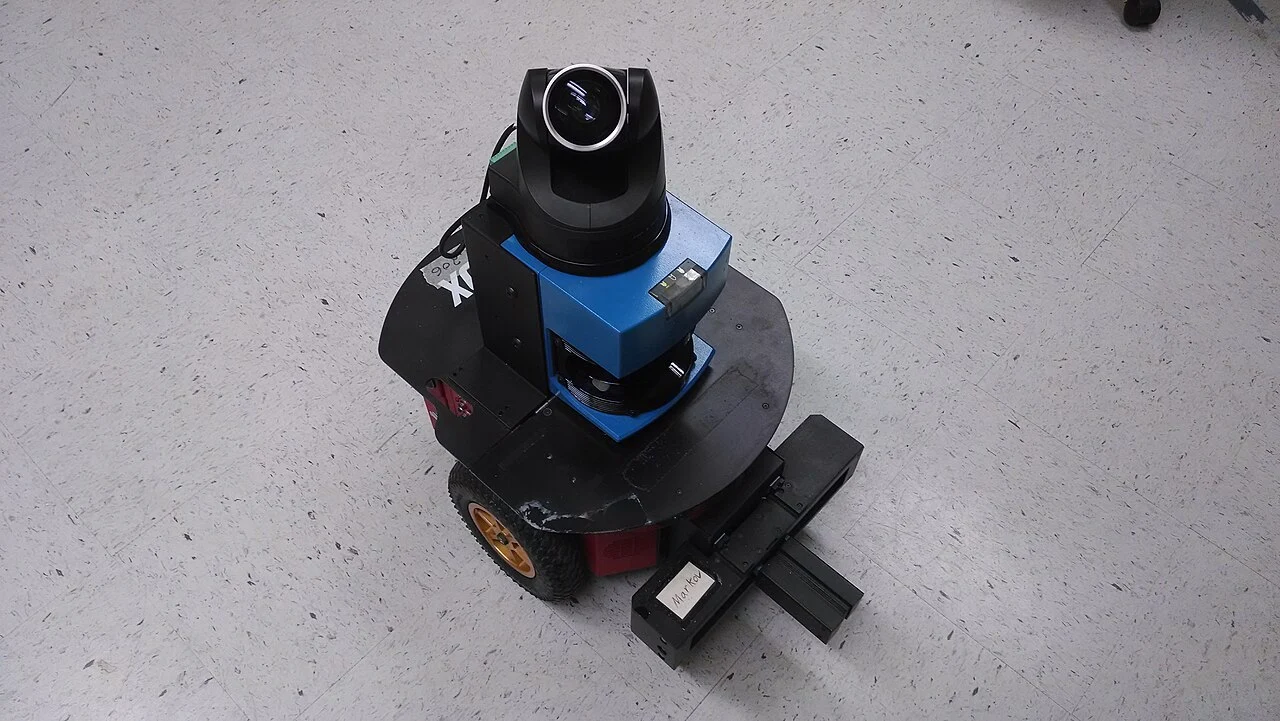
A Robotino mobile robot with a SICK laser range finder
Robotics

Warehouse Robot Sensors What Keeps an AMR Localized and Safe

Warehouse robot sensors explained by job LiDAR, safety scanners, 3D cameras, encoders, IMUs and inventory sensing, plus failure modes and redundancy.

Read article
A Unitree Go1 quadruped robot outdoors
Robotics

Robots for Sale in 2026 Which Machines You Can Actually Order

Verified robots for sale in 2026, separating online prices, deposits, subscriptions and quote-only systems, with Unitree and 1X availability checks.

Read article
The Svan M2 research quadruped outdoors
Robotics

How to Become a Robotics Programmer A Roadmap That Reaches Hardware

A hands-on robotics programmer roadmap covering C++, Python, Linux, ROS 2, TF2, URDF, control, MoveIt, Nav2, perception, logging and real hardware.

Read article
An ABB robot in a laboratory automation installation
Robotics

Physical AI Data Providers Who Collects the Data Robots Need?

Compare Physical AI data providers by real-robot collection, egocentric video, annotation, teleoperation, sensor modalities, quality controls and data rights.

Read article
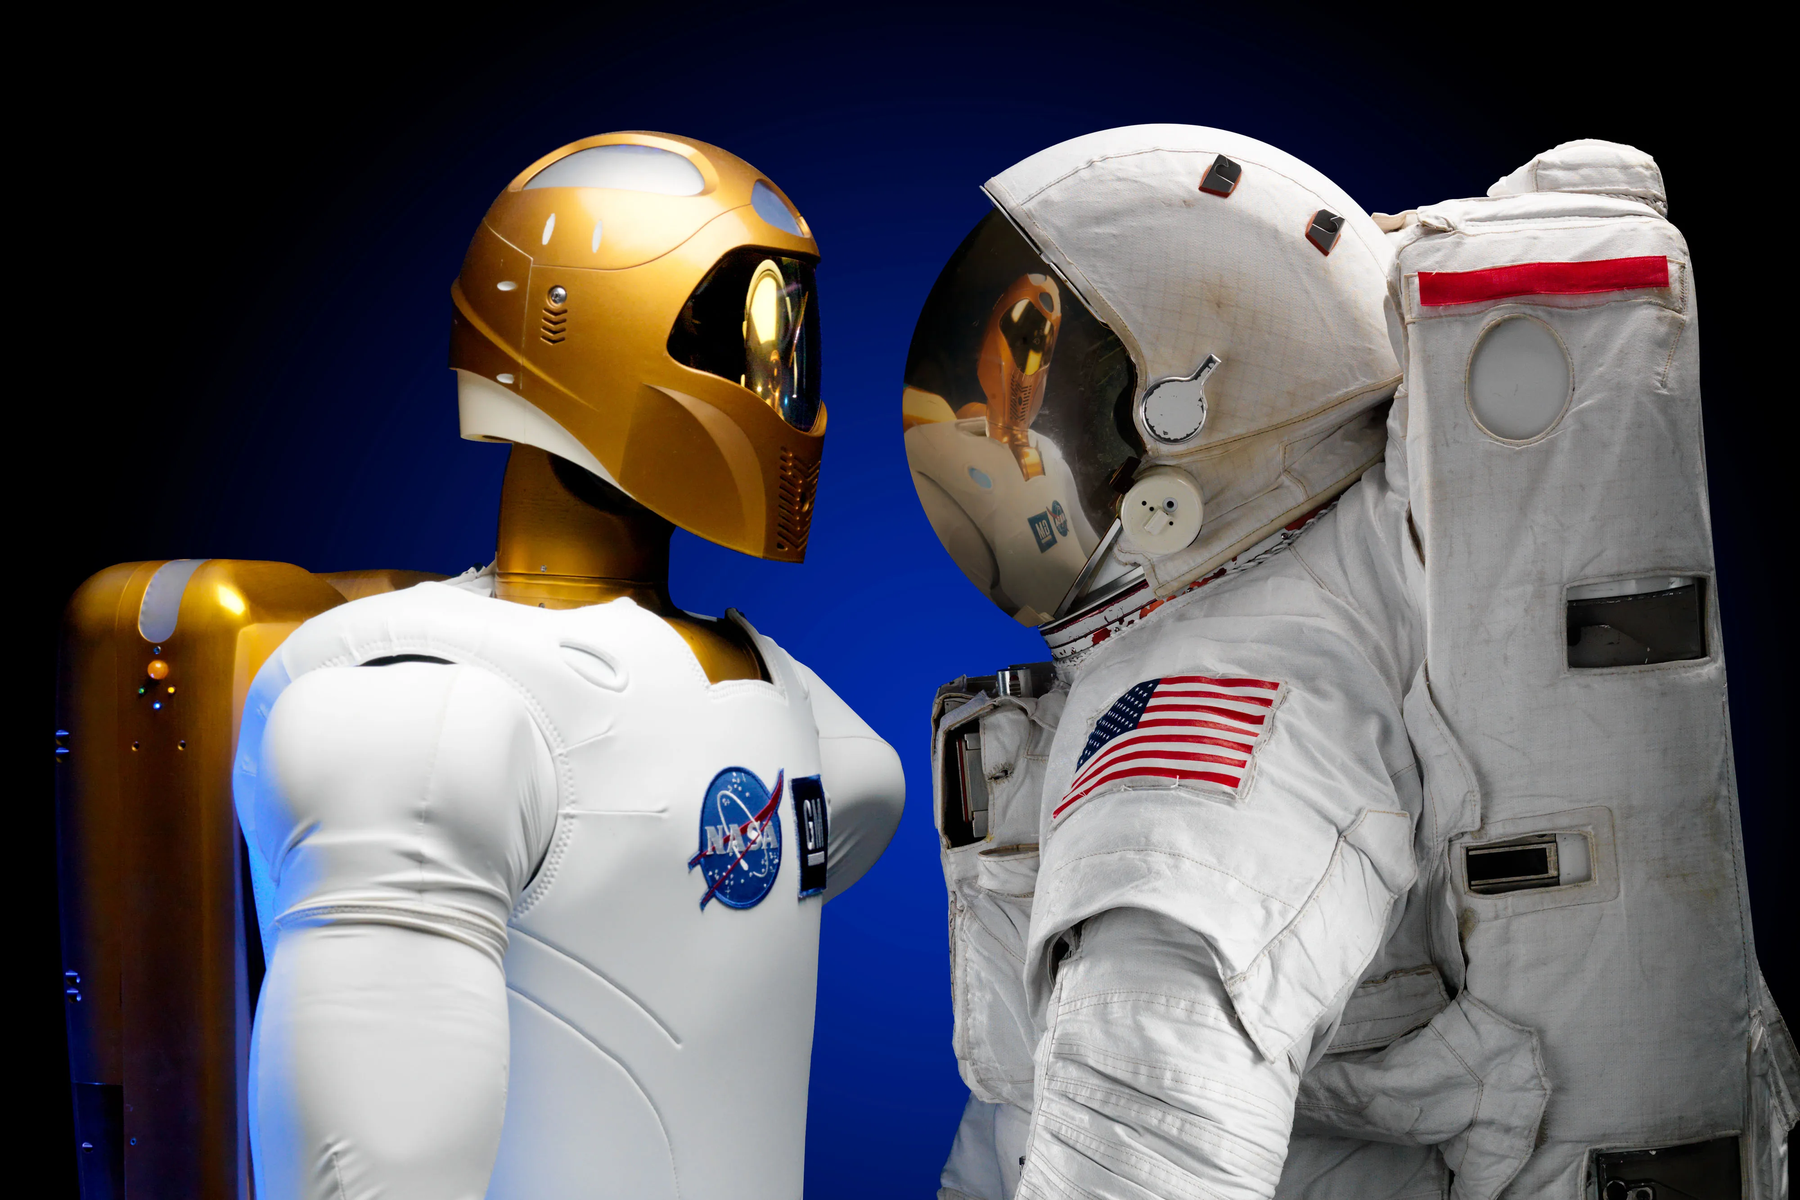
NASA Robonaut 2 humanoid upper bodies
Robotics

Space Robotics Market 2026 Where Robots Are Creating Real Value

Space robotics market 2026 mapped through real missions orbital servicing, robotic arms, lunar mobility and ISAM, plus why market-size estimates disagree.

Read article
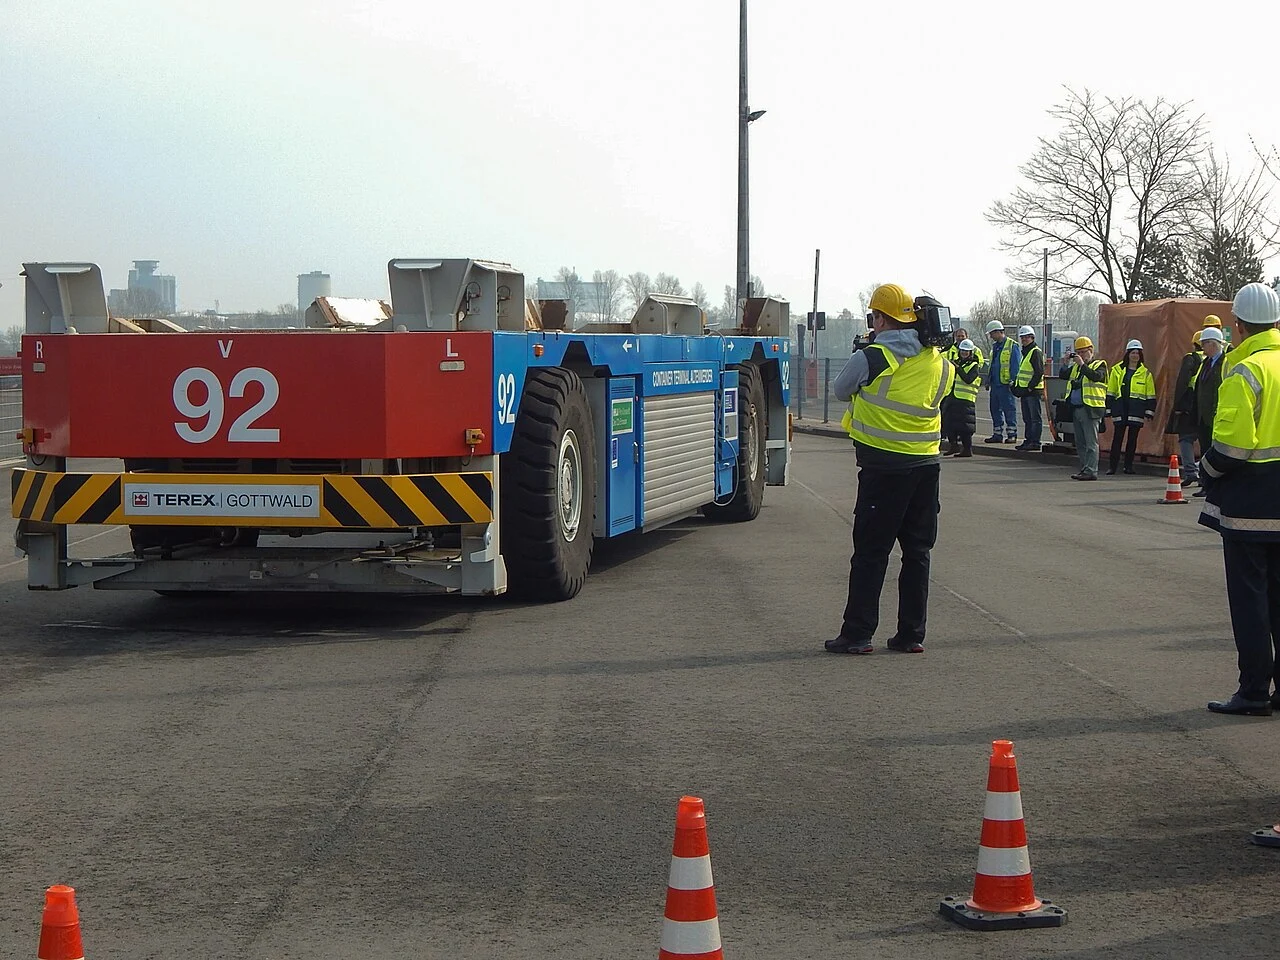
People standing beside an automated container vehicle
Robotics

AGV & AMR Risk Assessment Failure Modes Warehouses Must Design For

AGV and AMR risk assessment guide covering traffic, stopping, loads, blind intersections, localization loss, docking, charging and ISO 3691-4:2023.

Read article
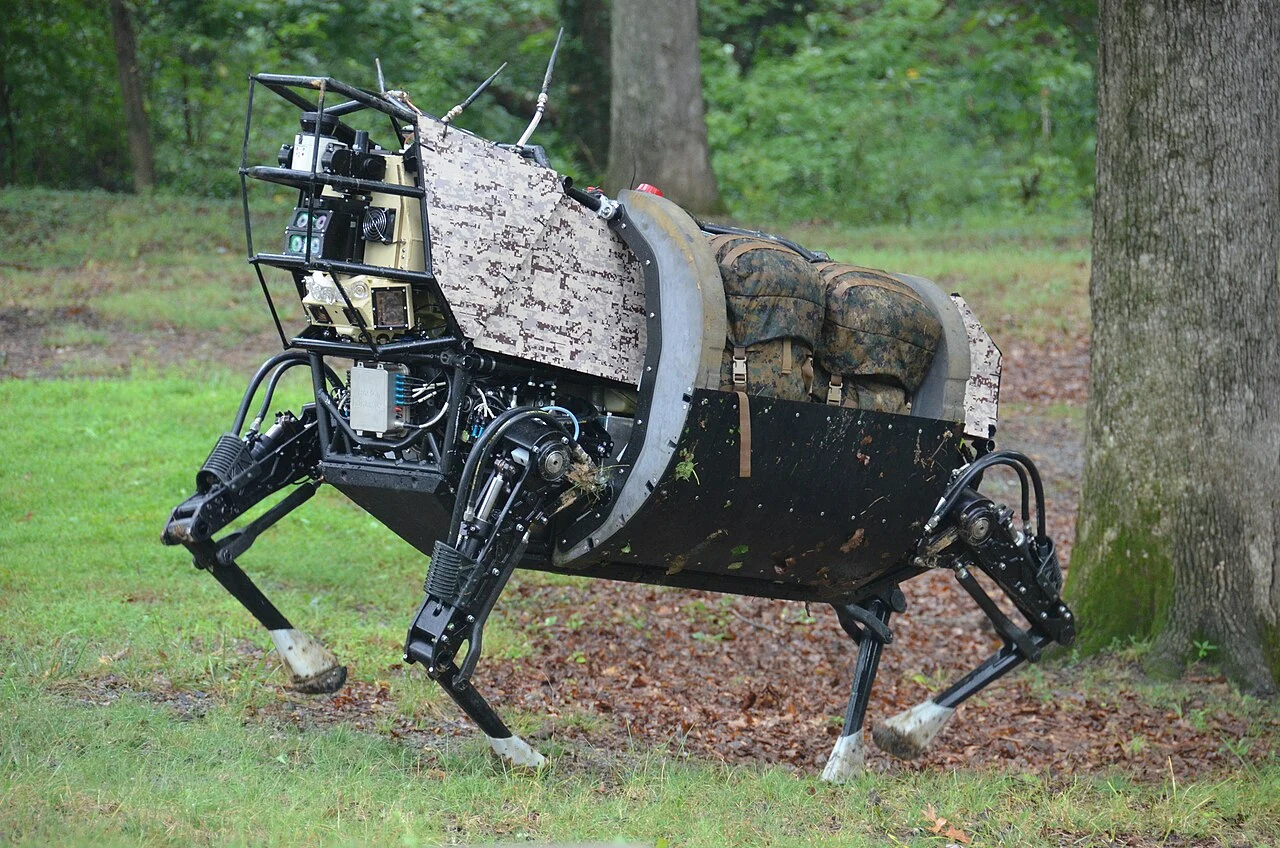
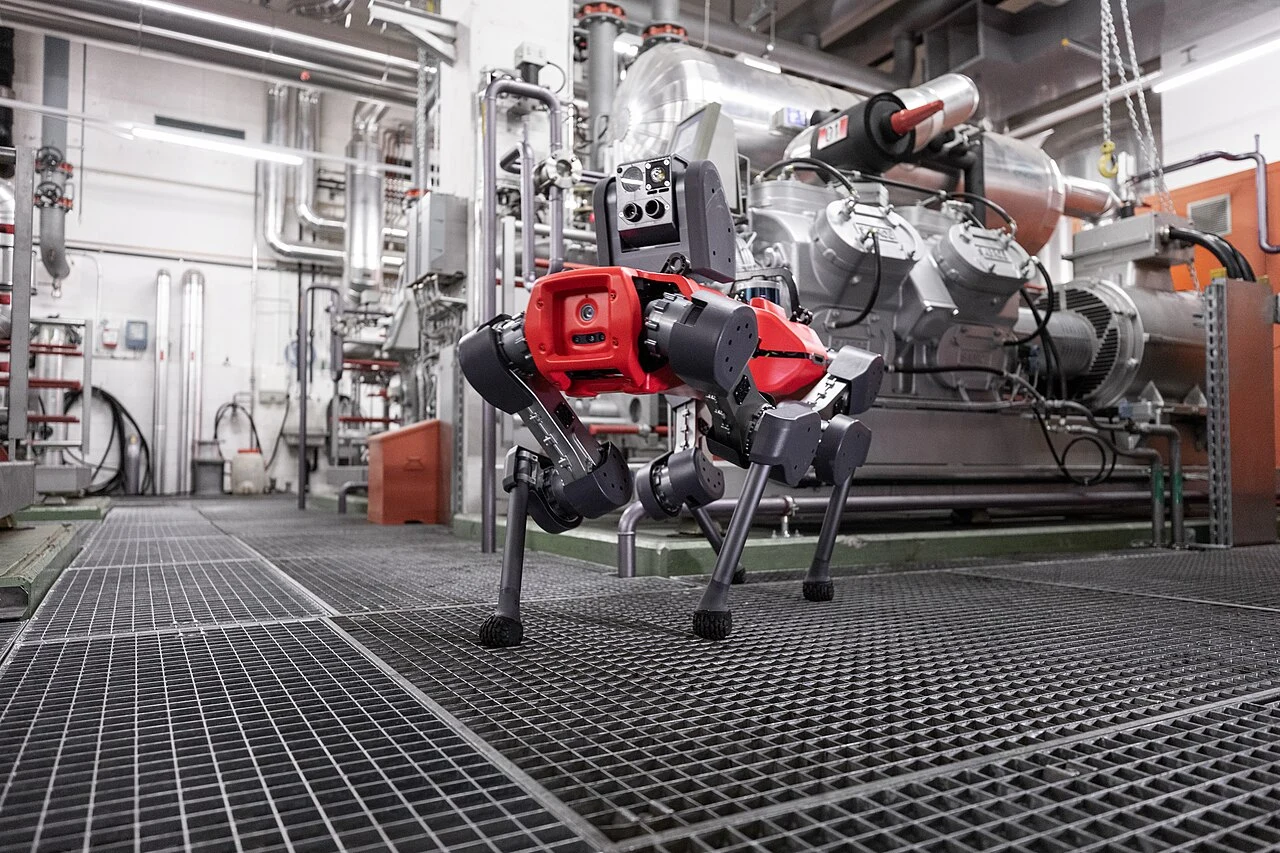
A DARPA LS3 quadruped crossing uneven ground
Robotics

Quadruped Robot Safety What Happens When a Robot Dog Falls?

Quadruped robot safety explained fall zones, self-righting, E-stops, leg motion, payload center of mass, stairs, autonomy, communication loss and recovery.

Read article
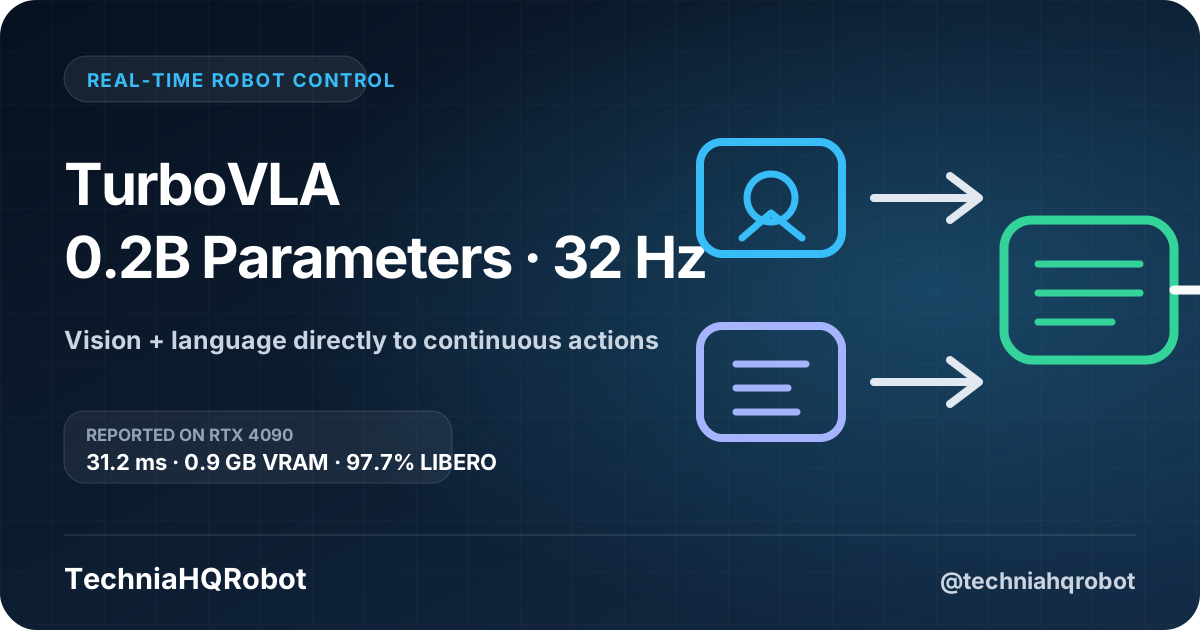
Editorial diagram of TurboVLA connecting camera observations and language instructions directly to robot action chunks at 32 Hz
Efficient vision-language-action models

TurboVLA Runs Robot Control at 32 Hz Without a Giant LLM

TurboVLA removes the large language model from the center of execution-level robot control. The preprint reports a compact 216-million-parameter policy that directly combines visual features and language instructions before predicting continuous action chunks.

Read article
Diagram of the physical AI supply chain centered on TSMC chip manufacturing
Physical AI infrastructure

Why TSMC Is a Critical Bottleneck for Physical AI

Physical AI depends on far more than robot hardware. Advanced processors, image sensors, batteries, motors, cloud systems and model developers form a supply chain with several concentrated points of failure.

Read article
Student competition robot collecting and shooting a ball during an outdoor test
Educational robotics

What Team 3255’s Ball-Shooting Robot Test Actually Shows

A short outdoor test can reveal mechanical behavior that a polished CAD render cannot wheel slip, intake alignment, vibration, shot recovery and the time needed to repeat a cycle.

Read article
Multi-legged spider robot crossing uneven terrain with several feet in contact
Multi-legged research robots

Spider Robots Explained Why Extra Legs Change Mobility

Multi-legged robots trade mechanical simplicity for contact options. More legs can preserve support while another leg searches for a foothold, but they also increase actuator count, control complexity and maintenance.

Read article
Cutaway diagram of a dexterous robot hand with coreless motors, tendons and sensors
Humanoid robot hands

How Coreless Motors Power a Dexterous Robot Hand

A lifelike robot hand needs compact actuators, transmission, sensing and fast current control. Software chooses motion, but the hardware determines force, backlash, heat and response.

Read article
Editorial graphic separating AI job cuts, robotics funding and population projections
Automation economics

AI Job Cuts, Robotics Funding and the 4 Billion Claim

The viral post combines three different claims employer-announced job cuts attributed to AI, a large robotics funding round and a study exploring a lower global population by 2200.

Read article
Tesla factory automation stack with industrial arms, mobile robots, vision and Optimus
Factory automation

Tesla’s Factory Robots The Automation Stack Beyond Optimus

Optimus dominates Tesla robotics coverage, but vehicle and battery manufacturing already rely on specialized automation built around repeatable geometry, high throughput and controlled work cells.

Read article
Radio circuit board with an antenna beside an administrative folder
Robotics regulation

What the FCC Foreign Robot Rule Actually Blocks

The FCC action targets equipment authorization for newly covered foreign-produced advanced robotic devices. It is broader than a brand blacklist and narrower than confiscating every foreign robot already in the United States.

Read article
Xiaomi-Robotics-1 data pipeline from a handheld UMI gripper to a mobile manipulation robot
Physical AI data scaling

Xiaomi-Robotics-1 Tests Whether Handheld Data Can Scale Physical AI

Xiaomi Robotics is trying to separate robot learning from the robot itself. Its new vision-language-action model begins with more than 100,000 hours of manipulation trajectories recorded through portable UMI grippers, then learns how to control physical robot embodiments in a separate alignment stage.

Read article
Kawasaki CORLEO four-legged personal mobility concept with milestones for 2027, 2030 and 2035
Rideable quadruped robotics

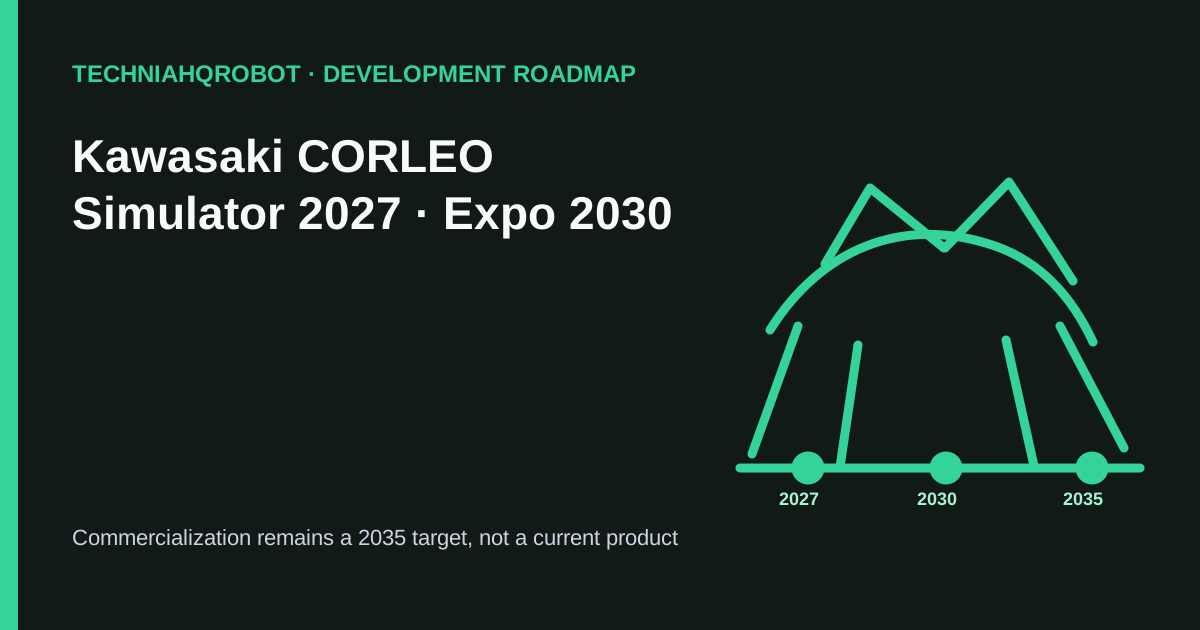
Kawasaki Has a CORLEO Roadmap, but the Walking Vehicle Is Still a Concept

Kawasaki Heavy Industries has moved CORLEO from a distant 2050 concept into a formal development program. The company now targets a riding simulator in 2027, use as on-site mobility at Expo 2030 Riyadh and commercialization work toward 2035.

Read article
Unitree G1 humanoid robot striking a football along a curved trajectory
Humanoid robot learning

How a Unitree G1 Can Learn Curved Soccer Shots

A “banana kick” is not simply a stronger leg swing. The robot must approach the ball, orient the foot, strike away from the center, control body momentum and recover without falling.

Read article
Robotic broadcast camera moving through a television newsroom studio
Broadcast robotics

How Robotic Cameras Are Changing TV Newsrooms

A robotic camera system can repeat precise movements, reposition between shots and connect to newsroom automation. The technology ranges from motorized heads to moving pedestals, rails and robotic arms.

Read article
Engineered Arts Ameca humanoid robot
Robotics

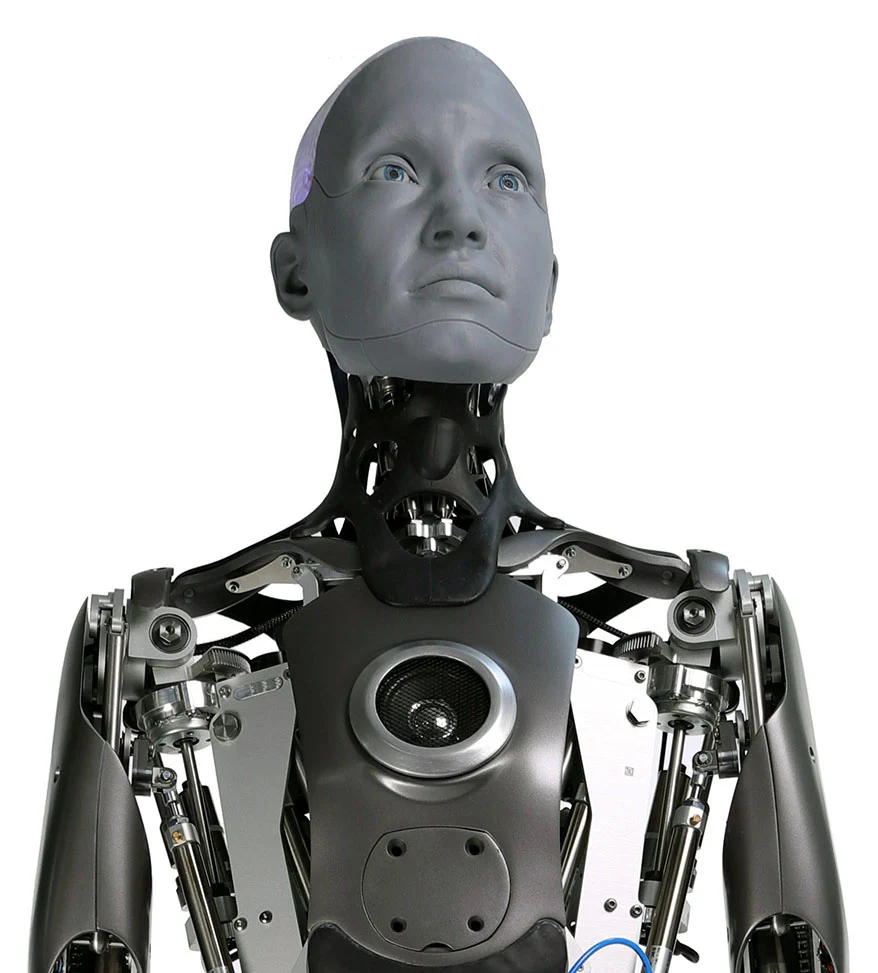
Autonomous Robot Companies in 2026 A Buyer’s Map

Compare autonomous robot companies by robot type, autonomy scope, deployment evidence, safety controls, remote assistance and integration requirements.

Read article
An industrial robot polishing a guitar
Robotics

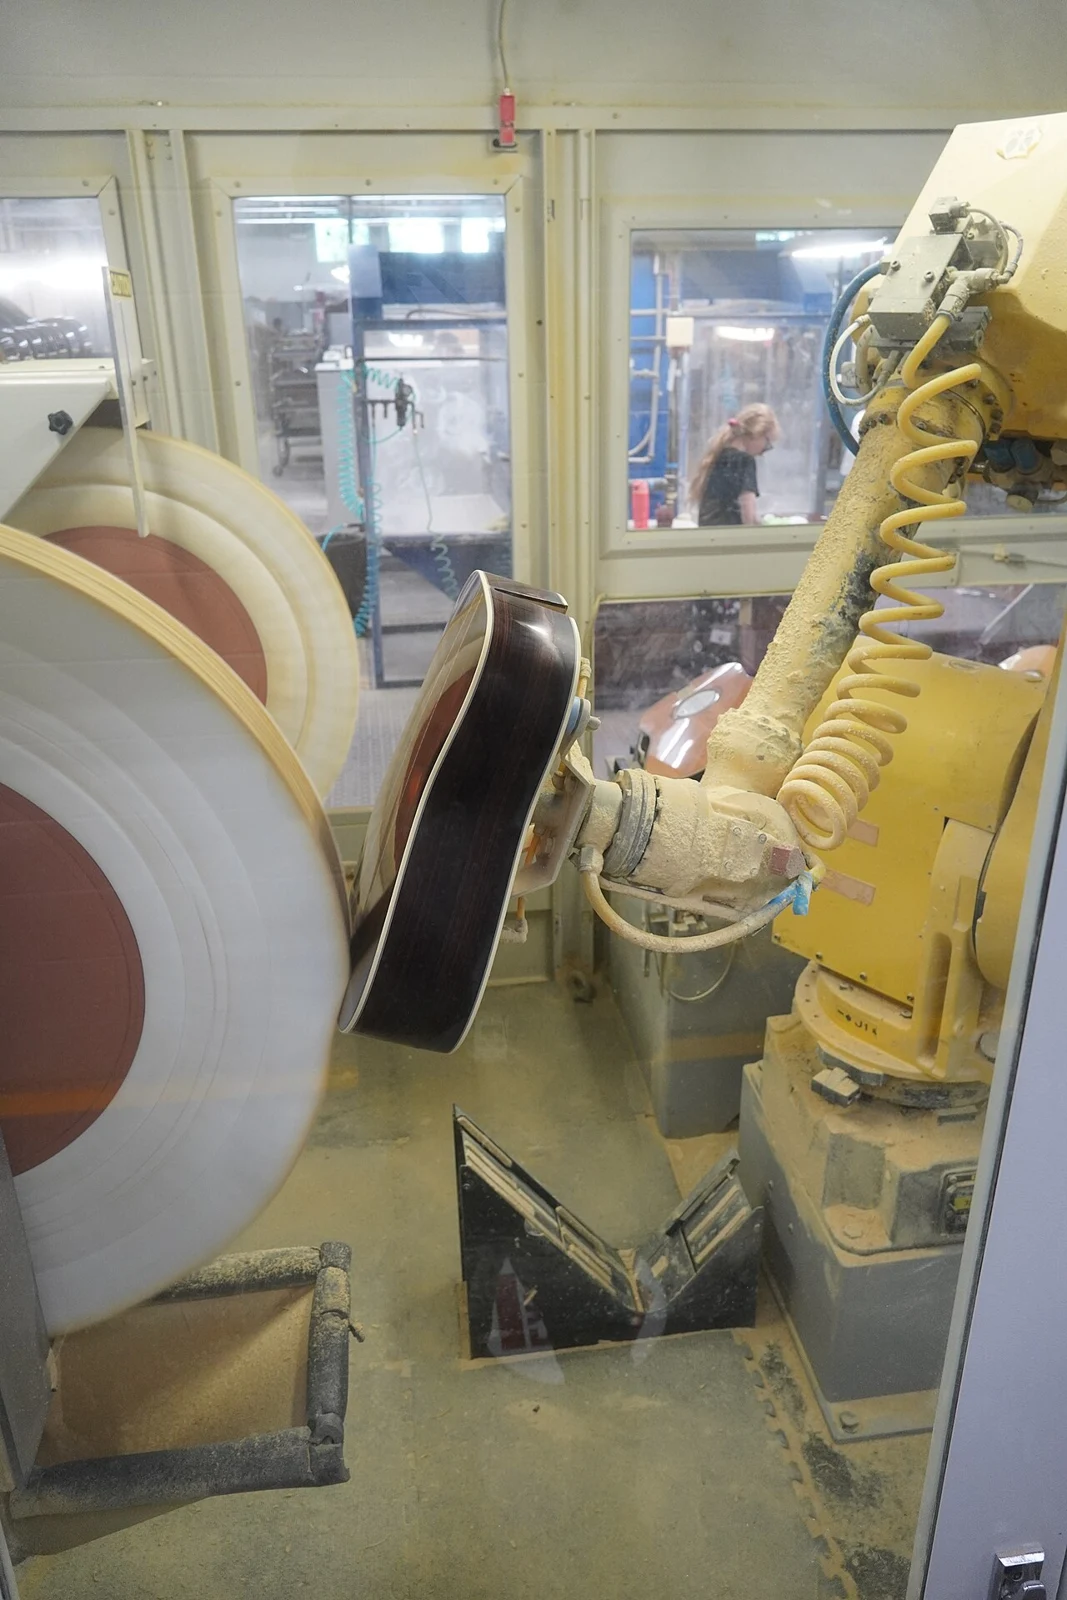
Industrial Robot Manufacturers and Suppliers 2026 Guide

Compare industrial robot manufacturers, cobot suppliers, integrators and component vendors by application, payload, support, safety and software ecosystem.

Read article
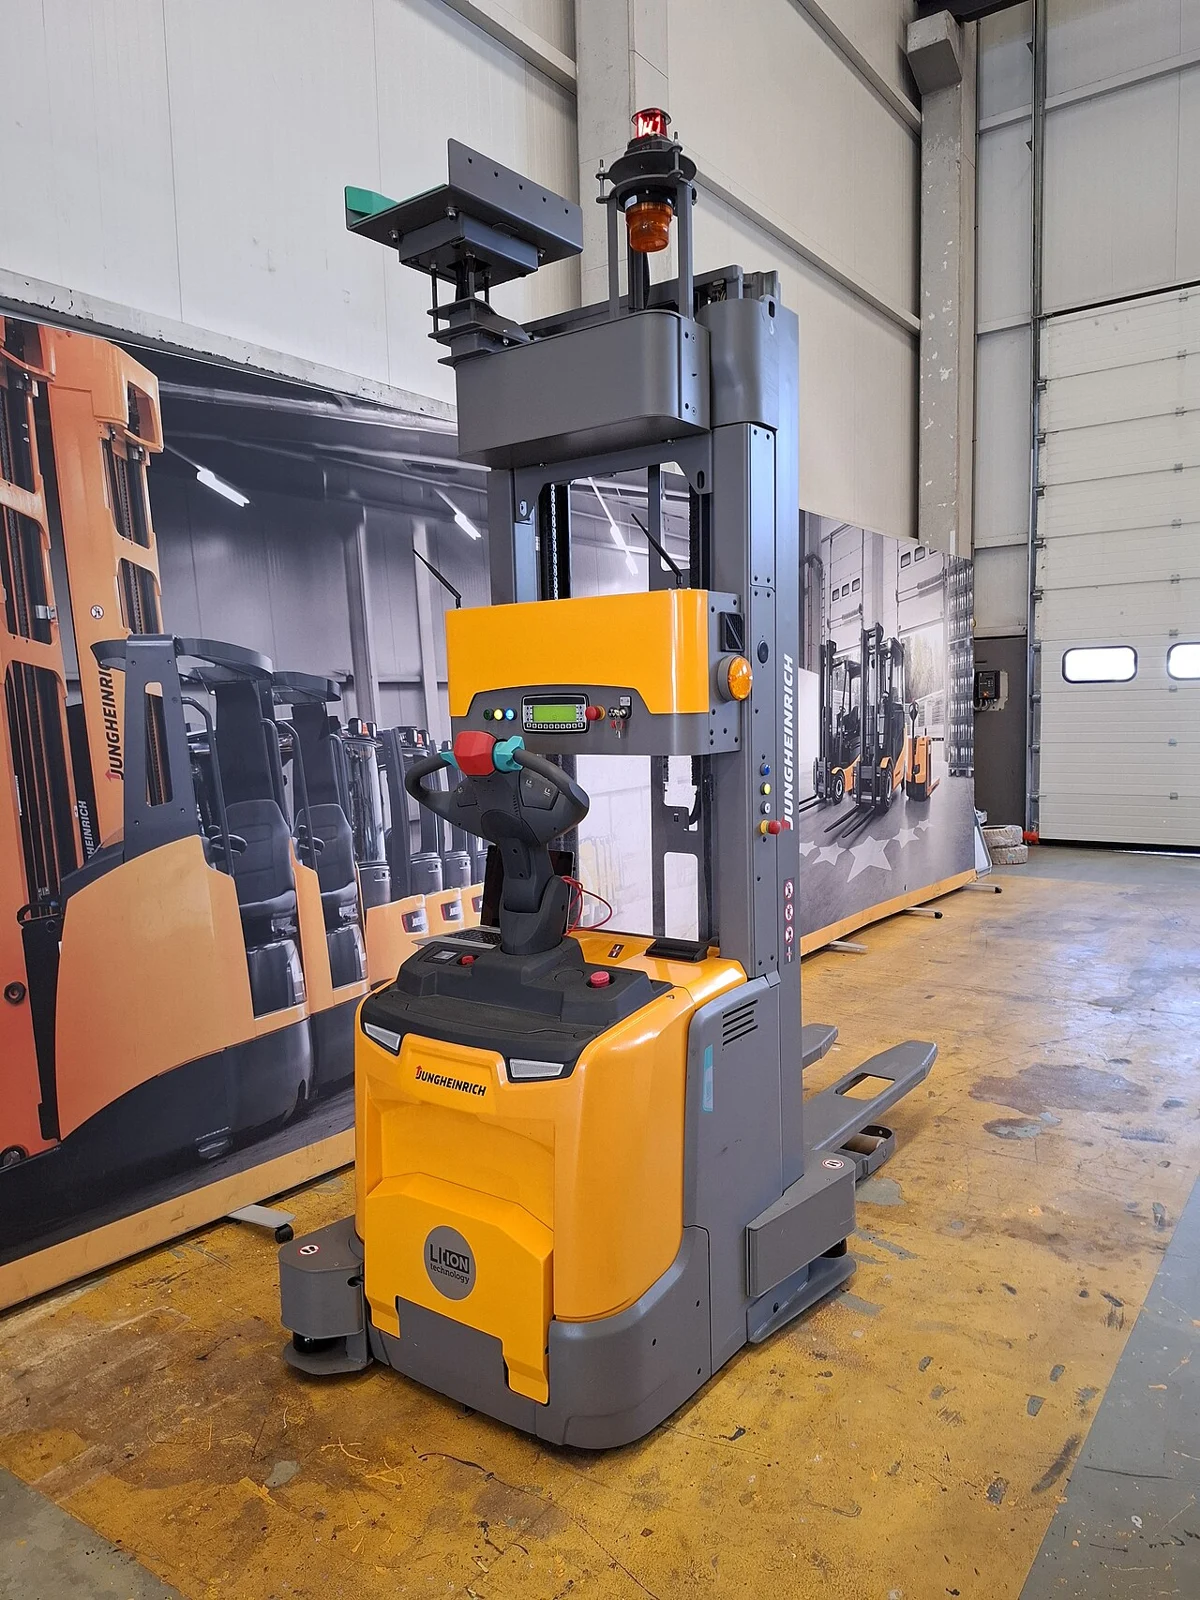
A Jungheinrich automated industrial truck
Robotics

Robot-Agnostic Fleet Management Software Explained

Learn how robot-agnostic fleet management software coordinates multi-vendor robots through adapters, shared maps, traffic rules, missions and telemetry.

Read article
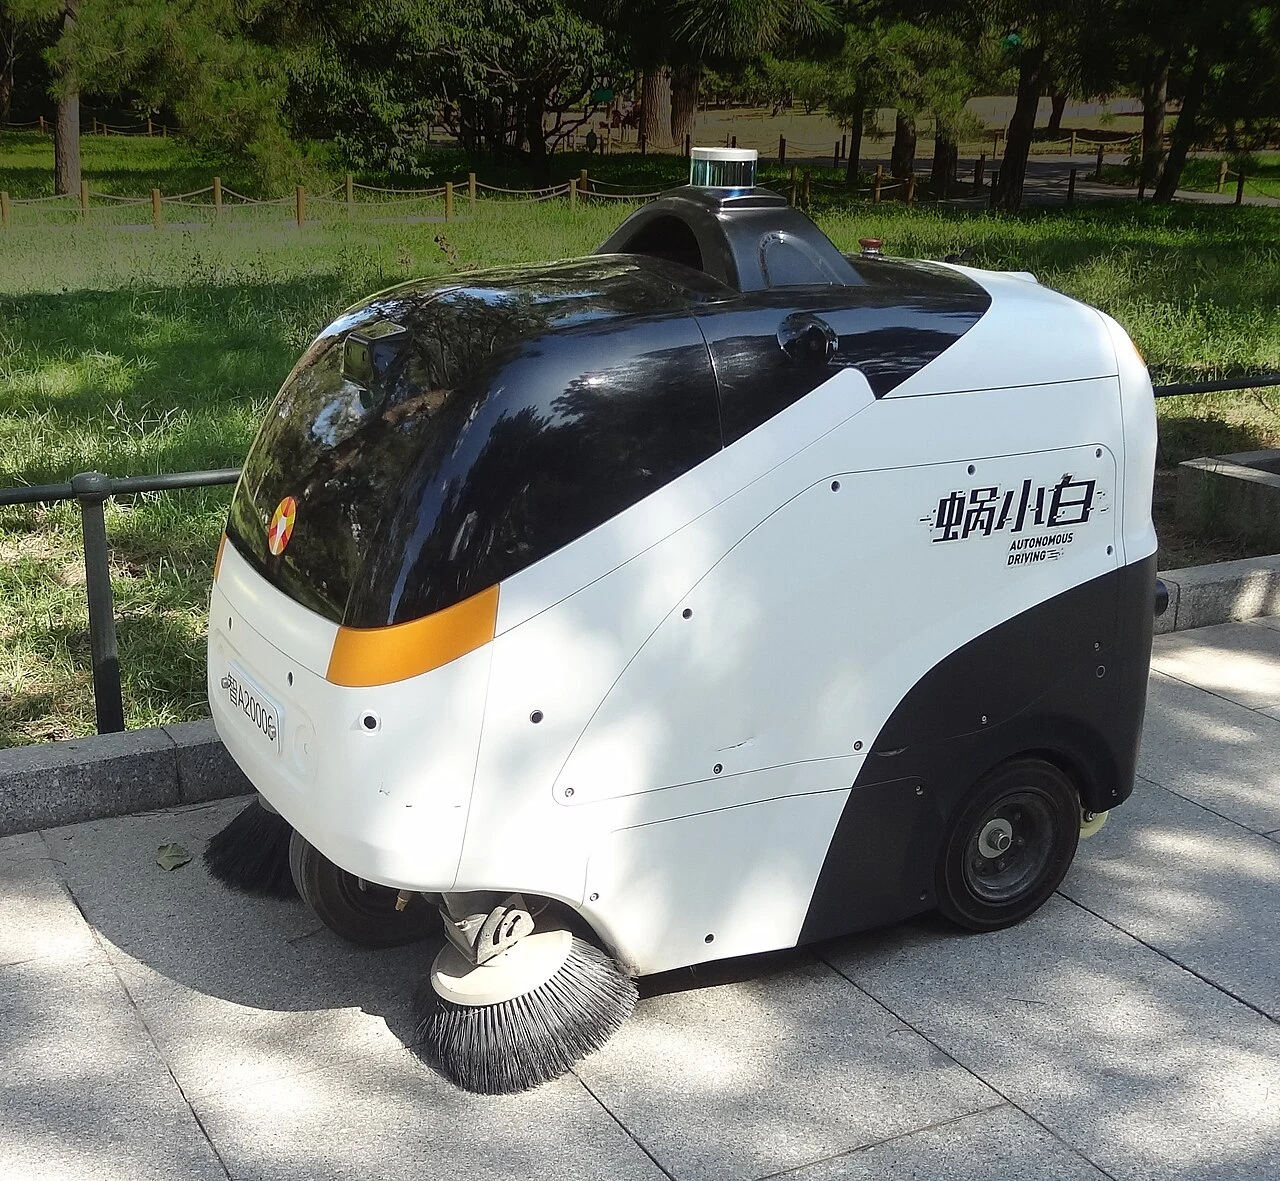
An autonomous cleaning robot at Beijing Botanical Garden
Robotics

Cleaning Robot Management Software Facility Guide

Evaluate cleaning robot management software by supported brands, mission scheduling, maps, reports, alerts, remote assistance, security and service workflows.

Read article
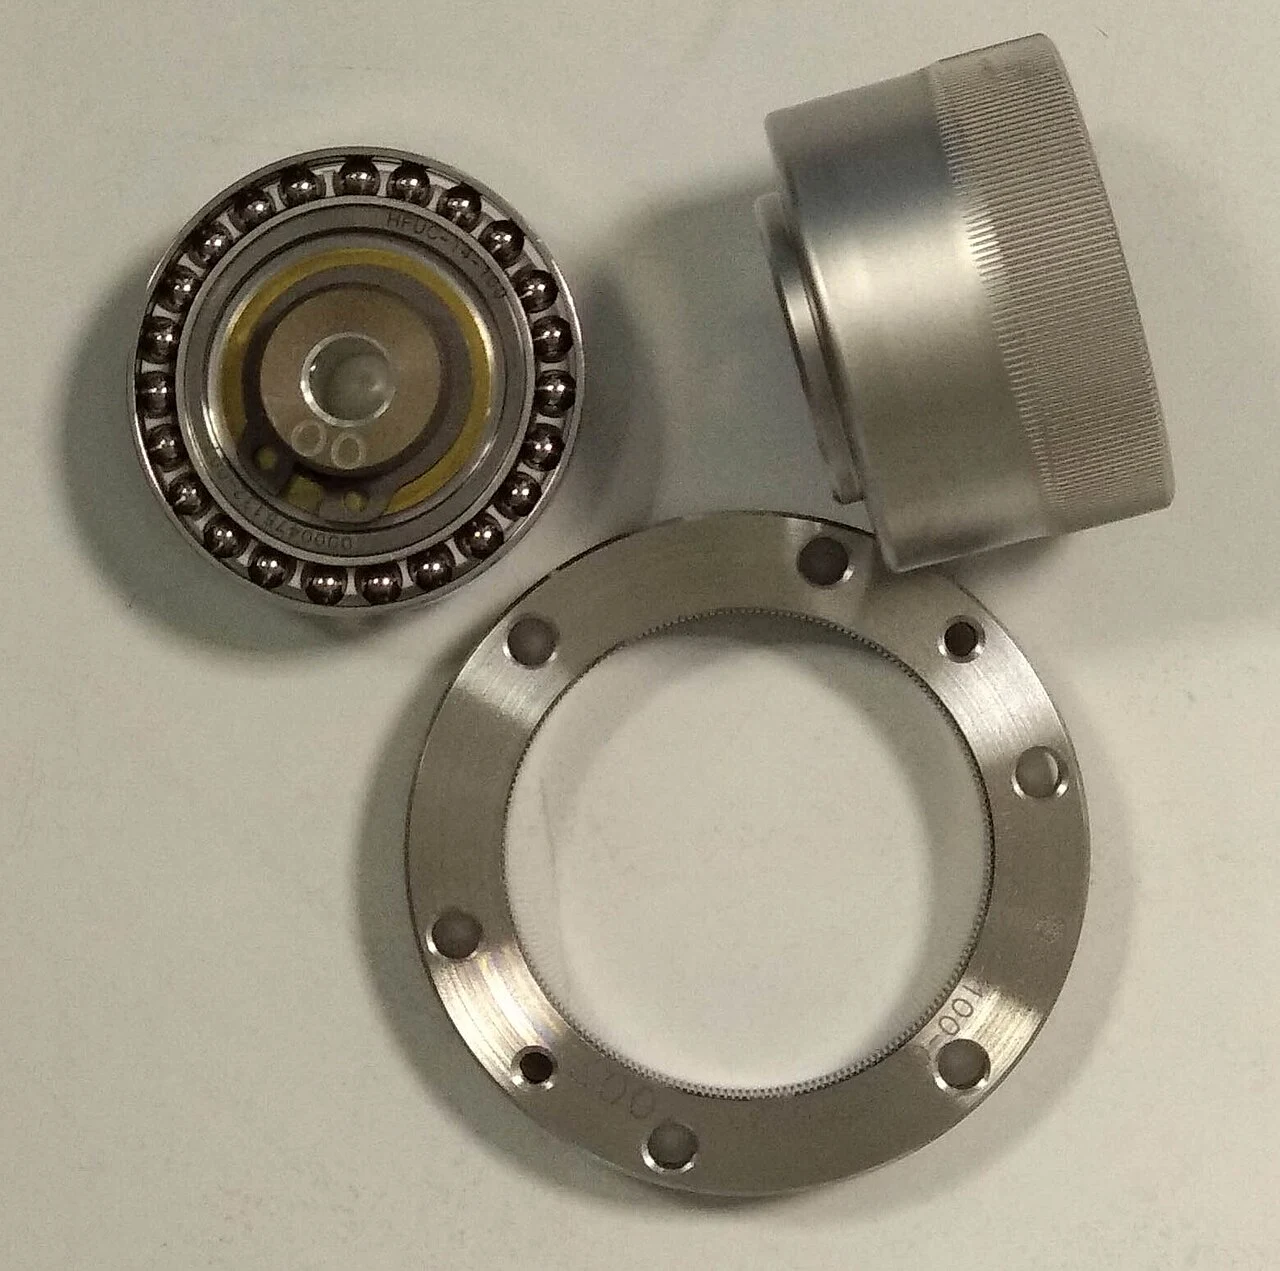
Components of a Harmonic Drive strain wave gear
Robotics

Robotics Component Manufacturers and Suppliers Guide

Find robotics component manufacturers for motors, reducers, encoders, cameras, LiDAR, grippers, force sensors, computers, batteries and safety hardware.

Read article
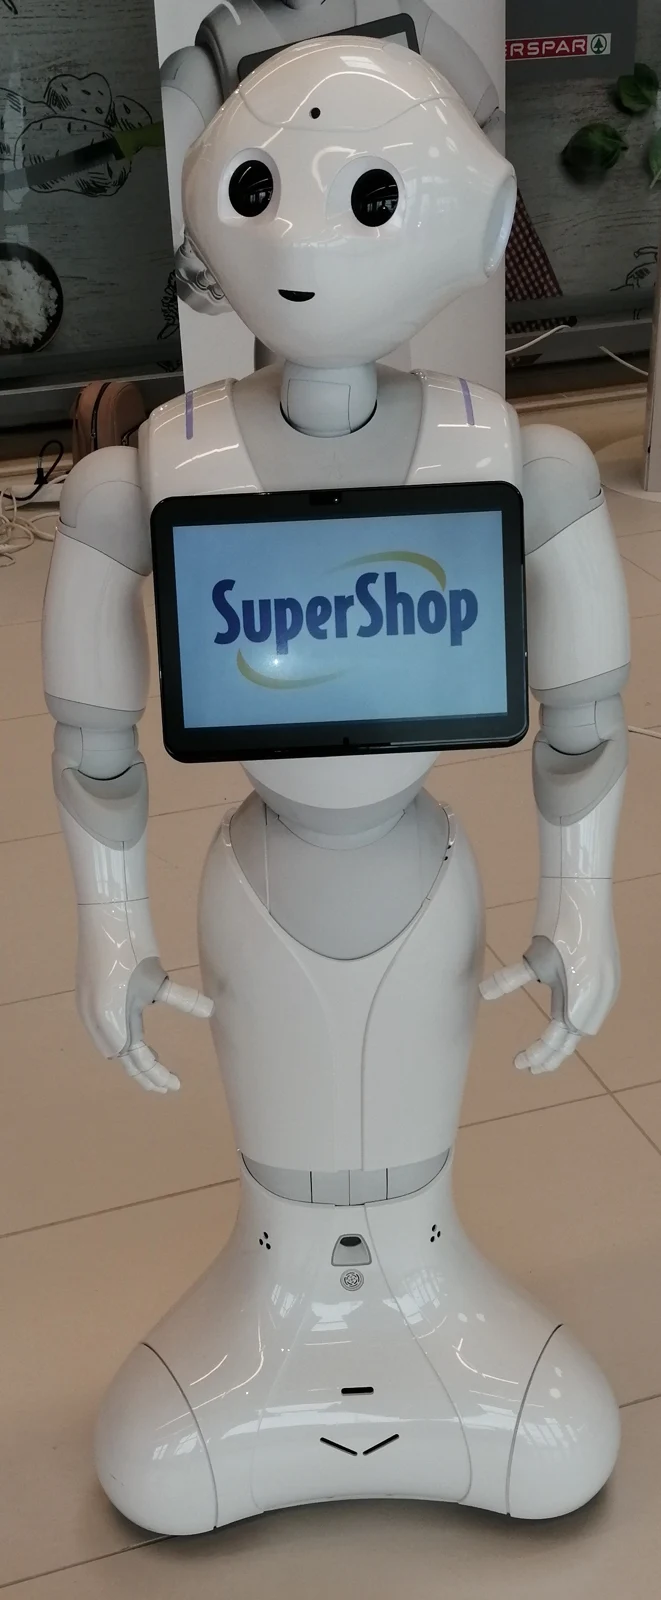
A Pepper robot used for human interaction
Robotics

Entertainment Robotics Market Categories and Venue Checks

Understand entertainment robotics across attractions, social robots, toys and live performance, with operating and venue checks.

Read article
Narrow robotic gripper handling a laboratory plate
Robotics

Robotics Training Data Services and Collection Guide

Plan robotics training data collection through teleoperation, demonstrations, video, force sensing, metadata, quality review, consent and dataset governance.

Read article
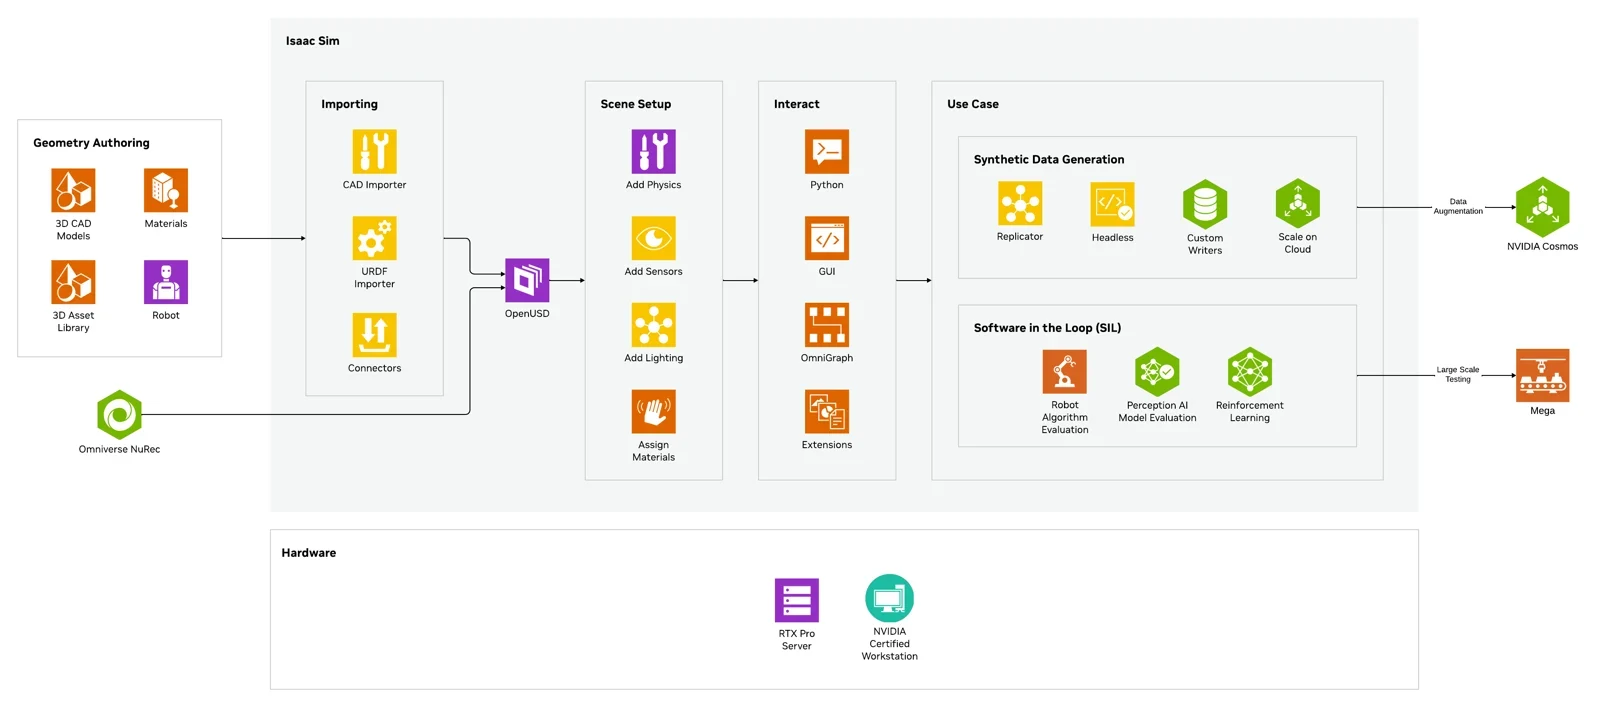
NVIDIA's diagram of the Isaac Sim software ecosystem
Robotics

How to Use NVIDIA Isaac Sim Without a GPU

Run NVIDIA Isaac Sim without a local RTX GPU by using a remote NVIDIA GPU, browser streaming, Unitree H1, URDF import and Isaac Lab. A practical step-by-step guide.

Read article
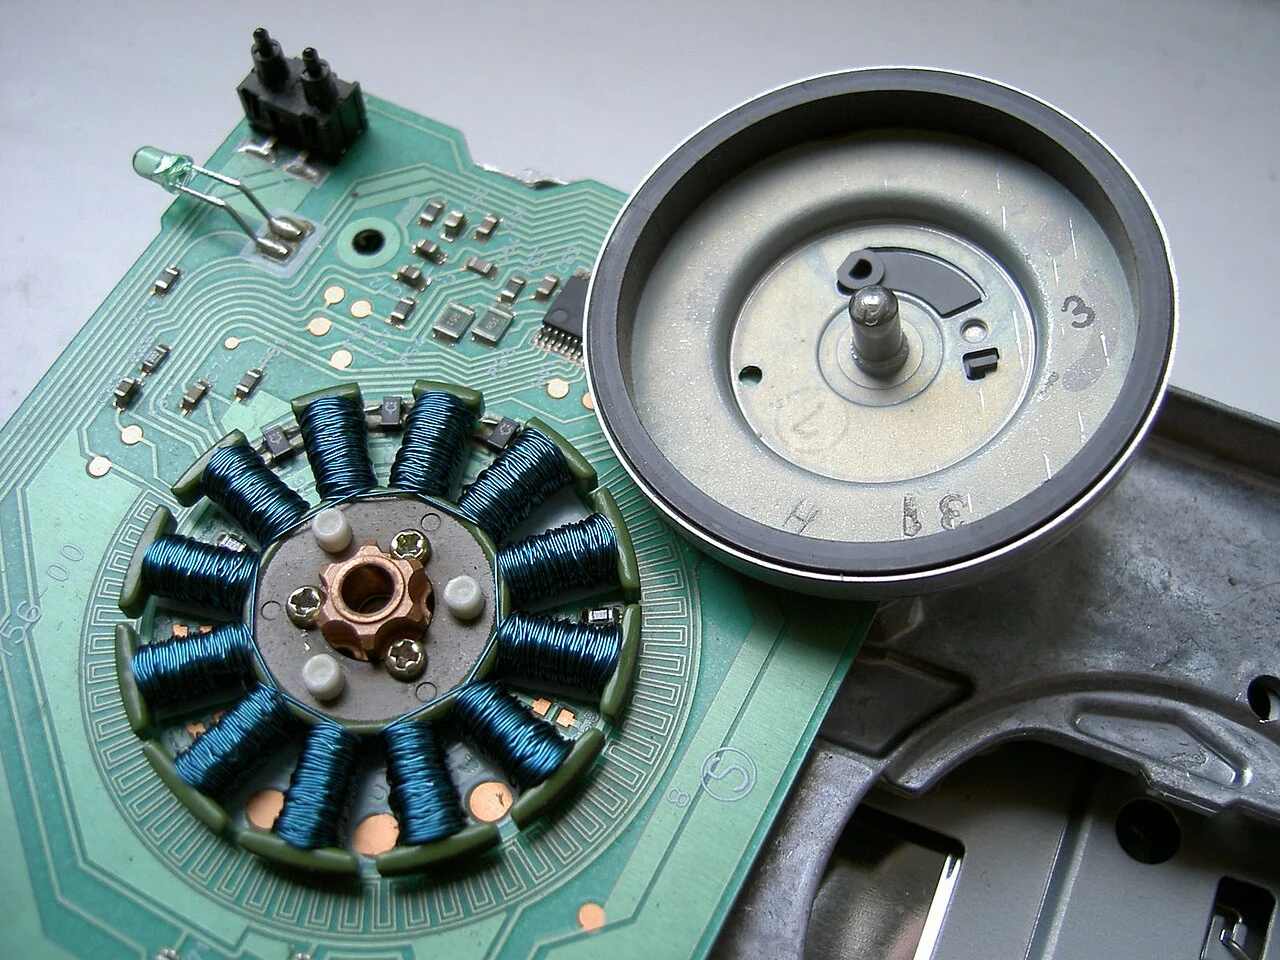
A disassembled brushless motor showing stator coils and Hall sensors
Robotics

Motor Sensing for Warehouse Robotics

Design motor sensing for warehouse robotics with encoders, current, temperature, torque, vibration and fault logic for AMRs, conveyors and picking systems.

Read article
A robot arm and gripper in NIST's dexterous manipulation testbed
Robotics

Warehouse Robotic Picking Systems Complete Guide

Understand warehouse robotic picking systems from cameras and grippers to motion planning, conveyors, WMS integration, exception handling and safety.

Read article
An Intel RealSense D435 stereo depth camera
Robotics

Stereo and 3D Cameras for Robotics Compared

Compare Intel RealSense D455, Stereolabs ZED 2i and Basler blaze by depth method, range, field conditions, interfaces and robotics integration.

Read article
An industrial arm mounted on a mobile robot base
Robotics

AMR Robot Companies for Warehouse Automation

Compare AMR robot companies for warehouses by workflow, navigation, fleet software, payload handling, charging, safety and integration evidence.

Read article
A demonstration of a ReWalk assistive exoskeleton
Robotics

Assistive Robotics Supplier Categories and Buyer Checks

Understand supplier categories for mobility, rehabilitation, manipulation and care, with user eligibility, evidence and support checks.

Read article
NASA's Valkyrie humanoid robot
Robotics

Humanoid Robot Operating Hours, Charging and Uptime

Estimate humanoid robot operating hours by battery, task intensity, charging, thermal limits, maintenance and human intervention instead of one headline runtime.

Read article
A robotic exoskeleton on display
Robotics

Exoskeleton Control Systems Sensors and Safety

Understand exoskeleton control systems using joint encoders, IMUs, force sensors, pressure, EMG and intent detection with layered safety.

Read article
Archive photograph of KUKA robots on a car body assembly line
Robotics

Robotic Production Line Design and Integration Guide

Design a robotic production line around process flow, robot cells, PLCs, conveyors, vision, tooling, safety, quality checks and maintenance.

Read article
A shielded ZVL deep groove ball bearing
Robotics

Robotic Arm Linkage Bearings Selection Guide

Select robotic arm linkage bearings by radial, axial and moment load, stiffness, backlash, speed, lubrication, sealing and joint packaging.

Read article
Automated vehicles transporting shipping containers
Robotics

Transport Robots for Factories, Hospitals and Warehouses

Compare transport robots for factories, hospitals and warehouses by payload, load transfer, navigation, fleet control, safety and workflow integration.

Read article
A robot used in warehouse transport
Warehouse automation

Warehouse Sorting Robots The Traffic System Behind the Moving Floor

A viral warehouse video shows many small mobile robots carrying parcels across a shared sorting floor while people load packages at the perimeter. The visible robots are only one layer of the system. The harder engineering problem is coordinating routes, destinations, congestion, charging and exceptions without bringing the floor to a stop.

Read article
A Tesla Optimus humanoid on display
AI, robotics and economics

Why Elon Musk Says Money May Stop Mattering by 2036

In a July 2026 interview with The Economist editor-in-chief Zanny Minton Beddoes, Elon Musk argued that AI and robots could make goods and services so abundant that money would matter far less within ten years. The statement is a prediction about production and scarcity, not evidence that currency will literally disappear.

Read article
An expressive humanoid face developed by AheadForm
Social and expressive robots

China’s Humanoid Robot Faces AheadForm, AnyWill and DroidUp Compared

A comparison video places humanoid faces associated with AheadForm, AnyWill Robotics and DroidUp side by side. The faces show how quickly eye motion, skin materials and expression control are improving, but appearance alone says little about perception, reasoning, mobility or real-world reliability.

Read article
Xynova's product image of its FLEX 2 dexterous robotic hand
Humanoid manipulation

Xynova Robot Handwriting Demo What Drawing With a Marker Actually Tests

A Xynova robot hand holds a marker and draws simple shapes on paper. The movement looks modest, yet handwriting combines grasp stability, tool angle, contact force and precise path control in one contact-rich task.

Read article
Humanoid and quadruped robots at the Japan Mobility Show 2025
Humanoid robot manufacturing

China vs the US Humanoid Robot Race Production Claims Need Better Metrics

A comparison video places China’s UBTECH and EngineAI beside the US company Figure and highlights production announcements made between October 2025 and May 2026. The comparison captures a genuine difference in industrial strategy, but production capacity, first-batch assembly, shipments and productive customer hours must be separated.

Read article
Unitree's product image of the G1 humanoid robot
Human-robot safety

Unitree Robot Near a Child Why Demonstration Safety Starts Before Motion

A short video shows a Unitree humanoid robot moving energetically near a small child. The framing is humorous, but the safety question is concrete was the child inside the robot’s reachable motion area before the action began, and what controls were available to stop the machine?

Read article
A NASA Snakebot research prototype
Open-source research robots

Open-Source Snake Robot With ROS Control and Seven Dynamixel Joints

An open-source robot project uses seven Robotis Dynamixel MX-28AR servos to create a programmable snake-like body controlled through ROS Kinetic and ROS Control. The public repository documents the software and joint architecture, but it does not certify the machine for underwater operation.

Read article
Archive photograph of a Scheuerle modular transporter moving a building
Autonomous and specialized vehicles

What Is the Giant New-Energy Vehicle in This Viral Road Video?

A road video shows a massive low-profile vehicle with an unconventional industrial appearance. The original caption calls it a new-energy vehicle without a combustion engine or gasoline, but the footage does not reveal a manufacturer badge, model name, charging interface or control system.

Read article
A robot walking outdoors in RoboParty's ROBOTO ORIGIN demonstration
Open-source humanoid robots

RoboParty ROBOTO ORIGIN How AMP Gait Training Supports Push Recovery

RoboParty publishes ROBOTO ORIGIN as an open-source humanoid platform with hardware guidance and locomotion training and deployment code. In the associated demonstration, the robot remains upright after a sideways disturbance, showing a controller correcting body motion instead of holding a fixed pose.

Read article
A POK Jupiter firefighting robot at a fire equipment exhibition
Emergency response robots

Firefighting Rescue Robots When Should a Robot Enter Before a Firefighter?

An indoor demonstration shows quadruped robots carrying cameras and firefighting equipment beside a wheel-leg platform designed for difficult terrain. The footage raises a serious operational question when can a robot reduce risk by entering before a firefighter, and when would deployment delay the rescue?

Read article
Robonaut 2 shaking hands with an astronaut
Physical human-robot interaction

Humanoid Robot Massage Safety What Must Work Before Body Contact

A viral clip shows a humanoid robot making repeated contact with a person’s body in a massage-like demonstration. The scene is memorable because a small control error could turn intended pressure into a painful strike. Safe body contact requires a different standard from moving objects on a workbench.

Read article
Unitree Robotics headquarters in Hangzhou
Humanoid robot industry

China Has More Than 150 Humanoid Robot Companies. How Many Can Survive?

China’s humanoid robot sector now contains more than 150 companies, according to an official Chinese government report. The number shows industrial momentum, but it also raises a harder question about duplicated products, weak demand and which manufacturers can survive the transition from demonstrations to paid work.

Read article
A Waymo autonomous taxi on a city street
Autonomous vehicles

Waymo vs Tesla Robotaxi Technology, Safety and Availability

Waymo vs Tesla Robotaxi compared by sensors, maps, supervision, safety evidence, remote support and public availability, verified July 15, 2026.

Read article
A Universal Robots UR16e arm and its teach pendant
Industrial robotics

Robotic Arm Cost in 2026 Robot, Gripper, Safety and Integration

Robotic arm cost explained with grippers, vision, safety, controls, engineering, maintenance and five transparent 2026 cell budget scenarios.

Read article
A da Vinci Xi surgical robot in an operating room
Medical robotics

Da Vinci Surgical Robot How It Works, Cost and Alternatives

Da Vinci surgical robot guide covering surgeon control, 3D vision, articulated instruments, costs, training, clinical risks and alternatives.

Read article
NASA Astrobee robots aboard the International Space Station
Robotics software

Best Robotics Programming Languages Python, C++, RAPID and KRL

Robotics programming languages compared by task Python, C++, ROS 2, RAPID, KRL, URScript, FANUC TP, INFORM, MATLAB, Simulink and JavaScript.

Read article
A KUKA KR Quantec robot at an industrial exhibition
Industrial robotics

FANUC vs ABB vs KUKA vs Yaskawa Industrial Robots Compared

FANUC vs ABB vs KUKA vs Yaskawa compared by robot ranges, controllers, offline software, safety, service, applications and integration cost in 2026.

Read article
Velodyne lidar sensors with different form factors
Robot navigation

Visual SLAM vs LiDAR SLAM Accuracy, Cost and Robot Applications

Visual SLAM vs LiDAR SLAM compared for accuracy, lighting, glass, dust, compute, drift, 3D mapping, sensor fusion and mobile robot applications.

Read article
A powered wearable exoskeleton
Wearable robotics

Best Exoskeleton Robots 2026 Medical and Industrial Systems

Best exoskeleton robots in 2026 compared by medical use, industrial support, actuation, training, certification, pricing and practical limits.

Read article
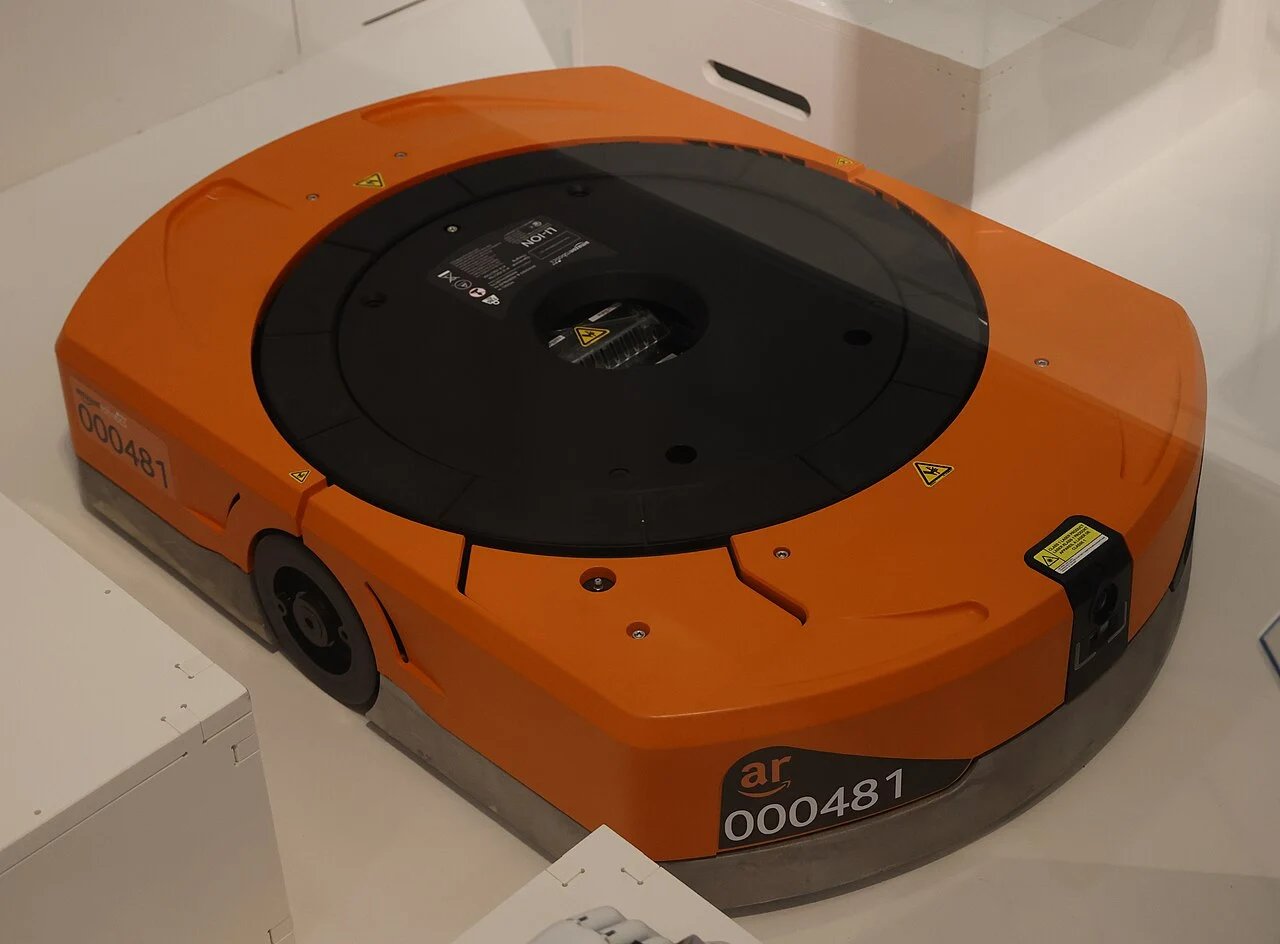
An Amazon warehouse robot photographed in 2020
Logistics robotics

Warehouse Automation Cost AMRs, Robots and ROI Explained

Warehouse automation cost and ROI modeled with AMRs, fleet software, WMS integration, charging, safety, support and transparent assumptions.

Read article
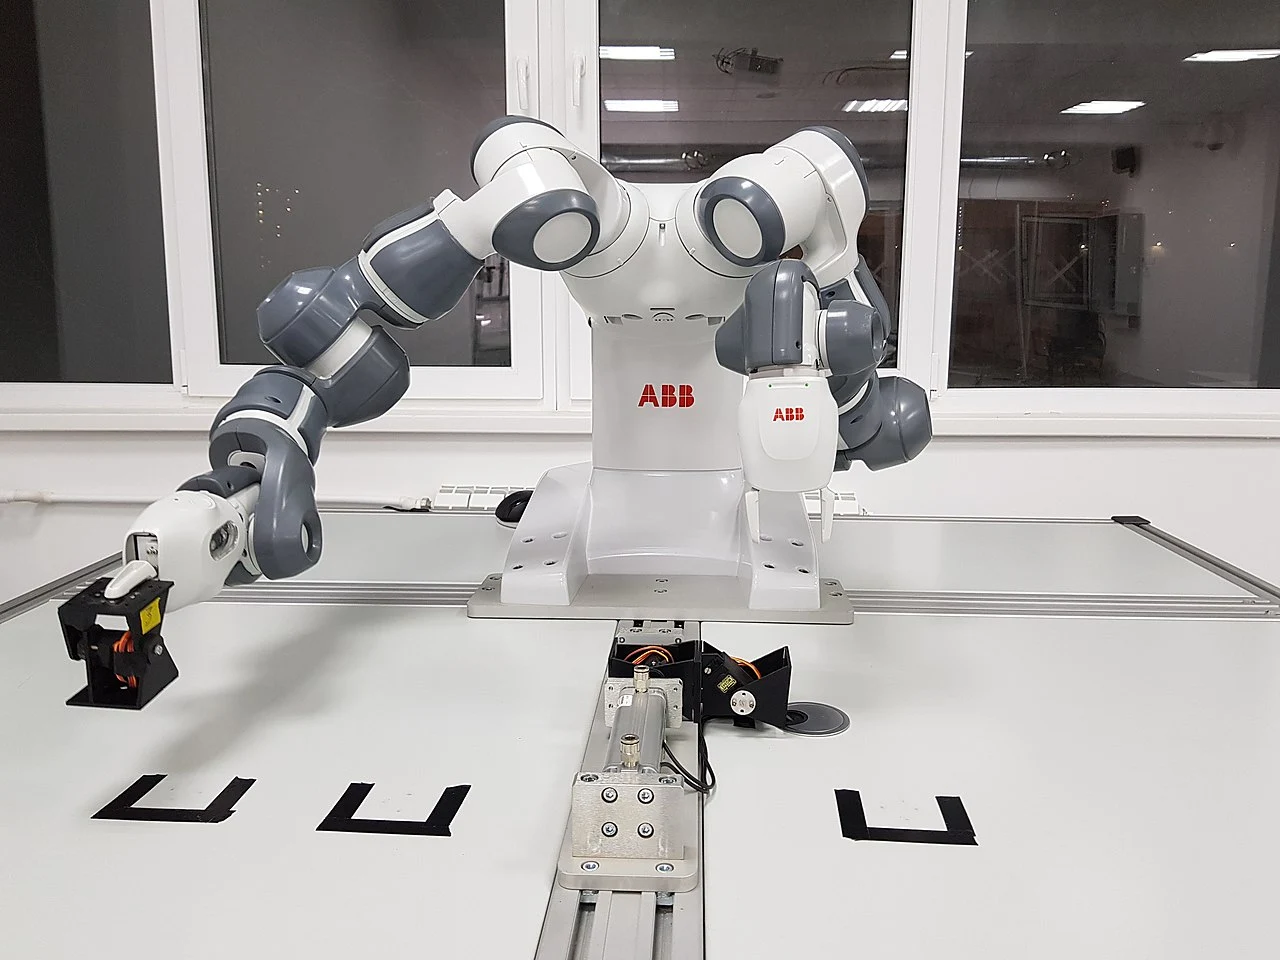
An ABB dual-arm robot in a robotics laboratory
Robotics education

Best Robotics Courses and Certifications for Engineers in 2026

Best robotics courses and certifications for Python, C++, ROS 2, controls, simulation, industrial robots and safety, verified on July 15, 2026.

Read article
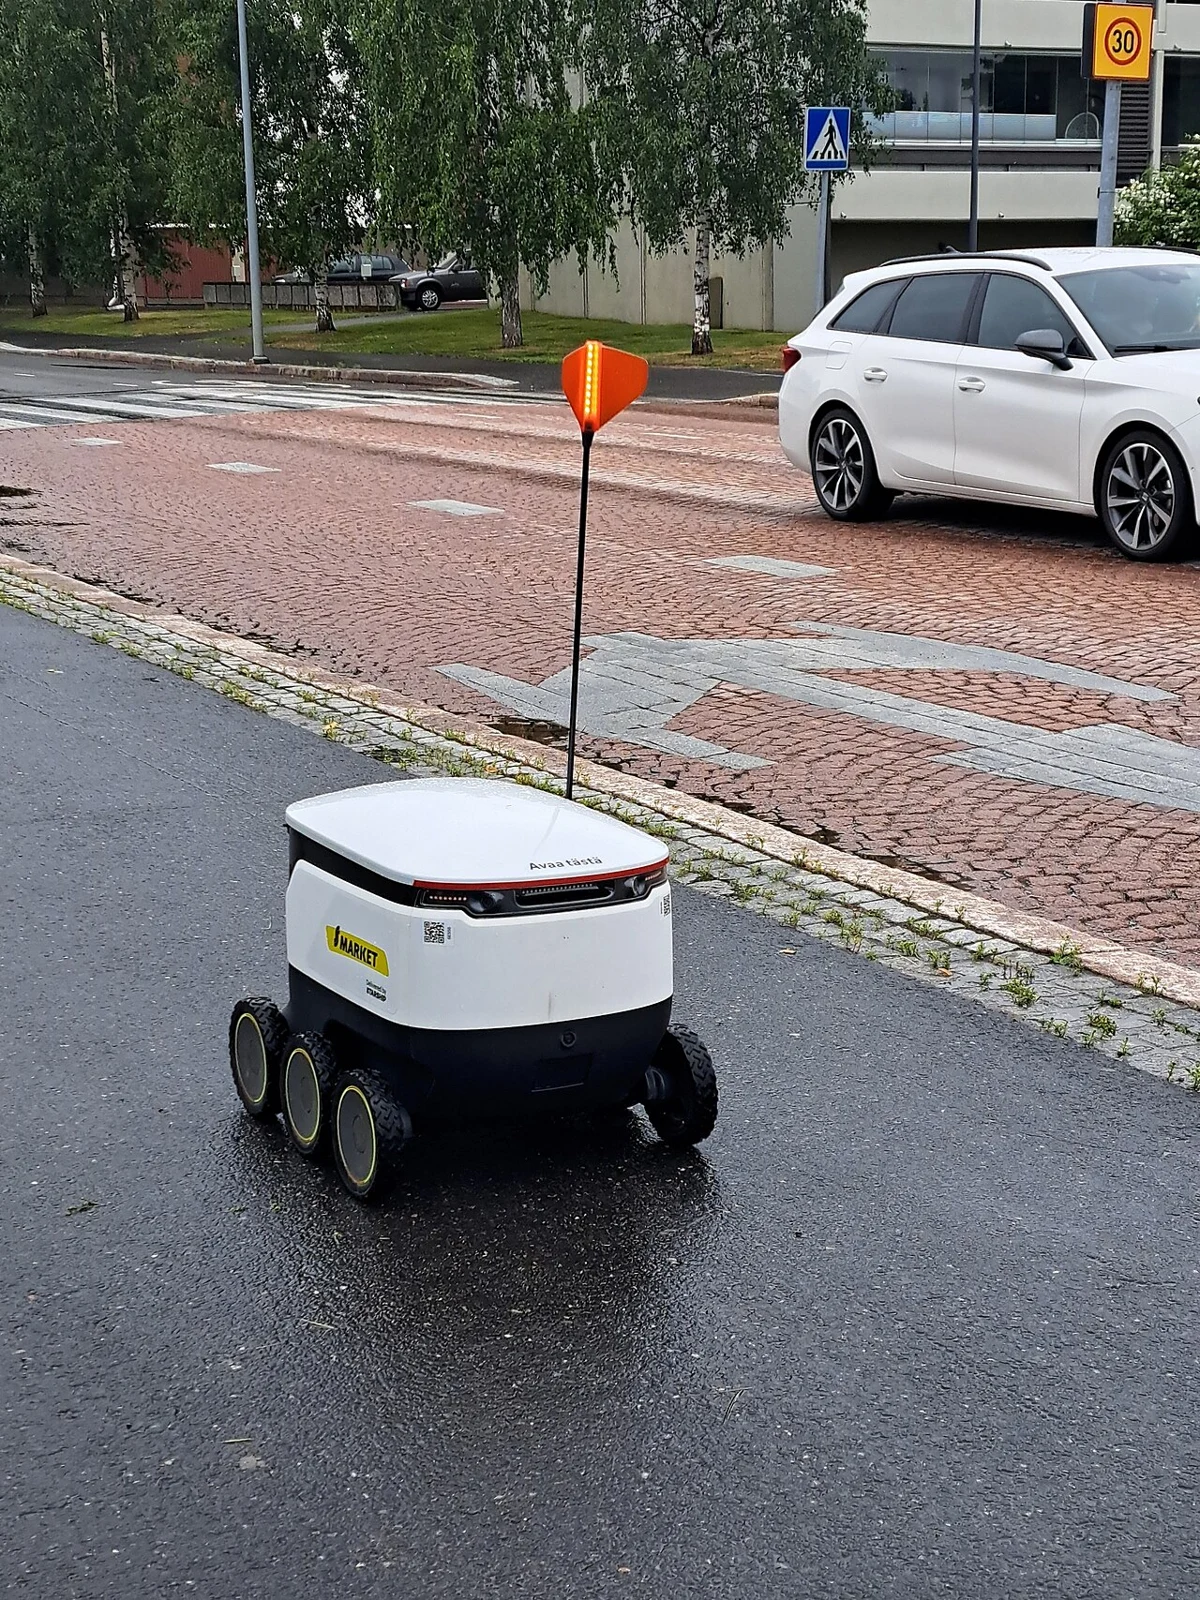
A Starship delivery robot in Oulu, Finland
Delivery robotics

Autonomous Delivery Robots Starship, Serve, Nuro and Kiwibot

Autonomous delivery robots compared by vehicle type, sensors, remote assistance, operating area, payload, service status and human intervention.

Read article
A robotic vacuum cleaner on a floor
Robotics

Best AI Robot Vacuums in 2026 What Actually Matters

Compare leading AI robot vacuums in 2026 by navigation, object detection, mopping, dock automation, privacy, maintenance and real household limits.

Read article
A robotic arm in a laboratory work area
Robotics

Robotics Engineer Salary in 2026 A Role-by-Role Guide

Understand robotics engineer salary in 2026 using official occupation data, role differences, location, experience, hardware skills and total compensation.

Read article
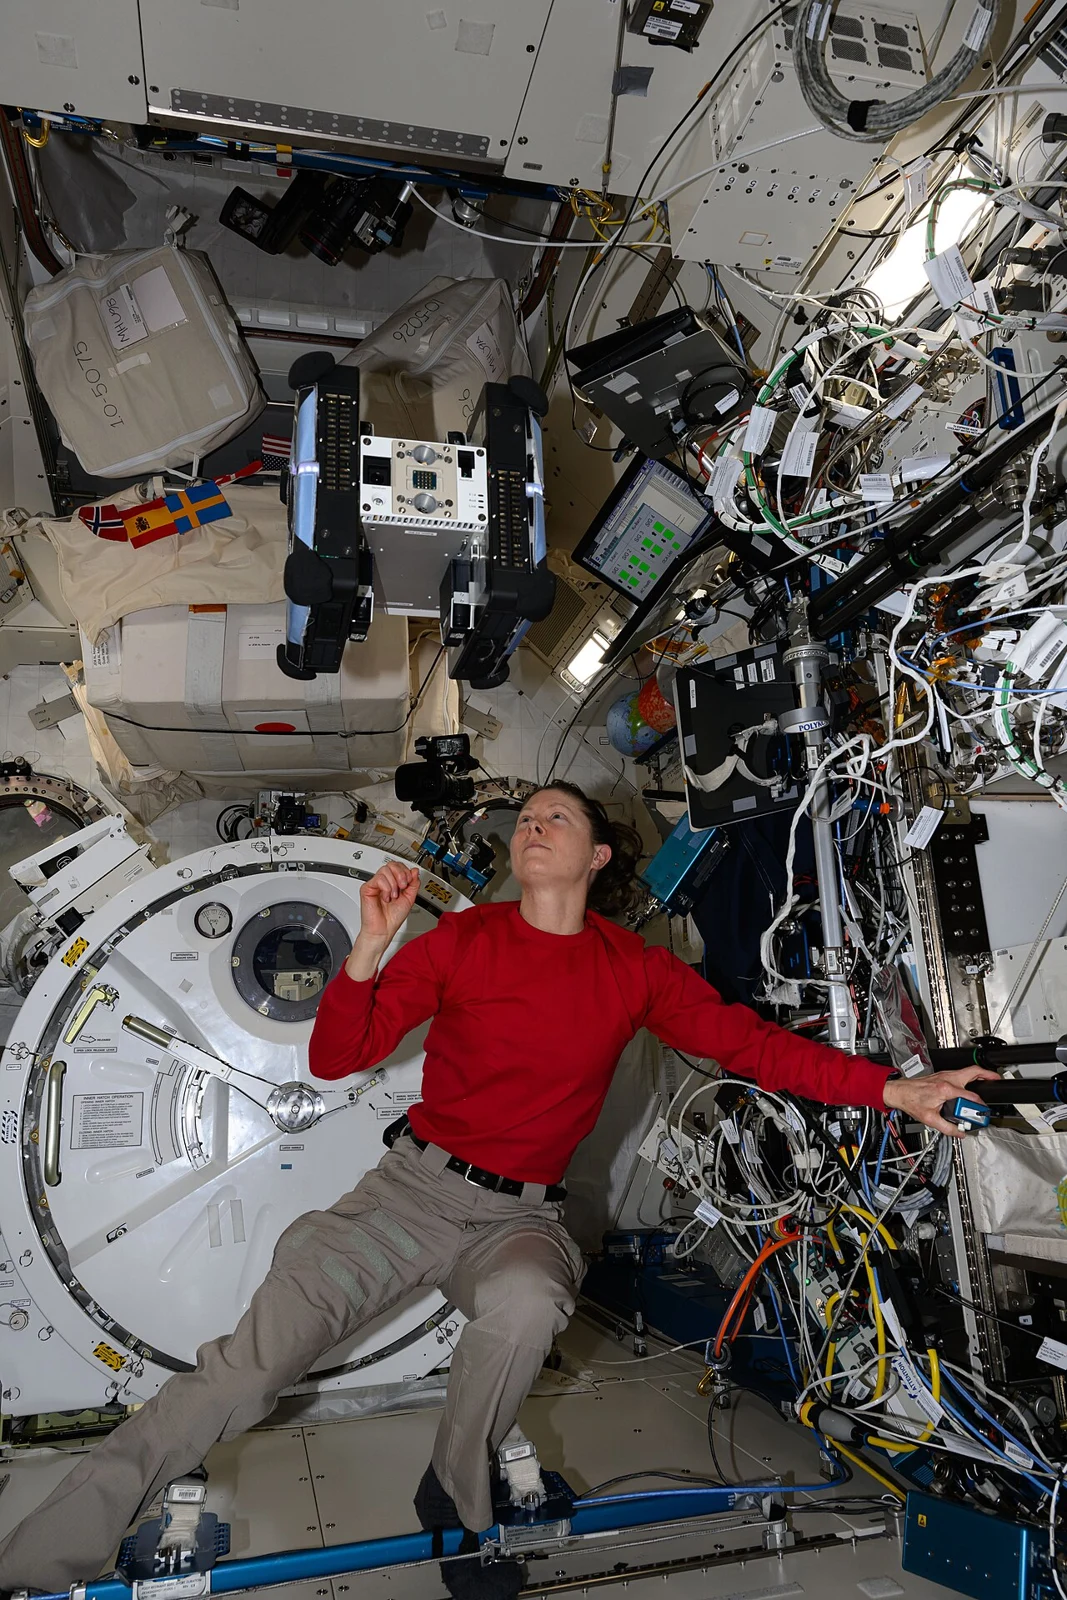
NASA astronaut Tracy Dyson monitoring Astrobee for a student robotics experiment
Robotics

How to Become a Robotics Engineer in 2026

A practical robotics engineer roadmap for 2026 covering math, mechanics, electronics, C++, Python, ROS 2, projects, portfolios and job preparation.

Read article
A TurtleBot3 Burger mobile robot
Robotics

ROS 2 Tutorial for Beginners Build a Small Robot Graph

Learn ROS 2 with a practical beginner workflow covering installation, nodes, topics, services, parameters, launch files, bags, TF and Gazebo.

Read article
A LEGO Mindstorms NXT educational robot
Robotics

Best Robotics Kits for Beginners and Students in 2026

Compare robotics kits for beginners and students by controller, sensors, programming, ROS 2 support, assembly, documentation, cost and upgrade path.

Read article
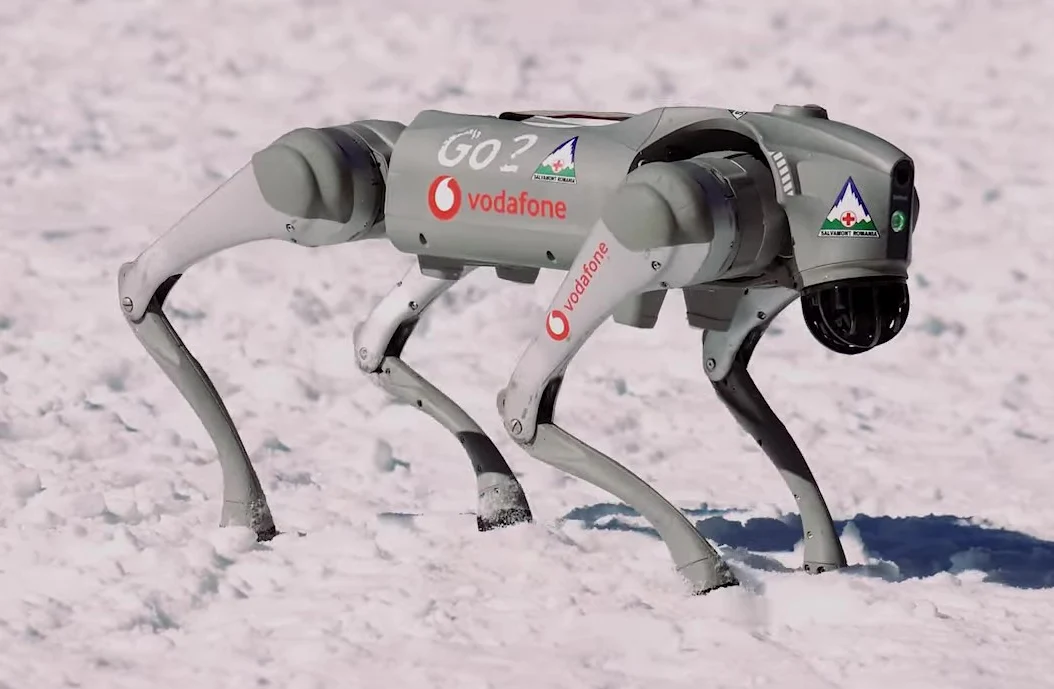
A Unitree Go2 quadruped used by the Salvamont rescue service
Robotics

Robot Dog Prices in 2026 Consumer and Industrial Costs

Compare robot dog prices in 2026, from consumer quadrupeds to inspection platforms, including software, payload, support, shipping and integration costs.

Read article
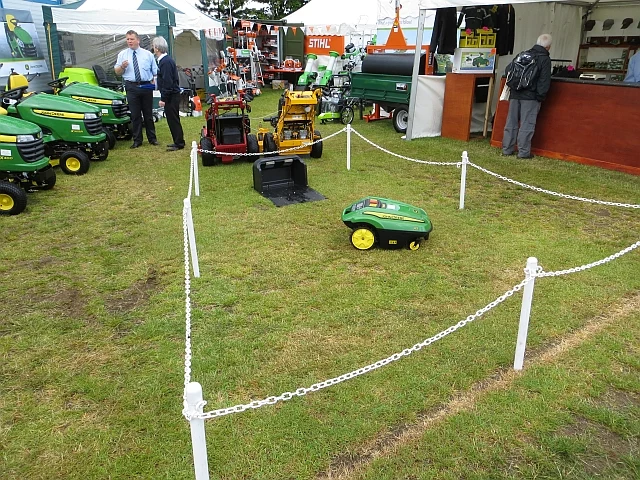
Robotic lawn mowers operating on grass
Robotics

Robot Lawn Mower Technology RTK, Vision and LiDAR

Learn how robot lawn mowers use boundary wires, RTK, cameras and LiDAR, where each navigation method fails and what installation and maintenance really require.

Read article
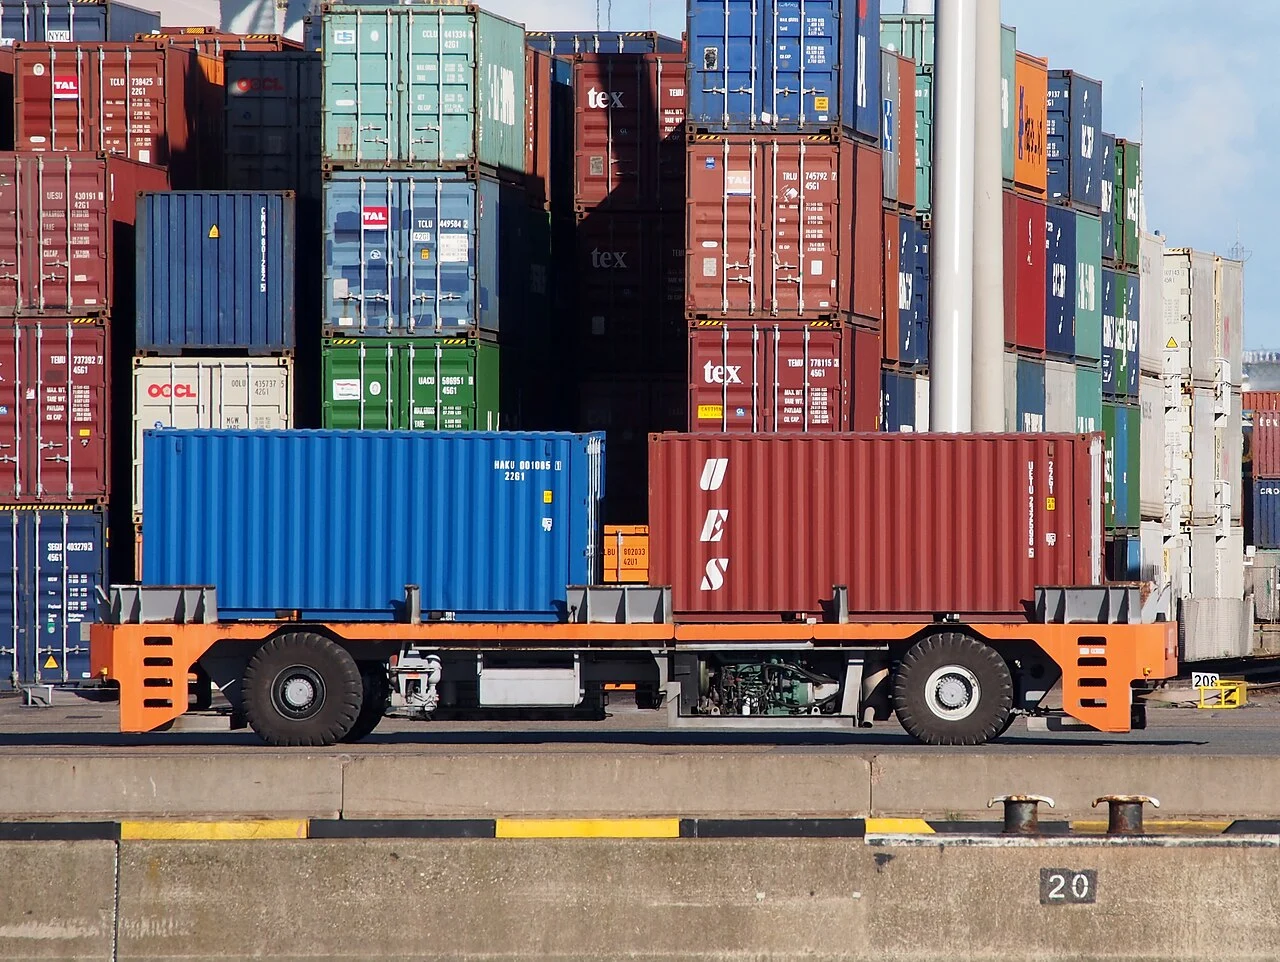
An automated guided vehicle carrying a shipping container
Robotics

AMR vs AGV Navigation, Safety, Cost and Use Cases

Compare AMR vs AGV navigation, infrastructure, safety, fleet software, throughput and cost to choose the right mobile robot for a factory or warehouse.

Read article
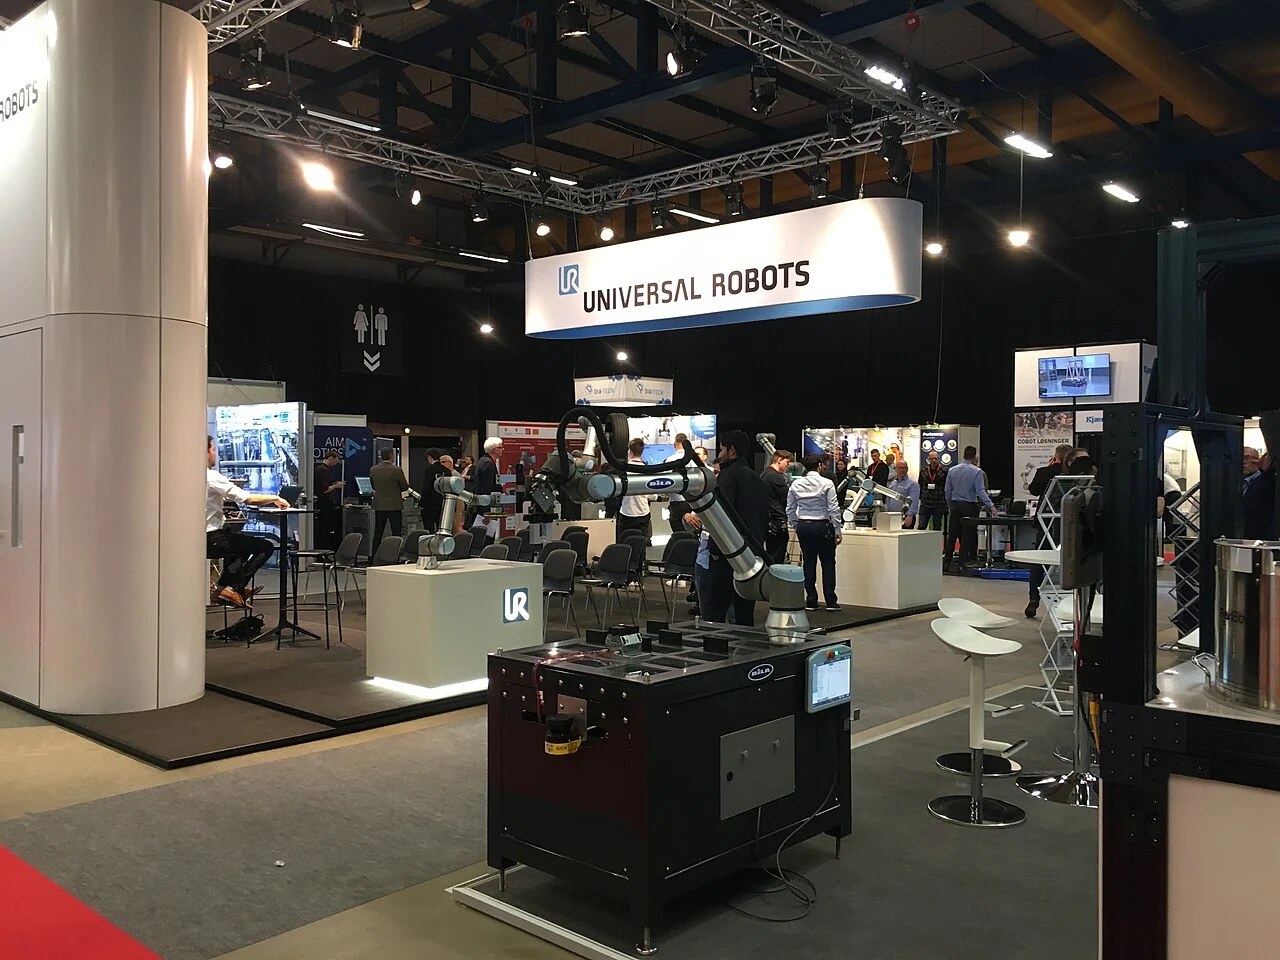
Universal Robots at a robotics trade fair
Robotics

Cobots vs Industrial Robots Safety, Speed and Cost

Compare cobots vs industrial robots by payload, speed, safety, guarding, programming, cycle time and total deployment cost for real automation projects.

Read article
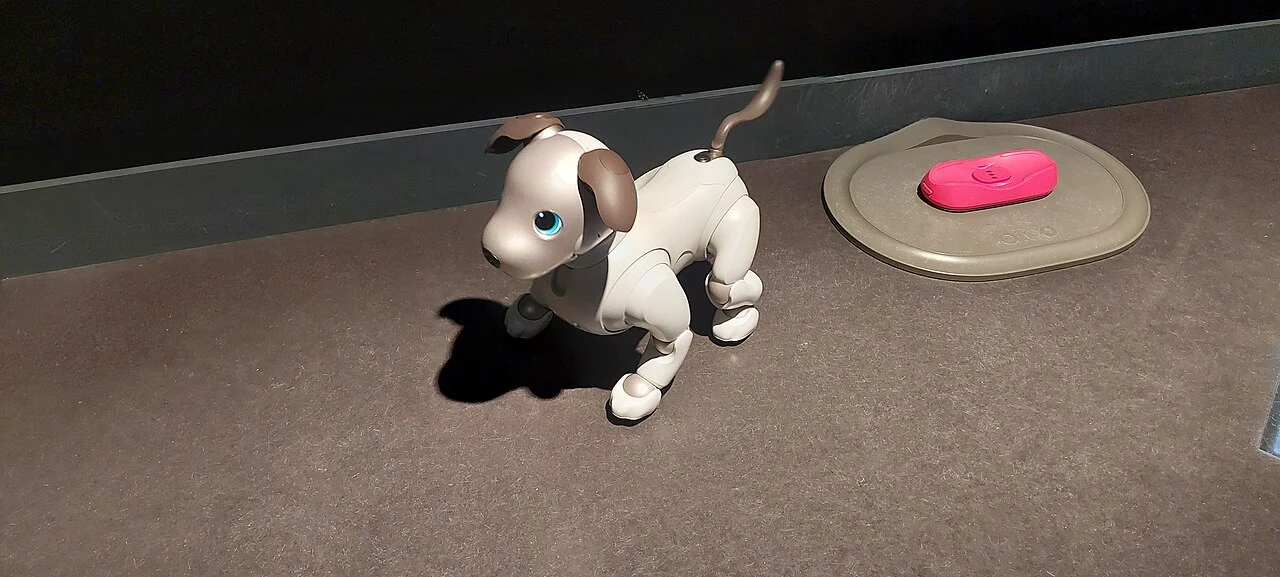
A Sony AIBO robotic dog on display
Robotics

AI Robot Pets in 2026 Companion Robots Compared

Compare AI robot pets in 2026 by movement, sensors, interaction, privacy, subscription, repairability and their limits as companions or therapeutic devices.

Read article
Editorial graphic showing the LingBot-VLA 2.0 open-source code, 6B weights and 20 robot configurations
Open-source robot foundation models

LingBot-VLA 2.0 Open Source Release and Robot Coverage

Robbyant has published the LingBot-VLA 2.0 codebase and a 6B pretrained checkpoint. The official pretraining total is about 60,000 hours 50,000 hours of cleaned robot trajectories plus 10,000 hours of filtered egocentric human video.

Read article
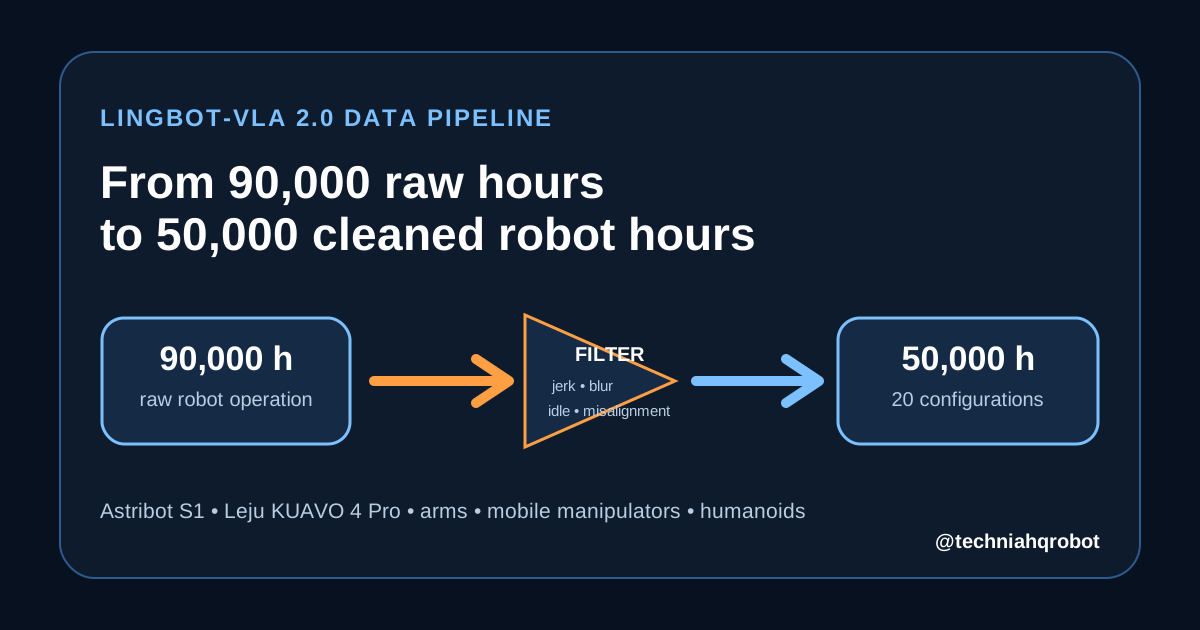
Editorial diagram showing 90,000 raw robot-operation hours filtered into 50,000 cleaned hours across 20 robot configurations
Robot foundation model data

How LingBot-VLA 2.0 Filters 90,000 Raw Robot Hours

Robbyant collected about 90,000 hours of physical robot operation and retained 50,000 hours of high-quality robot trajectories after filtering. The official paper lists 20 robot configurations spanning arms, mobile manipulators, half-humanoids and humanoids.

Read article
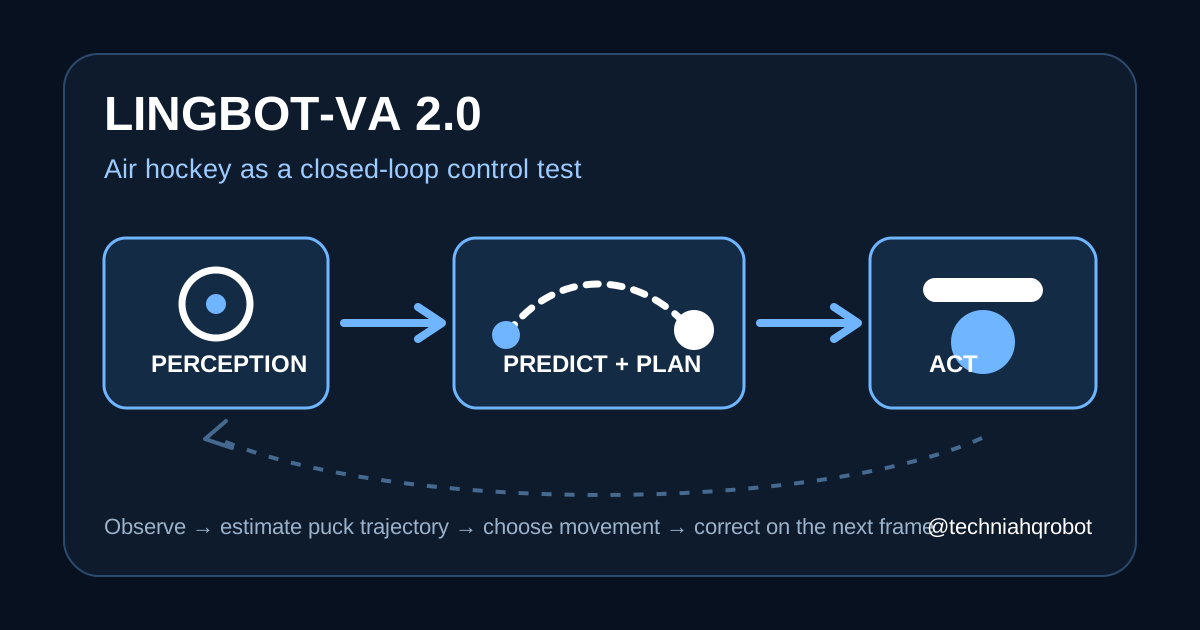
Editorial diagram of a robot mallet predicting a moving air-hockey puck trajectory
Robot foundation models

Why Air Hockey Is a Hard Real-Time Test for LingBot-VA 2.0

The air-hockey clip places LingBot-VA 2.0 in a scene that changes while the robot is acting. A fixed sequence is insufficient because the puck position, speed and rebound path keep changing.

Read article
Editorial list of eight Italian humanoid robot platforms from IIT, Oversonic Robotics and the University of Pisa
Humanoid robotics by country

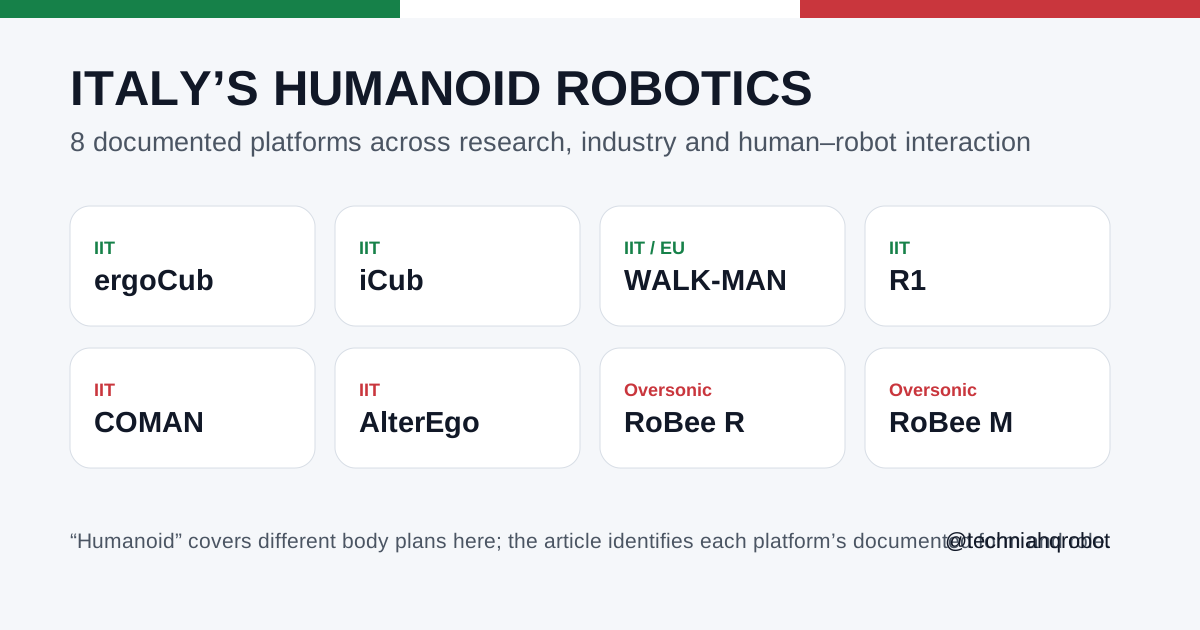
Eight Italian Humanoid Robot Platforms and What Each One Was Built to Test

Italy's humanoid robotics record spans open research platforms, compliant bipeds, wheeled avatars and commercial cognitive robots. The eight machines belong to different generations and should not be compared as if they were one product category.

Read article
Editorial diagram comparing a quadruped robot and a tracked unmanned ground vehicle
Military robotics

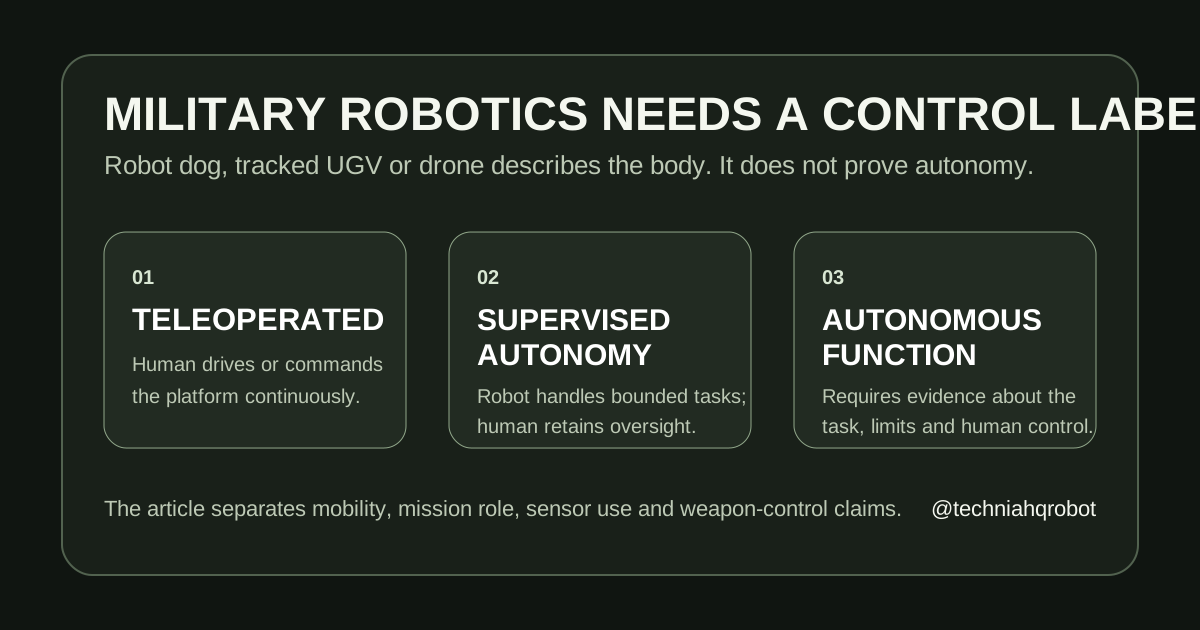
Robot Dogs and Tracked UGVs Are Rewriting Ground Operations Before Humanoids Arrive

The convoy in the TechniaHQRobot post combines quadruped robots, tracked unmanned ground vehicles and other uncrewed platforms. Their immediate advantage is not a human shape. It is the ability to put sensors, cargo or equipment into dangerous terrain without seating a person inside the machine.

Read article
Editorial factory diagram showing a vehicle assembly line being cleared for humanoid robot production
Robot manufacturing

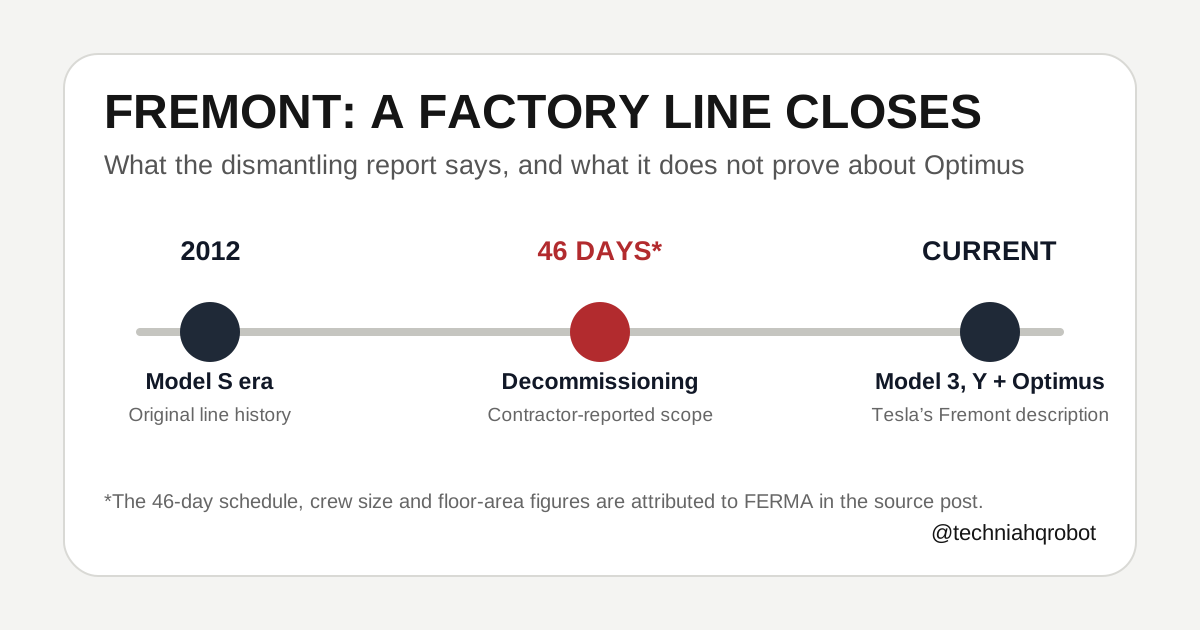
Tesla Cleared the Model S and Model X Line as Fremont Shifts Toward Optimus

A production line does not disappear when the final vehicle leaves it. Robots, conveyors, utilities, guarding, tooling and overhead infrastructure must be isolated, dismantled and removed before a different product can occupy the floor.

Read article
World models and simulation

World Models for Robotics Prediction, Planning and Control

How robotics world models represent future states, support planning and differ from physics simulators, with limits from contact, timing and uncertainty.

Read article
Simulation and transfer

Sim-to-Real Robotics Policies That Survive Physical Tests

How robot policies move from simulation to hardware, with checks for actuator mismatch, sensor timing, calibration and physical trials.

Read article
Simulation and transfer

Robot Training in Simulation Methods, Data and Limits

A practical guide to training robots in simulation with reinforcement learning, imitation learning, motion retargeting and synthetic perception, including the hardware checks needed for transfer.

Read article
Simulation and transfer

Digital Twins for Robotics Geometry, Physics and Operations

How robotics digital twins connect geometry, dynamics, sensors and operational data, with concrete validation checks and limits for simulation and deployment.

Read article
Simulation and transfer

Domain Randomization for Humanoid Robot Transfer

How domain randomization varies robot dynamics, contact, sensing and delay for sim-to-real transfer, with practical failure modes and evaluation limits.

Read article
Simulation and transfer

Physics Simulation for Physical AI Platforms Compared

A task-based comparison of robotics physics simulators, covering Isaac Sim/Lab, MuJoCo, SAPIEN/ManiSkill and Gazebo with fidelity, throughput and sim-to-real limits kept separate.

Read article
NVIDIA Physical AI

Omniverse Robot Training USD, Isaac Sim and Replicator

How Omniverse, Isaac Sim, Isaac Lab and synthetic data tools fit into robot training, with asset, simulation and hardware validation checks.

Read article
European Physical AI

Mistral Robostral Navigate Single-Camera Robot Navigation

Mistral Robostral Navigate is an 8B single-RGB-camera navigation model trained in simulation. This review separates its published R2R-CE results from real-world deployment evidence.

Read article
European Physical AI

Mistral Robostral vs Gemini Robotics Compared Carefully

A current functional comparison of Mistral Robostral Navigate with Gemini Robotics 2 and Gemini Robotics ER 2, separating navigation, action generation, embodied reasoning, access and real-robot evidence.

Read article
European Physical AI

Mistral Robostral vs NVIDIA Cosmos Different Stack Layers

A current comparison of Mistral Robostral Navigate and NVIDIA Cosmos 3, explaining why a single-camera navigation policy and an open omnimodal world/action model occupy different layers of a Physical AI stack.

Read article
European Physical AI

European Robotics Foundation Models Verified Projects

A source-checked map of European robot models and tooling, separating specialized models such as Robostral Navigate from broader foundation-model claims and software ecosystems.

Read article
European Physical AI

French Physical AI Companies Robots, Models and Data

A source-checked guide to French robotics and Physical AI companies, using current product, deployment and model evidence from Mistral AI, Wandercraft and Exotec.

Read article
Gemini Robotics

Gemini Robotics Models Capabilities, Access and Evidence

Current Gemini Robotics model family, roles, access and real-robot evidence, including Gemini Robotics 2, ER 2 and On-Device 2.

Read article
Gemini Robotics

Gemini Robotics-ER 1.6 Capabilities and Access

Gemini Robotics-ER 1.6 specifications, spatial-reasoning capabilities, API history, safety limits and current replacement status.

Read article
Robot foundation model comparison

Gemini Robotics vs NVIDIA GR00T N1.7 Compared

Gemini Robotics and NVIDIA GR00T compared by model access, control interfaces, robot adaptation and the limits of their published evaluations.

Read article
Gemini Robotics

Does Google Have a Humanoid Robot in 2026?

Google DeepMind develops Gemini Robotics software rather than a Google-branded humanoid. Current Gemini Robotics 2 demonstrations include Apptronik Apollo 2 and Franka Duo hardware.

Read article
NVIDIA Physical AI

NVIDIA Physical AI Stack Cosmos, GR00T, Isaac and Thor

A practical map of NVIDIA's Physical AI stack, separating Cosmos world models, Isaac simulation/training, GR00T robot policies, Omniverse infrastructure and Jetson Thor edge compute.

Read article
World Models

NVIDIA Cosmos 3 for Robotics Models, Access and Limits

NVIDIA Cosmos 3 explained for robotics: 16B and 64B open models, multimodal reasoning/world/action generation, published benchmarks, access terms and the real-robot validation still required.

Read article
Robot Foundation Models

NVIDIA GR00T N1.7 Architecture, Robot Support and Access

NVIDIA GR00T N1.7's observation and action pipeline, model access, embodiment adaptation and the limits of the documented robot evaluations.

Read article
Simulation

Isaac Sim and Isaac Lab for Humanoid Robot Training

The roles of Isaac Sim and Isaac Lab in robot training, including Isaac Sim 6.0 migration, simulated sensors, learning environments, policy deployment and hardware validation.

Read article
Robot Compute

Jetson Thor for Humanoid Robots Compute, Power and Limits

Jetson Thor for humanoid robots: current NVIDIA compute, memory and power specifications, plus what those numbers do and do not establish about onboard autonomy.

Read article
Physical AI

Physical AI vs Embodied AI Definitions and Boundaries

A practical distinction between Physical AI and Embodied AI, showing where the terms overlap, where simulation-only research differs from physical deployment, and what evidence each label should include.

Read article
Physical AI

Physical AI Company Categories and Supplier Checks

A guide to Physical AI suppliers across robot hardware, models, simulation, data and components, with evidence to check before selection.

Read article
Physical AI

Physical AI Market, Stocks and Real Use Cases Explained

A conservative guide to Physical AI market claims, public-company exposure and deployed use cases, with forecasts, audited revenue, pilots and enabling technologies kept separate.

Read article
Robot Models

Large Behavior Models for Robotics Meaning and Evidence

A technical definition of the non-standard Large Behavior Model label, with concrete criteria for data breadth, embodiments, action spaces, adaptation and real-robot evaluation.

Read article
Unitree G1 humanoid with bent knees and its hands held together
Humanoid robot comparison

8 Humanoid Robots Compared in 2026: Price, Tasks and Availability

Compare eight humanoid robots using documented deployments, price, payload, runtime, control method, availability and stated technical limits.

Read article
Humanoid Comparisons

Humanoid Robot Speed and Strength Records How to Verify Claims

A source-checked guide to humanoid speed, race times and payload claims, with current examples and rules for keeping incompatible tests separate.

Read article
Humanoid Industry

How to Evaluate Humanoid Robot Companies

A guide to assessing humanoid robot suppliers through product specifications, customer sites, deliveries and task-level operating data.

Read article
Humanoid Comparisons

Tesla Optimus vs Figure Factory Robots Compared

Tesla Optimus and Figure compared by hardware generation, autonomy disclosures, partner programs and evidence of factory operation.

Read article
Humanoid Comparisons

Tesla Optimus vs Unitree G1 Access, Research and Use

Compare the public purchase routes, developer access and configuration limits of Unitree G1 and Tesla Optimus.

Read article
Humanoid Comparisons

Unitree G1 vs Atlas: developer access and payload definitions

Compare G1 standard, G1 EDU and the 2026 Atlas using published specifications, with the configuration and payload differences that limit a fair comparison.

Read article
Humanoid Comparisons

1X NEO vs Tesla Optimus Home and Factory Strategies

A source-checked comparison of 1X NEO and Tesla Optimus covering current public access, operator involvement, disclosed hardware, intended environments and the evidence limits around autonomy.

Read article
Humanoid Comparisons

Figure vs Agility Digit Factory and Warehouse Evidence

A task-level comparison of Figure and Agility Digit using current factory and warehouse evidence, with separate treatment of robot generations, deployment metrics and missing intervention data.

Read article
Humanoid Comparisons

AgiBot vs Unitree Humanoid Robots: Products, Prices and Public Evidence

A source-checked comparison of AgiBot and Unitree using current product pages, published store prices, developer access and company-reported production evidence.

Read article
Home Robotics

Home Robots for Cleaning, Laundry, Dishes and Cooking

A task-by-task guide to home robots for cleaning, laundry, dishes, cooking and object retrieval, separating mature single-purpose products from bounded humanoid demonstrations.

Read article
Home Robotics

Home Robots for Care, Availability and Unsupervised Use

Evidence for home robots working with limited supervision, including current autonomy claims, remote-assistance paths, safety limits and missing reliability data.

Read article
Robot Autonomy

Humanoid Robot Teleoperation and Control Systems Explained

A technical guide to humanoid teleoperation, shared autonomy and safety control, covering operator interfaces, retargeting, latency, intervention reporting and communication-loss behavior.

Read article
Robot Autonomy

How to Assess Teleoperation in Tesla Optimus Videos

How to distinguish teleoperation, scripted motion and autonomous control in individual Tesla Optimus demonstrations using disclosed evidence.

Read article
Robot Autonomy

1X NEO vs Figure 03 Autonomy What the Evidence Actually Shows

Evidence-based comparison of 1X NEO and Figure 03 autonomy, including Expert Mode, Helix 02, Helix 2.5 zero-shot home generalization, BMW deployment evidence, interventions and missing reliability metrics.

Read article
Robot Verification

How to Detect Misleading Humanoid Robot Demonstrations

A practical evidence checklist for humanoid robot videos: editing, playback speed, teleoperation, resets, task setup, trial count, recovery and what the footage actually proves.

Read article
Robot Learning

Did the Robot Learn the Task or Replay a Program?

How to distinguish fixed trajectories, state machines, teleoperation playback and learned robot policies using observable tests and published technical evidence.

Read article
Humanoid Prices

Tesla Optimus Price, Release Date and Buying Status

Tesla has not published a complete retail price, public preorder channel or general delivery date for Optimus. This page separates company targets from current buying status and official sales information.

Read article
Humanoid Prices

Unitree Humanoid Robot Prices, Models and Buying Costs

Unitree G1 and H1 buying considerations, including configuration, developer access, shipping, tax and the difference between a base price and a delivered quotation.

Read article
Humanoid Prices

1X NEO and Figure Robot Prices and Availability

Current 1X NEO pricing and availability compared with Figure access: $20,000 Early Access ownership, $499/month subscription, $200 deposit, warranty/support terms and Figure's lack of a public retail price.

Read article
Humanoid Prices

Humanoid Robots Under $20,000 and Home Robot Costs

A current price guide to humanoid hardware under $20,000, separating base robot price from shipping, duties, developer access, hands, compute and home-use claims.

Read article
Humanoid robot hands

How Many Degrees of Freedom Does a Humanoid Hand Need?

Mechanical, active, passive and coupled degrees of freedom in robot hands, and why a joint count alone does not measure useful dexterity.

Read article
Humanoid robot hands

Robot Hands With Tactile Sensors What They Can Measure

A practical comparison of tactile robot hands, covering pressure, shear, force transparency, calibration, sampling, slip detection and what current 1X, Unitree and Figure hardware actually publishes.

Read article
Humanoid robot hands

Tesla Optimus Hand What Tesla Has Actually Disclosed

Tesla Optimus hand demonstrations and the specification gaps that remain when comparing generations, control modes and manipulation tasks.

Read article
Humanoid robot hands

1X NEO Hand 25 DoF, Tendon Drive and Tactile Sensing

1X documents NEO as a 25-DoF tendon-driven hand and wrist system with force-controlled backdrivable joints, tactile sensing and published force and durability measurements. This guide separates those company measurements from independent evidence that is still missing.

Read article
Humanoid robot hands

Figure Robot Hand Palm Cameras, Tactile Sensing and Helix

Figure's hand cameras and tactile sensing, their role in manipulation and the limits of publicly reported specifications and demonstrations.

Read article
Humanoid robot hands

Unitree Dexterous Hands Compared Dex3-1 and G1 Options

How Unitree Dex3-1 uses three fingers, force control and pressure sensing, with configuration, SDK and humanoid-package compatibility checks.

Read article
Humanoid robot hands

How to Evaluate Delicate and Dynamic Robot-Hand Tasks

An evidence guide to delicate and dynamic robot-hand tasks such as peeling, shoelace tying and catching, with contact control, deformable-object reasoning, timing and repeatability kept separate.

Read article
Humanoid robots in factories

BMW Humanoid Robots Verified Pilots, Tasks and Results

BMW humanoid robot projects at Spartanburg, including Figure 02 production work and the Figure 03 sequencing trial, with published results and missing operating data.

Read article
Humanoid robots in factories

Amazon Humanoid Robot Projects: Digit Testing and Fauna Robotics

Amazon tested Agility Robotics Digit for tote handling and now owns Fauna Robotics. This source-checked timeline separates confirmed humanoid work from Amazon’s other warehouse robots and lists data that remain unpublished.

Read article
Humanoid robots in factories

Humanoid Robots in Warehouses Tasks, Pilots and Limits

A warehouse-focused review of humanoid robots, separating commercial tote-handling deployments from tests, pilots and broader order-fulfillment claims.

Read article
Humanoid robots in factories

Humanoid Robots on Automotive Production Lines

A task-level review of humanoid robots in automotive plants, separating measured factory operation from pilots, commercial agreements and announced deployments.

Read article
Humanoid robots in factories

Humanoid Robot Picking, Placement and Inspection

A task-level guide to humanoid picking, placement and inspection, separating manipulation evidence from inspection accuracy and showing the metrics needed for each workflow.

Read article
Humanoid robots in factories

Humanoid Robot Cycle Time and Reliability Explained

How to measure humanoid cycle time, intervention rate and recovery across repeated work, and why the fastest clip does not establish reliability.

Read article
Humanoid robots in factories

Humanoid Robot Operating Cost A Transparent Model

A transparent humanoid operating-cost model covering productive uptime, financing, integration, support, maintenance, remote assistance, charging, downtime and accepted task output.

Read article
Humanoid robotics by country

How to Compare Humanoid Robotics by Country

A framework for comparing humanoid robotics by country, with selected regional examples and separate rules for companies, research institutes, components and historical programs.

Read article
Humanoid robotics by country

Chinese Humanoid Robot Companies: Selected Manufacturers and Evidence

Selected Chinese humanoid manufacturers and how to distinguish product pages, prices, orders, production claims and deployment evidence.

Read article
Humanoid robotics by country

European Physical AI Companies and Startups Robots, Data and Control

A source-checked directory of European Physical AI companies and younger startups, separating headquarters, founding history, robot hardware, sensing, software and public evidence.

Read article
Humanoid robotics by country

Chinese Humanoid Robot Prices What the Listings Include

Current public prices and sales channels for Chinese humanoid robots, with configuration, export-cost and quote-only caveats checked against official manufacturer pages.

Read article
Humanoid robotics by country

Japan and Korea Humanoid Robot Programs Active and Historic

A dated guide to humanoid robotics programs in Japan and South Korea, separating historical platforms, university research, commercial companies and currently available systems.

Read article
Humanoid robotics by country

European Humanoid Robot Map Companies and Laboratories

A source-checked map of selected European humanoid companies and laboratories, with country, organization type, robot program, current status and explicit limits where the directory is incomplete.

Read article
Humanoid robotics by country

Who Leads Humanoid Robotics? A Measurable Framework

Compare humanoid robotics ecosystems by research, components, robot delivery and deployment evidence while keeping geography and company status distinct.

Read article
Humanoid robotics by country

Humanoid Robot Manufacturing Capacity Claims vs Output

A source-checked comparison of humanoid manufacturing capacity, actual production, shipments and deliveries, with company targets kept separate from observed output.

Read article
Humanoid robotics by country

Humanoid Robot Companies in Italy and France

A dated directory of humanoid robotics organizations in Italy and France, separating research institutes, commercial robot companies, complete platforms and enabling components.

Read article
Robot learning from humans

How Robots Learn From Humans Data, Methods and Limits

How teleoperation, human video, motion capture and corrective demonstrations become robot training data, with the transfer limits and evaluation fields each method needs.

Read article
Robot learning from humans

Robot Learning From Video What Images Cannot Provide

How human and robot video support policy learning, what missing action and contact data must be supplied, and how to test transfer on a physical robot.

Read article
Robot learning from humans

Imitation Learning in Robotics Methods and Failure Modes

A technical guide to imitation learning in robotics, comparing behavior cloning, DAgger, diffusion policies and sequence models through distribution shift, action representation and real-robot evaluation.

Read article
Robot learning from humans

Learning From Demonstration Teleoperation to Robot Policy

A practical guide to robot learning from demonstration, focused on kinesthetic teaching, leader-follower control, VR, motion capture, synchronization, retargeting and corrective data collection.

Read article
Robot learning from humans

Humanoid Robot Training and Teleoperation Data

How robot teleoperation produces training data, including synchronized observations, action labels, calibration and operator interventions.

Read article
Robot learning from humans

Human Motion Capture for Robotics Retargeting Explained

How motion capture is retargeted to robot joints, contacts and dynamics, with checks for body differences, balance and task preservation.

Read article
Robot learning from humans

Robot Data Collection Jobs and Companies Explained

A practical guide to robot data-collection work, including teleoperation, scene reset, motion capture, labeling, safety supervision and dataset quality, with employment terms kept separate from model-engineering roles.

Read article
Robot learning from humans

Robot Learning Without Action Labels What Is Possible

How observation-only video supports representations and latent actions, and why robot control still needs action grounding and closed-loop evaluation.

Read article
Robot learning from humans

Synthetic vs Real Robot Data Cost, Fidelity and Transfer

A practical comparison of synthetic and real robot data, covering cost, labels, physics fidelity, teleoperation, autonomous rollouts, calibration and sim-to-real validation.

Read article
Open-source Physical AI

Open-Source Physical AI: Artifacts, Licenses and Reproducibility

A practical map of open-source Physical AI artifacts, separating frameworks, model weights, datasets, simulators, robot interfaces and licenses so developers can see what is actually reusable and reproducible.

Read article
Open-source Physical AI

Open-Source Humanoid Robots: Reproducibility and Build Planning

An audit of released humanoid CAD, electronics, firmware, software and licenses, with build-planning questions and links to project instructions. It is not a complete assembly manual.

Read article
Open-source Physical AI

Hugging Face LeRobot Framework, Datasets and Policies

LeRobot's robot interfaces, datasets and training policies, with calibration requirements, licensing checks and links to the project documentation.

Read article
Open-source Physical AI

LeRobot With Unitree G1 Support, Setup and Safety

A current integration guide to LeRobot and Unitree G1 covering supported 23-DoF and 29-DoF variants, teleoperation, simulation, whole-body controllers, networking and safety limits.

Read article
Open-source Physical AI

Open VLA Models: Code, Weights and Adaptation Limits

A current comparison of open vision-language-action models, separating code, checkpoints, licenses, action representations, supported robots, compute requirements and real-robot evidence.

Read article
Open-source Physical AI

Robot Learning Workflow: Collect, Train and Evaluate

A workflow overview for a low-force research arm covering calibration, demonstrations, data splits, baseline training and physical evaluation, with links to hardware-specific instructions.

Read article
Open-source Physical AI

Humanoid Robot GitHub Repositories and Open Datasets

A practical audit of open humanoid robotics repositories and datasets covering maintenance, supported hardware, licenses, action labels, reproducibility and real-robot evidence.

Read article
Open-source Physical AI

Low-Cost Robot Arms and Training a Policy at Home

A practical guide to low-cost tabletop robot arms for home policy training, covering hardware scope, LeRobot support, cameras, calibration, teleoperation, spare parts and supervised safety.

Read article
Open-source Physical AI

Open-Source Robot Datasets Tasks, Formats and Licenses

A practical comparison of open robot datasets, covering embodiment mix, observations, action semantics, timestamps, task diversity, licenses and the checks needed before combining datasets for training.

Read article
Open-source Physical AI

LeRobot Datasets Explained Episodes, Actions and Metadata

LeRobotDataset v3 explained: Parquet state and action data, MP4 video, episode metadata, streaming, version migration and the compatibility checks needed before combining robot datasets.

Read article
Jobs and robot economics

Will Humanoid Robots Replace Jobs? Task-Level Evidence

Assess humanoid automation at task level, including supervision, maintenance, operating costs and the difference between a pilot and sustained labor substitution.

Read article
Jobs and robot economics

Humanoid Robots, Unemployment and the Tasks They Can Do

A task-level analysis of humanoid robots and employment, separating demonstrated robot tasks from occupation-level displacement, supervision work and labor-market forecasts.

Read article
Jobs and robot economics

Robots for Labor Shortages and Caregiver Gaps

Evaluate whether robots address a specific labor shortage, with separate considerations for supervision, workflow, consent and physical contact in caregiving.

Read article
Jobs and robot economics

Factory Workers vs Humanoid Robots A Fair Comparison

A task-level framework for comparing factory work with humanoid automation using cycle time, quality, intervention, uptime, safety, integration cost and worker impact rather than broad replacement claims.

Read article
Jobs and robot economics

Physical AI Jobs and Robotics Careers Through 2030

A practical guide to Physical AI and robotics careers through 2030, separating engineering, simulation, data operations, safety, integration and field-service roles from broad labor-market forecasts.

Read article
Jobs and robot economics

Humanoid Robot Cost vs Worker: A Comparison Framework

A task-level cost comparison framework covering productive uptime, integration, support, interventions and accepted output. The page explains model inputs and does not provide an interactive calculator.

Read article
Jobs and robot economics

Humanoid Robots Working Night Shifts Costs and Risks

A practical guide to humanoid night-shift operation, covering supervision, lighting, charging, blocked-route recovery, cybersecurity, emergency response and productive uptime.

Read article
Jobs and robot economics

The Future of Manual Labor With Physical AI

A task-level review of how robotics and AI affect manual work, using labor reports and real deployment evidence while keeping forecasts separate from measured outcomes.

Read article
Jobs and robot economics

Robot Tax Explained Proposals, Problems and Tradeoffs

A neutral guide to robot-tax proposals, covering what could be taxed, arguments for and against, administrative problems and alternative labor or capital-tax policies.

Read article
Humanoid robot safety

Are Humanoid Robots Safe? A Layer-by-Layer Assessment

Humanoid robot safety depends on the task, workspace and people nearby. This guide covers ISO 10218, risk assessment, independent safety controls, cybersecurity and limits for home and public use.

Read article
Humanoid robot safety

Robot Emergency Stops: Functions, Limits and Evidence

Emergency stops for robots: stop paths, reset behavior and system hazards to assess alongside the applicable machinery safety requirements.

Read article
Humanoid robot safety

Humanoid Fall Recovery and Balance Recovery Explained

Distinguish balance correction, impact protection and getting up after a fall, with checks for damage, nearby people and assisted recovery.

Read article
Humanoid robot safety

Human–Robot Collision Hazards and Incident Evidence

A safety-focused guide to human-robot collisions, separating impact, pinch, crush and fall hazards from documented injury evidence and keeping industrial-robot standards within their stated scope.

Read article
Humanoid robot safety

Humanoid Robot Safety Standards and Certification

How machinery, robot and functional safety requirements apply to a humanoid system, and what evidence is needed for a defined application.

Read article
Humanoid robot safety

Robot Cybersecurity Can a Humanoid Be Hacked?

A practical robot-cybersecurity guide covering remote access, fleet control, signed updates, authentication, logging, safe fallback and privacy risks for connected industrial and humanoid robots.

Read article
Humanoid robot safety

Safe Home Robots Children, Pets, Privacy and Stairs

A practical home-robot safety guide covering children, pets, stairs, tools, charging, privacy, remote assistance and the current ISO 13482 service-robot standard transition.

Read article
Humanoid robot safety

Humanoid Robot Injuries What the Evidence Shows

An evidence guide for humanoid robot injuries and near misses, separating verified incidents from other robot categories and showing what an incident record needs before causal claims are made.

Read article
An operator teaching a Franka Emika arm by hand
Physical AI technical guide

Vision-Language-Action Models

A technical guide to VLA models, action tokenization, diffusion control, robot data, real-world evidence, latency, generalization and failure modes.

Read article
A close view of a Baxter robot gripper
Physical AI technical guide

World Action Models

A rigorous guide to world action models, action-conditioned prediction, counterfactual rollouts, visual planning, uncertainty and real-robot control limits.

Read article
A humanoid research robot at Tsukuba
Physical AI technical guide

Whole-Body Loco-Manipulation

How humanoids coordinate feet, center of mass, arms and contact forces during real loco-manipulation, with systems, evidence, failures and safety limits.

Read article
A close view of NASA Robonaut's dexterous hand
Physical AI technical guide

Tactile-Language-Action Models

How robot policies fuse language, vision and touch for slip recovery, insertion and contact-rich manipulation, with verified models, sensor limits and evidence.

Read article
A PAL Robotics TIAGo robot at RoboCup 2016
Physical AI technical guide

Robot Foundation Models

A criteria-based guide to robot foundation models covering pre-training scale, task and embodiment diversity, adaptation, open weights, evidence and limits.

Read article
Human demonstration collection with a UMI handheld gripper
Physical AI technical guide

Egocentric Robotics Data

A technical guide to human and robot first-person datasets, embodiment gaps, missing action labels, gaze, depth, privacy and transfer into robot policies.

Read article
Baxter and NAO robots at Innorobo 2015
Physical AI technical guide

Multiview Embodied Reasoning

How robots align multiple camera views for 3D reasoning, occlusion handling, object permanence and action planning, with models, benchmarks and failures.

Read article
NVIDIA's Isaac GR00T data generation workflow
Physical AI technical guide

Synthetic Robotics Data

A technical comparison of robot simulators, domain randomization, synthetic trajectories, tactile and depth data, sim fidelity and the real data still required.

Read article
A Franka Emika arm viewed from the front
Physical AI technical guide

Generalist Robot Policies

A methodology for evaluating generalist robot policies across tasks, objects, environments, embodiments, action spaces, adaptation and real-world recovery.

Read article
A mobile research robot with a laser scanner, camera and gripper
Physical AI technical guide

Real2Sim2Real

A complete Real2Sim2Real pipeline covering scene capture, system identification, NeRF and Gaussian splatting, simulation training, transfer and validation.

Read article
Different robot arms, grippers and humanoids connected through a shared task representation and embodiment-specific action heads
Physical AI technical guide

Cross-Embodiment Learning

How robot policies transfer across arms, grippers, humanoids and mobile manipulators using normalized actions, shared latent spaces, adapters and retargeting.

Read article
An ANYmal quadruped at an industrial site
Physical AI technical guide

Safety Architectures for Physical AI

A layered safety architecture for Physical AI covering mechanics, functional safety, runtime monitoring, cybersecurity, standards, fallbacks and evidence.

Read article
Humanoid robot comparison

Tesla Optimus vs Figure 03 vs Unitree G1 vs 1X NEO

A source-checked comparison of Optimus, Figure 03, Unitree G1 and 1X NEO covering hardware, autonomy, pricing, production and real deployments today.

Read article
Robot autonomy guide

Is This Robot Autonomous or Teleoperated?

A practical guide for classifying robot videos using visible evidence, autonomy categories, teleoperation signals and a reusable scoring grid for current demos.

Read article
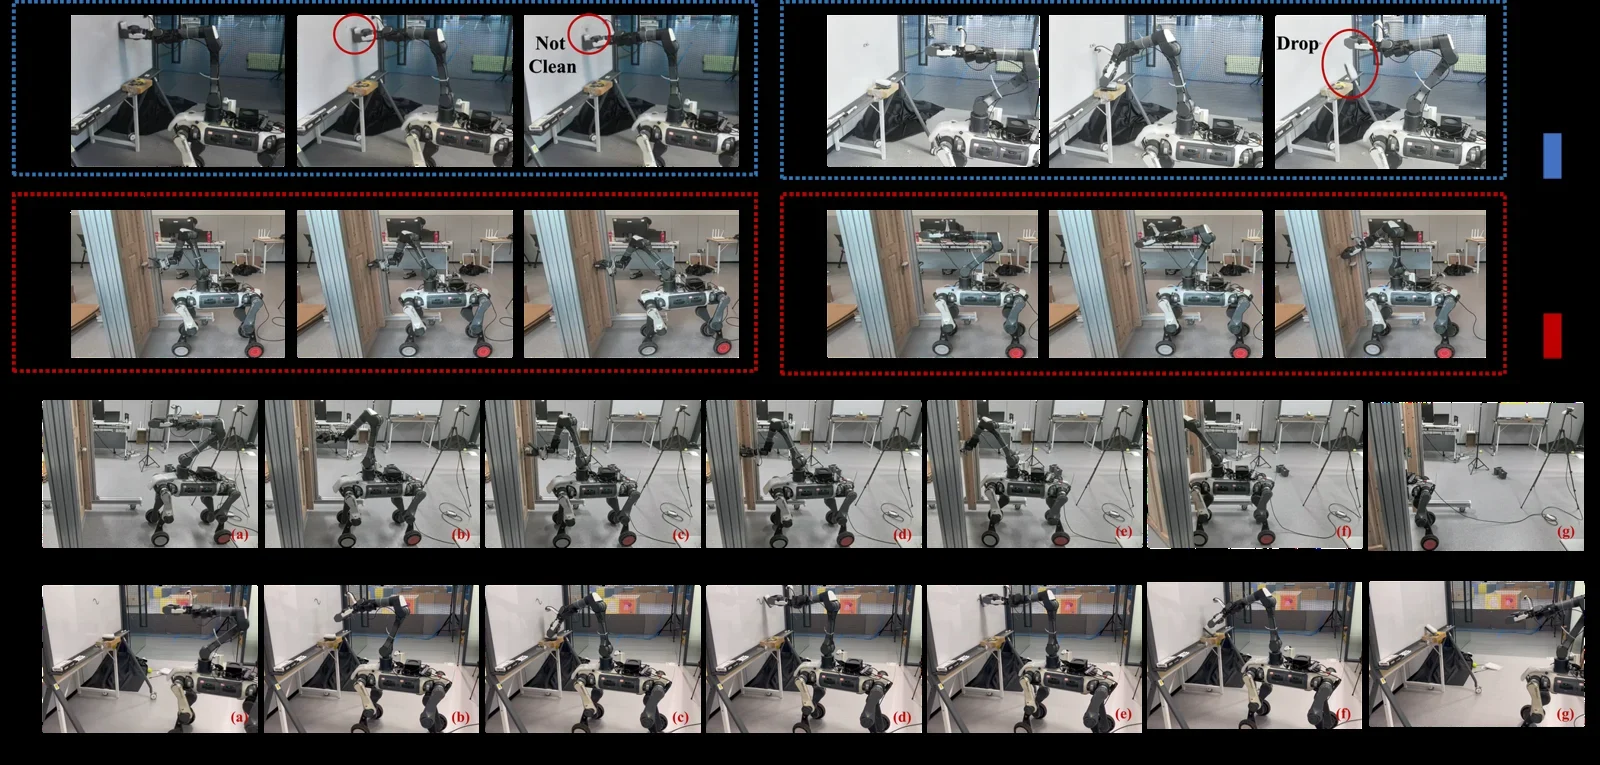
Humanoid robot hands

16 Humanoid Robot Hands Compared

Sixteen humanoid robot hands compared by fingers, degrees of freedom, actuation, tactile sensing, force control, demonstrated tasks and availability in 2026.

Read article
Industry map

11 US-Based Humanoid Robot Companies Tracked in 2026

A methodology-based list of 11 active US-based complete humanoid platforms, with product status, operating base, ownership and current public evidence. Acquired, paused and incomplete programs are listed separately.

Read article
Industry analysis

China vs USA Humanoid Robot Production in 2026

A documented comparison of Chinese and US humanoid production, shipments, factory capacity, supply chains, orders, pilots and government support.

Read article
Home robotics

What Can a Home Robot Really Do in 2026?

A task-by-task audit of home robots in 2026, separating reliable products, supervised work, controlled demonstrations, teleoperation and experiments today.

Read article
Physical AI models

Physical AI Model Map: Roles, Access and Control

A structured map of Physical AI models covering VLA policies, embodied reasoning, world models, manipulation, locomotion, tactile learning and simulation.

Read article
Industrial deployments

Humanoid Factory Deployments Real, Pilot or Announced?

A verified database of humanoid factory and warehouse projects, separating commercial deployments, pilots, internal tests, demos and partnerships.

Read article
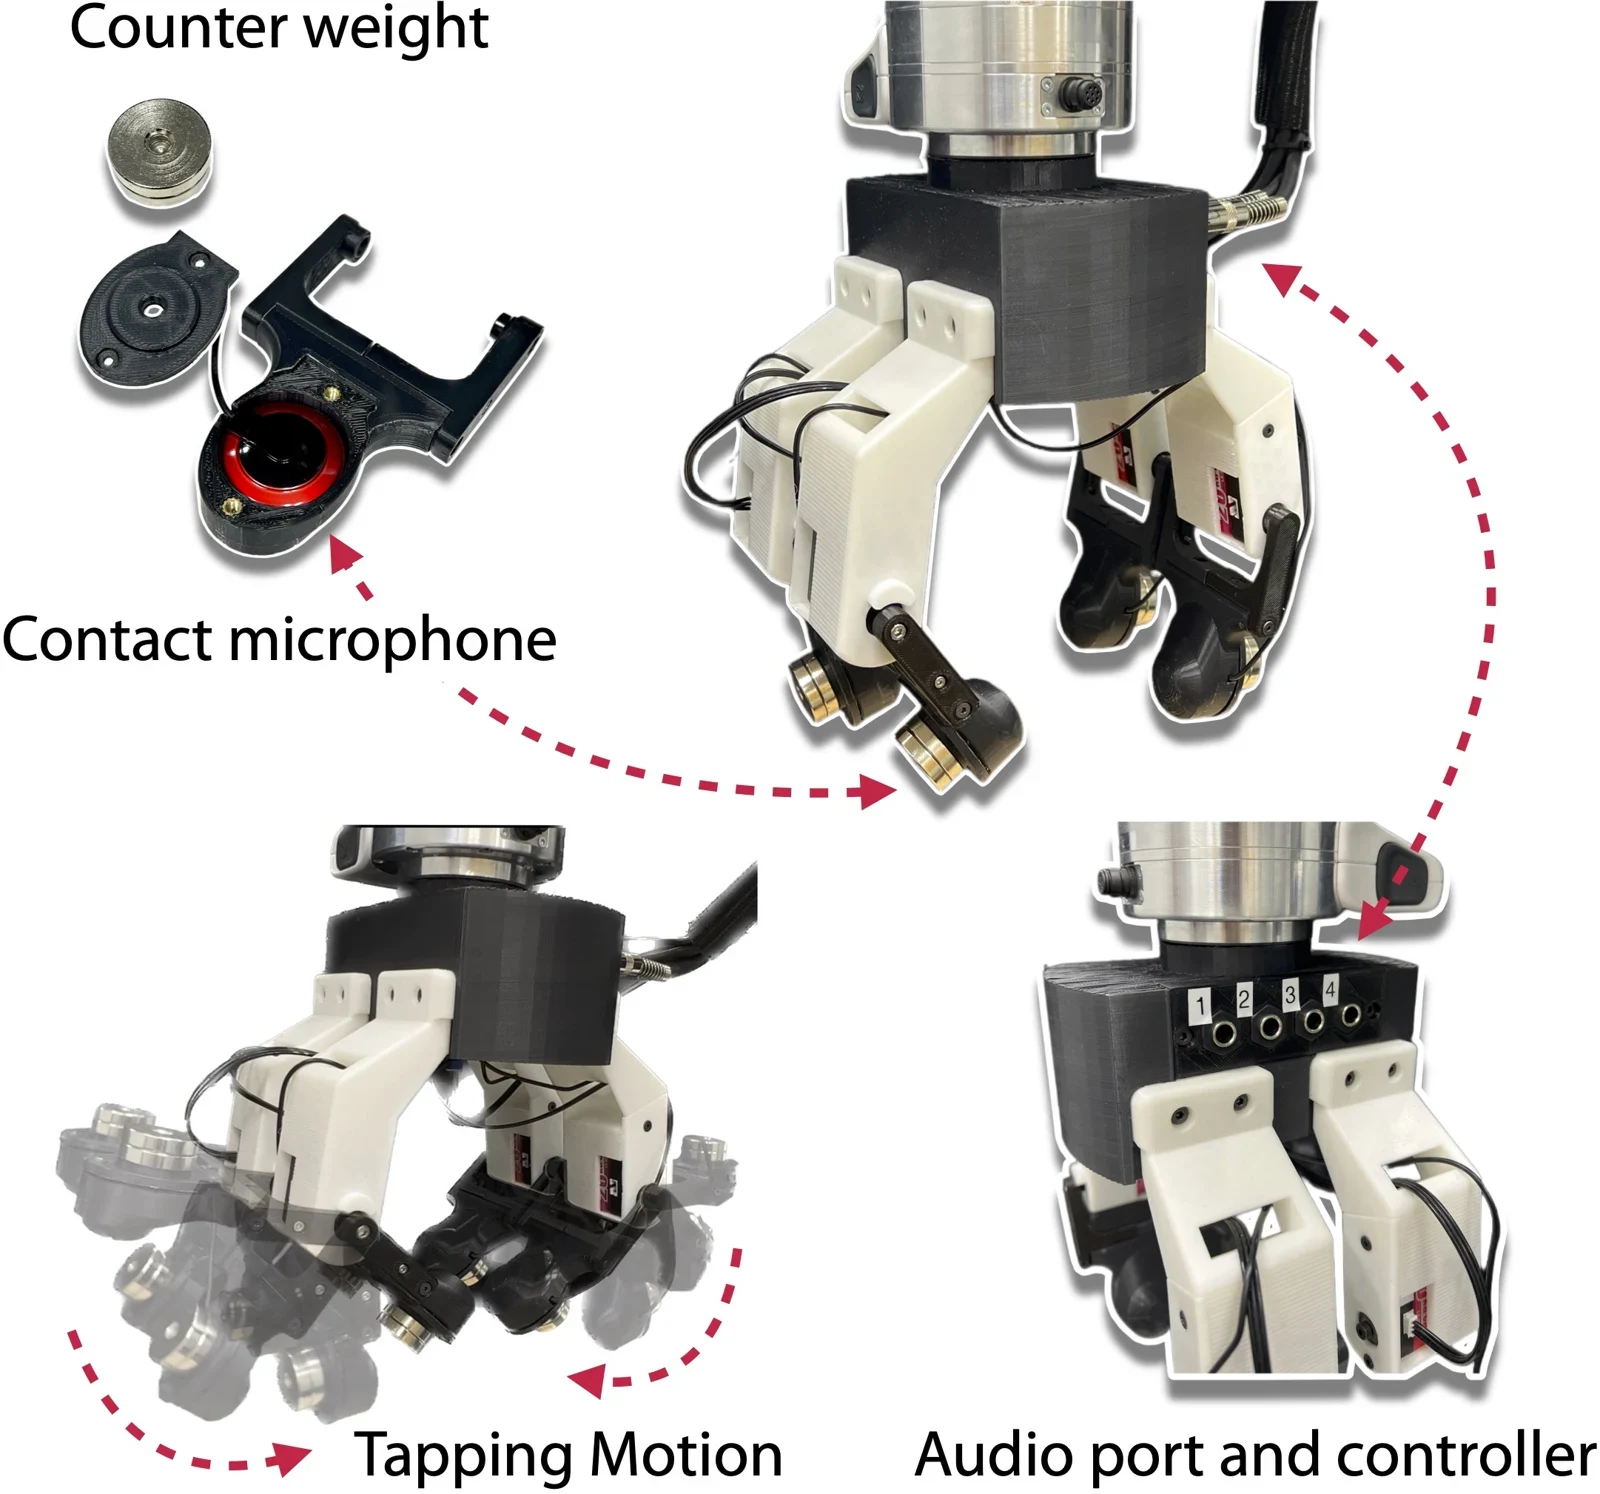
Buying guide

The Cheapest Humanoid Robots Available Today

Verified humanoid robot prices from official stores, with categories, shipping status, included hardware, deposits, subscriptions and hidden costs.

Read article
Humanoid robot buyers guide

20 Humanoid Robots You Can Actually Buy in 2026

A source-checked 2026 buyers guide to 20 humanoid robots offered through official stores, deposits or manufacturer quotations, with current purchase status, hardware and practical limits.

Read article
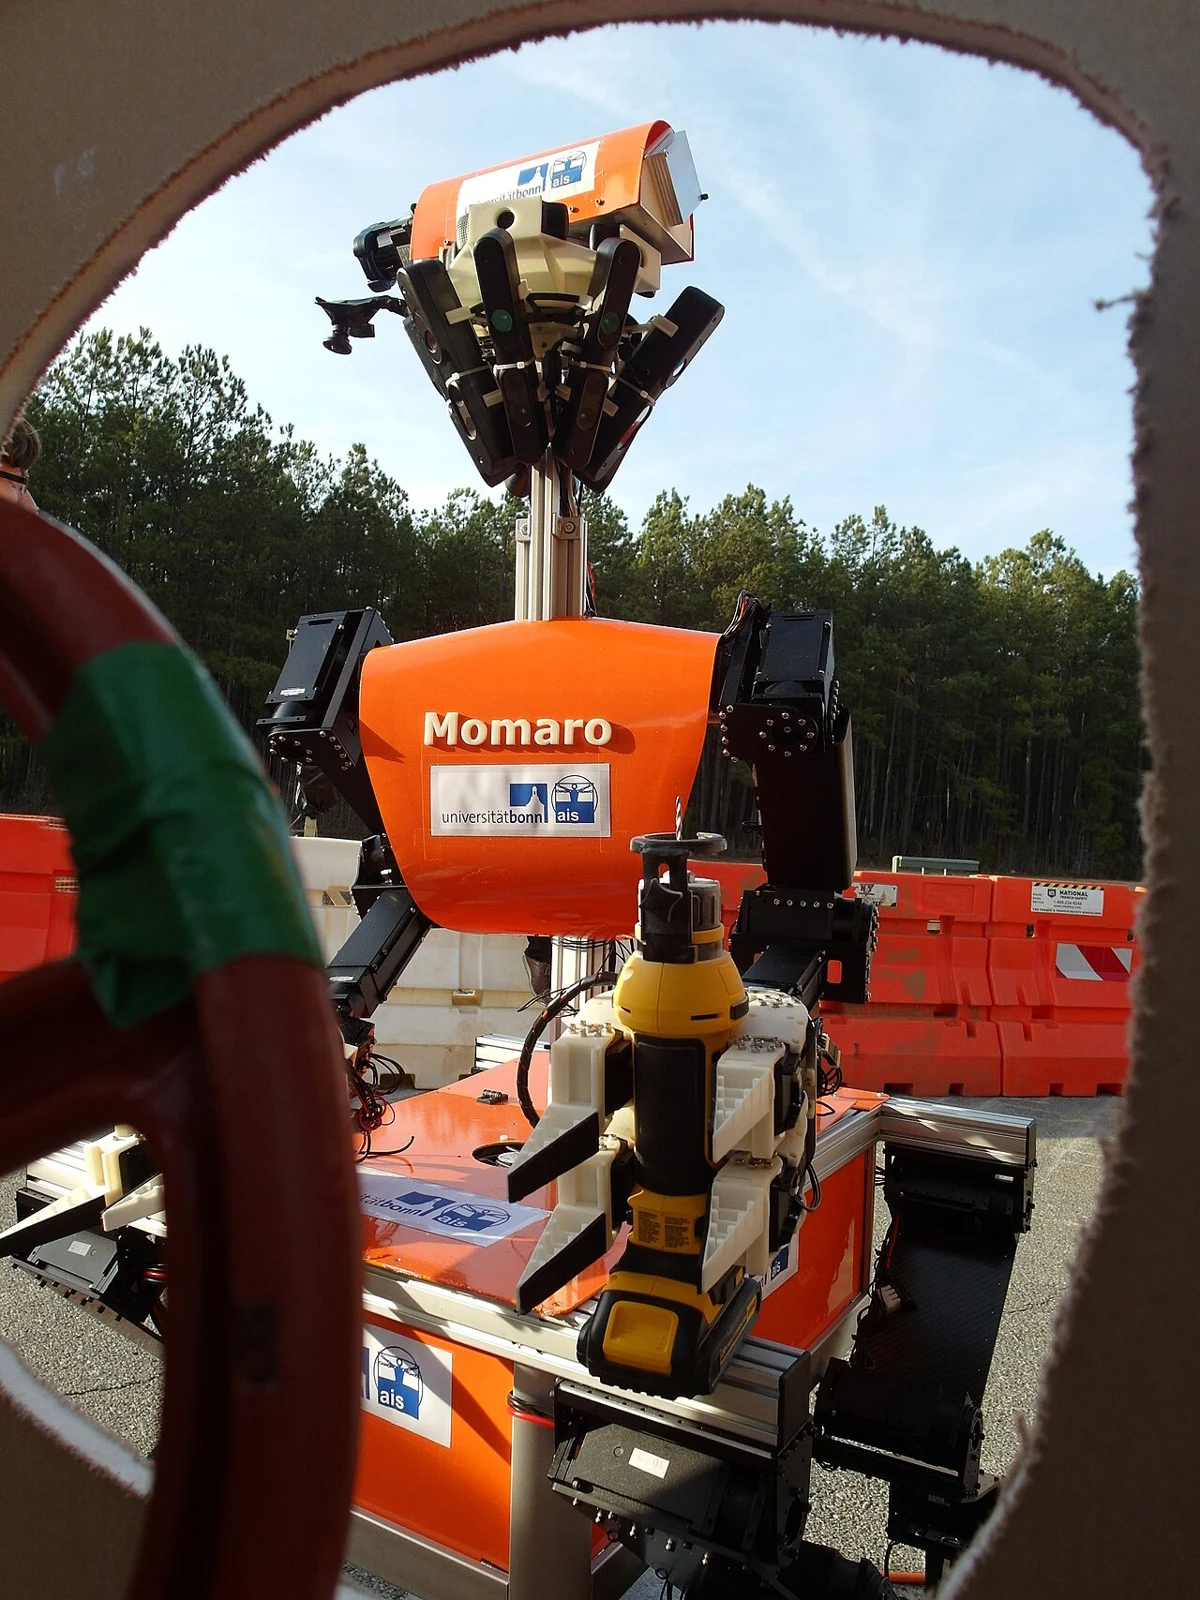
Editorial graphic showing synchronized Boston Dynamics Atlas robots performing Norway’s Viking Row
Humanoid robot demonstrations

Atlas Robots Recreate Norway’s Viking Row at Boston Dynamics HQ

Boston Dynamics Atlas robots recreate Norway’s Viking Row, showing synchronized humanoid motion while leaving the exact control method unconfirmed.

Read article
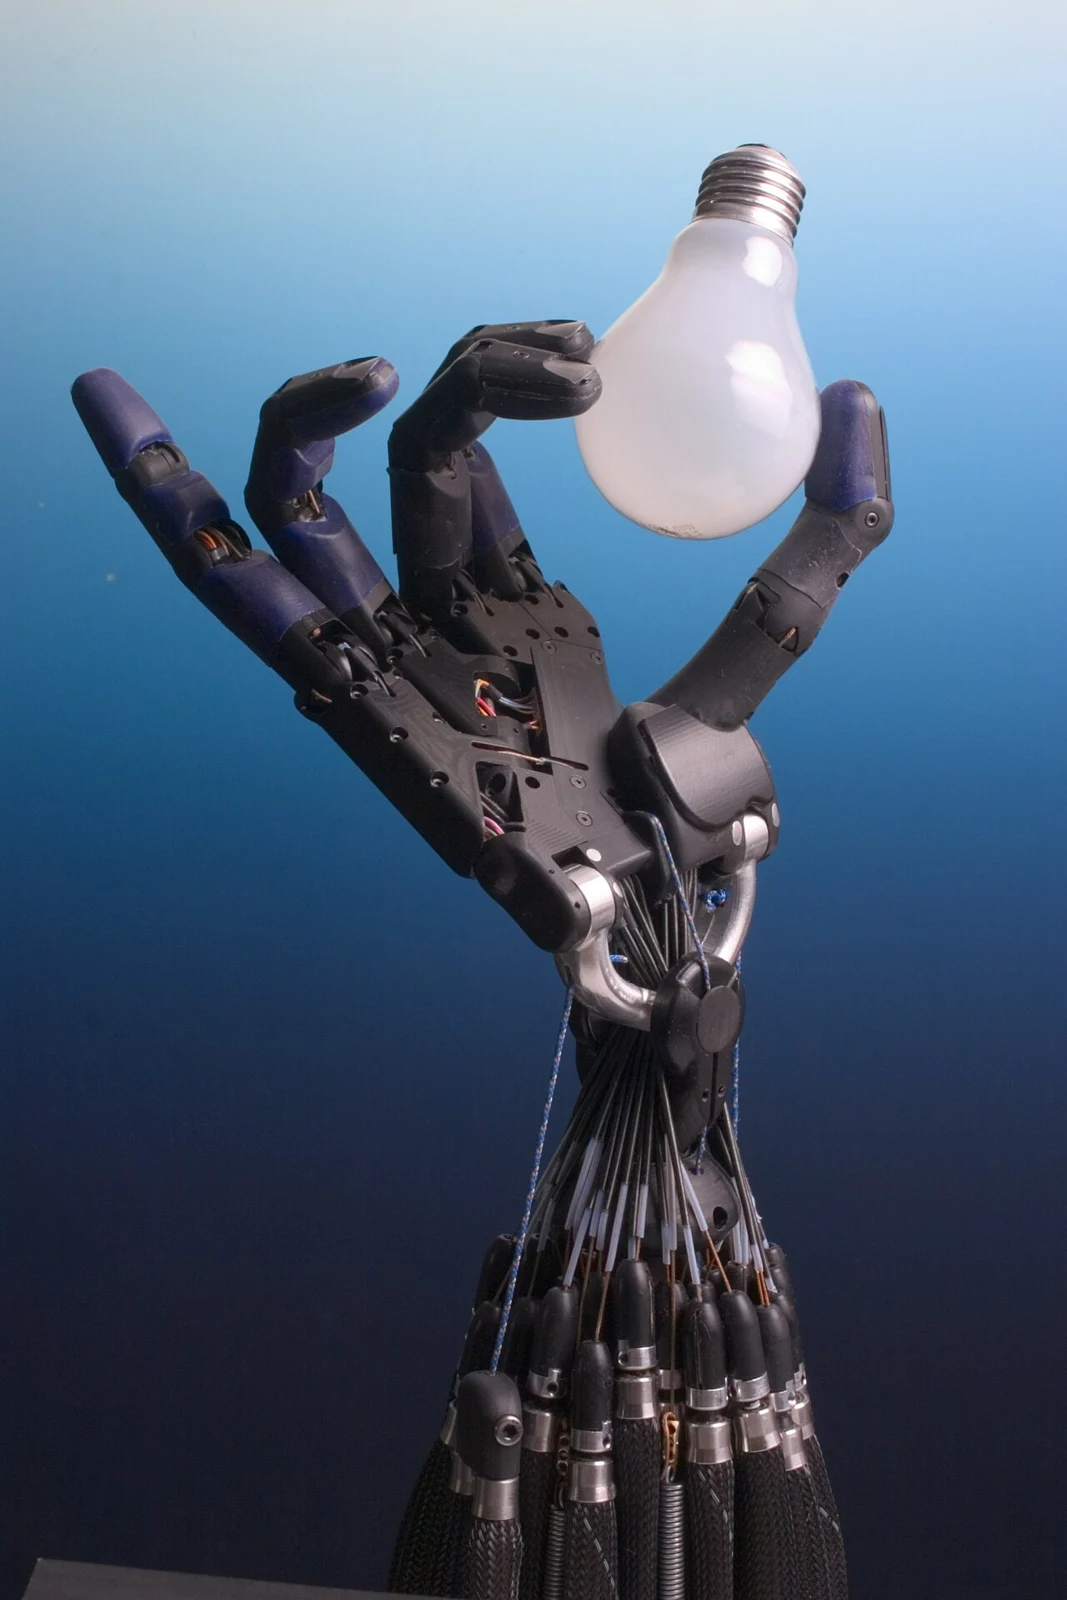
Editorial diagram showing LingBot-VA 2.0 predicting future video states and robot action chunks
Robot foundation models

LingBot-VA 2.0 Architecture, Benchmarks and Control Limits

LingBot-VA 2.0 was built as an embodied-native video-action model. Robbyant reports 93.6% average success on RoboTwin 2.0, a 150 Hz project-page demonstration and real-robot adaptation from about 20 demonstrations per task.

Read article
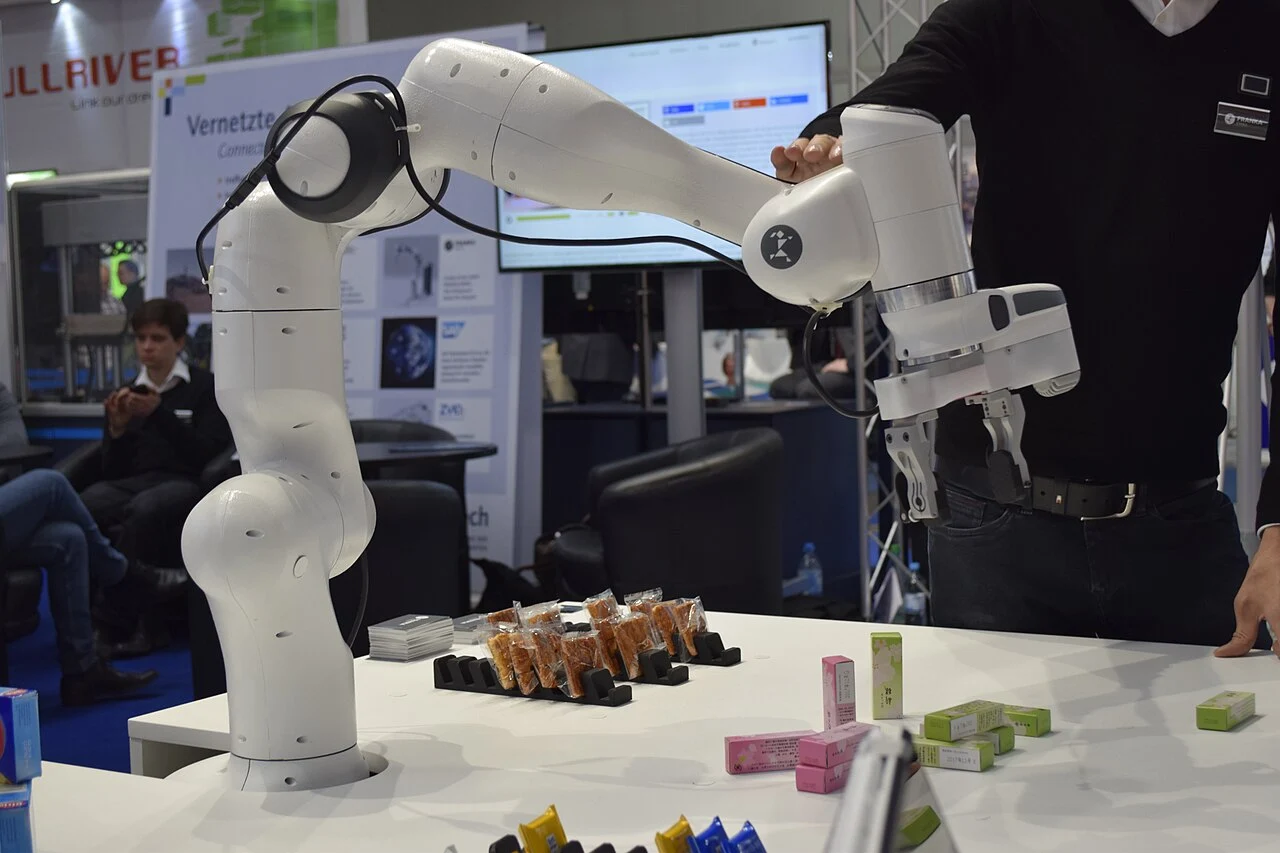
Editorial graphic showing a human operator controlling a Stardust Intelligence humanoid robot
Robot teleoperation

How Stardust Intelligence Controls a Humanoid Robot in Real Time

The demonstration shows a human operator supplying motion to a Stardust Intelligence robot rather than the machine choosing the task independently. Astribot’s official S1 page confirms a research platform with seven degrees of freedom per arm, a stated 5 kg horizontal-reach payload per arm and a VR teleoperation data-collection workflow. The clip itself does not publish end-to-end latency, packet-loss behavior or autonomous task success.

Read article
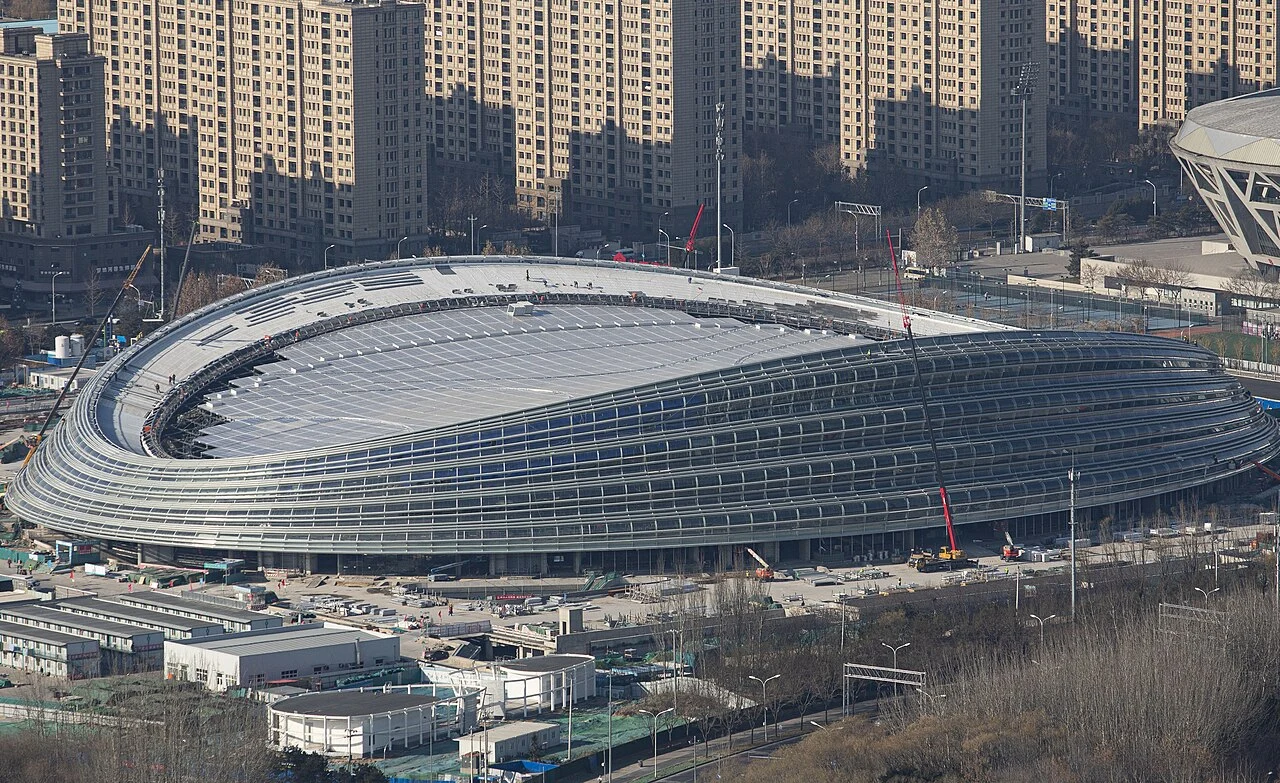
TechniaHQRobot editorial graphic for How 1X NEO’s Hands Sense Slip, Force and Contact
Dexterous robot hands

How 1X NEO’s Hands Sense Slip, Force and Contact

1X describes NEO’s latest hand as a 25-degree-of-freedom tendon system with force-controlled, backdrivable joints and tactile sensing for normal force, contact location and shear. The published specifications explain how the hand can detect slip and adapt its grip, but the strength, accuracy, ingress-protection and lifetime figures remain manufacturer-reported until comparable independent tests are available.

Read article
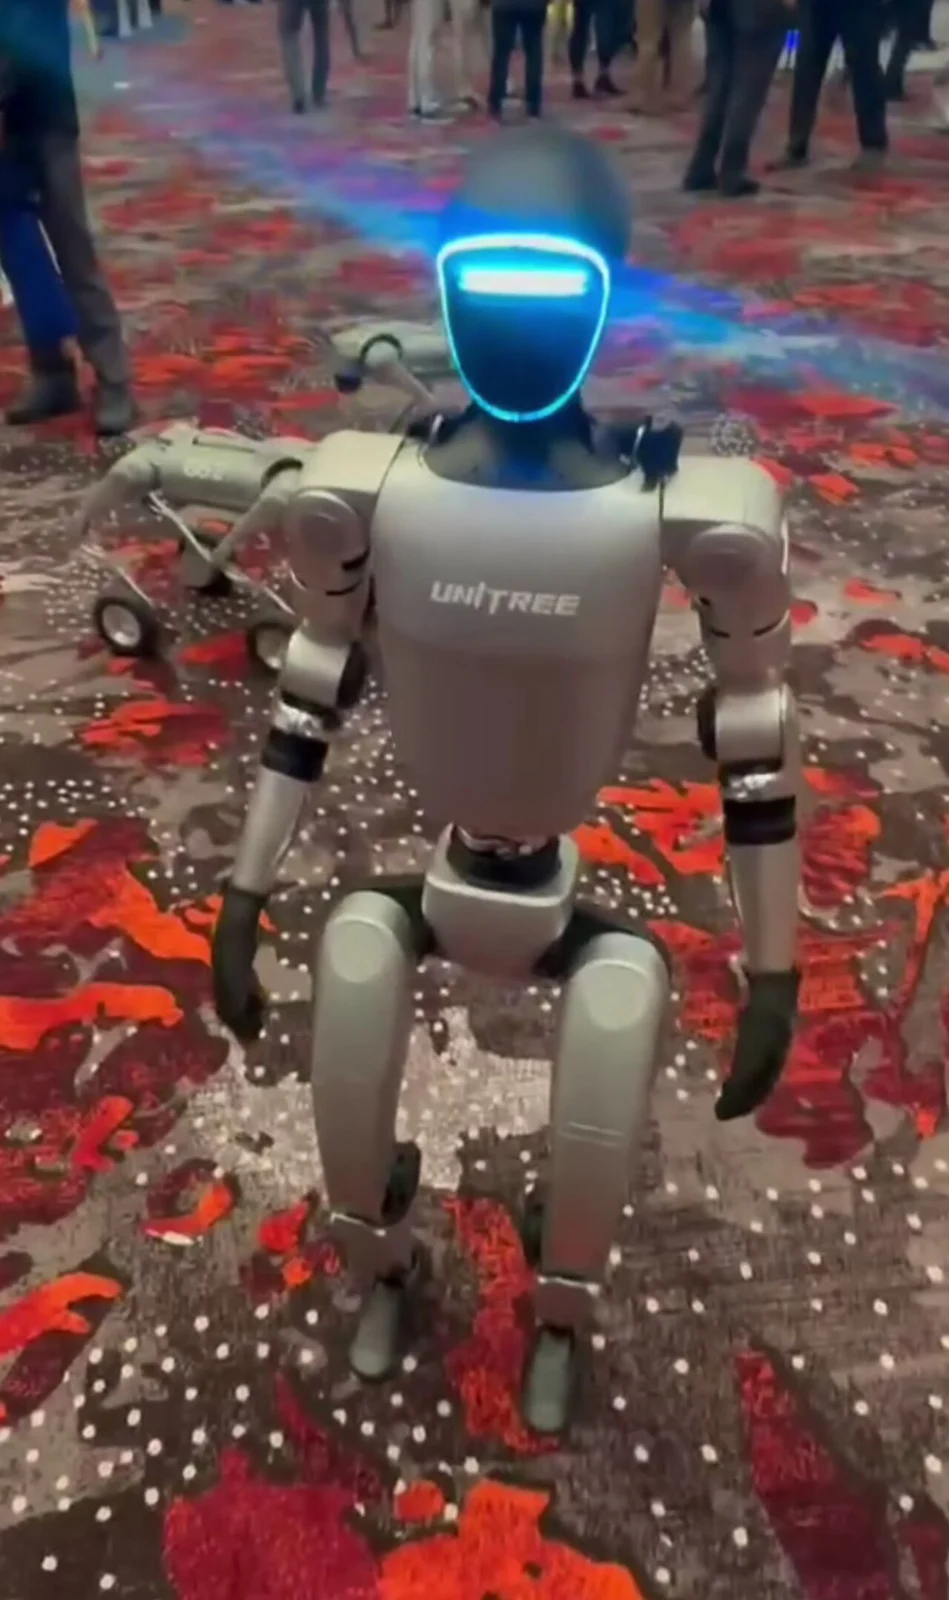
Editorial graphic showing hand tracks and temporal task segments in an egocentric robot demonstration video
Robotics data

How Perceptron Segments Egocentric Robot Demonstration Videos

Perceptron reports 0.280 semantic end-to-end F1 on WGO-Bench. We clearly explain hand tracking, task segmentation, baselines and benchmark limits.

Read article
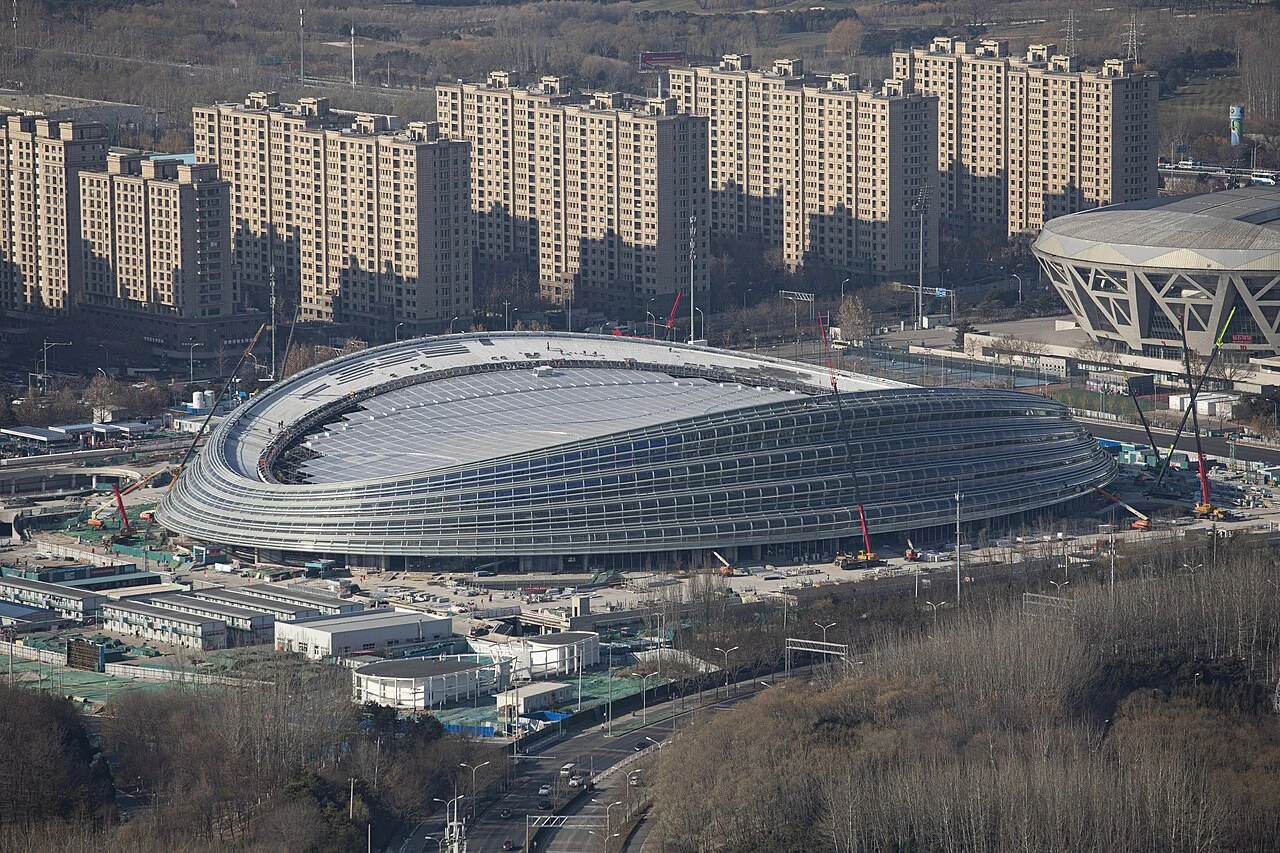
TechniaHQRobot diagram-style title graphic for the 1X NEO 25-DOF tendon-driven hand
Humanoid robot hands

How 1X Built NEO’s 25-DOF Tendon-Driven Hands

How 1X designed NEO’s 25-DOF tendon-driven hands, including finger motion, wrist movement, compliance and the limits of current demonstrations.

Read article
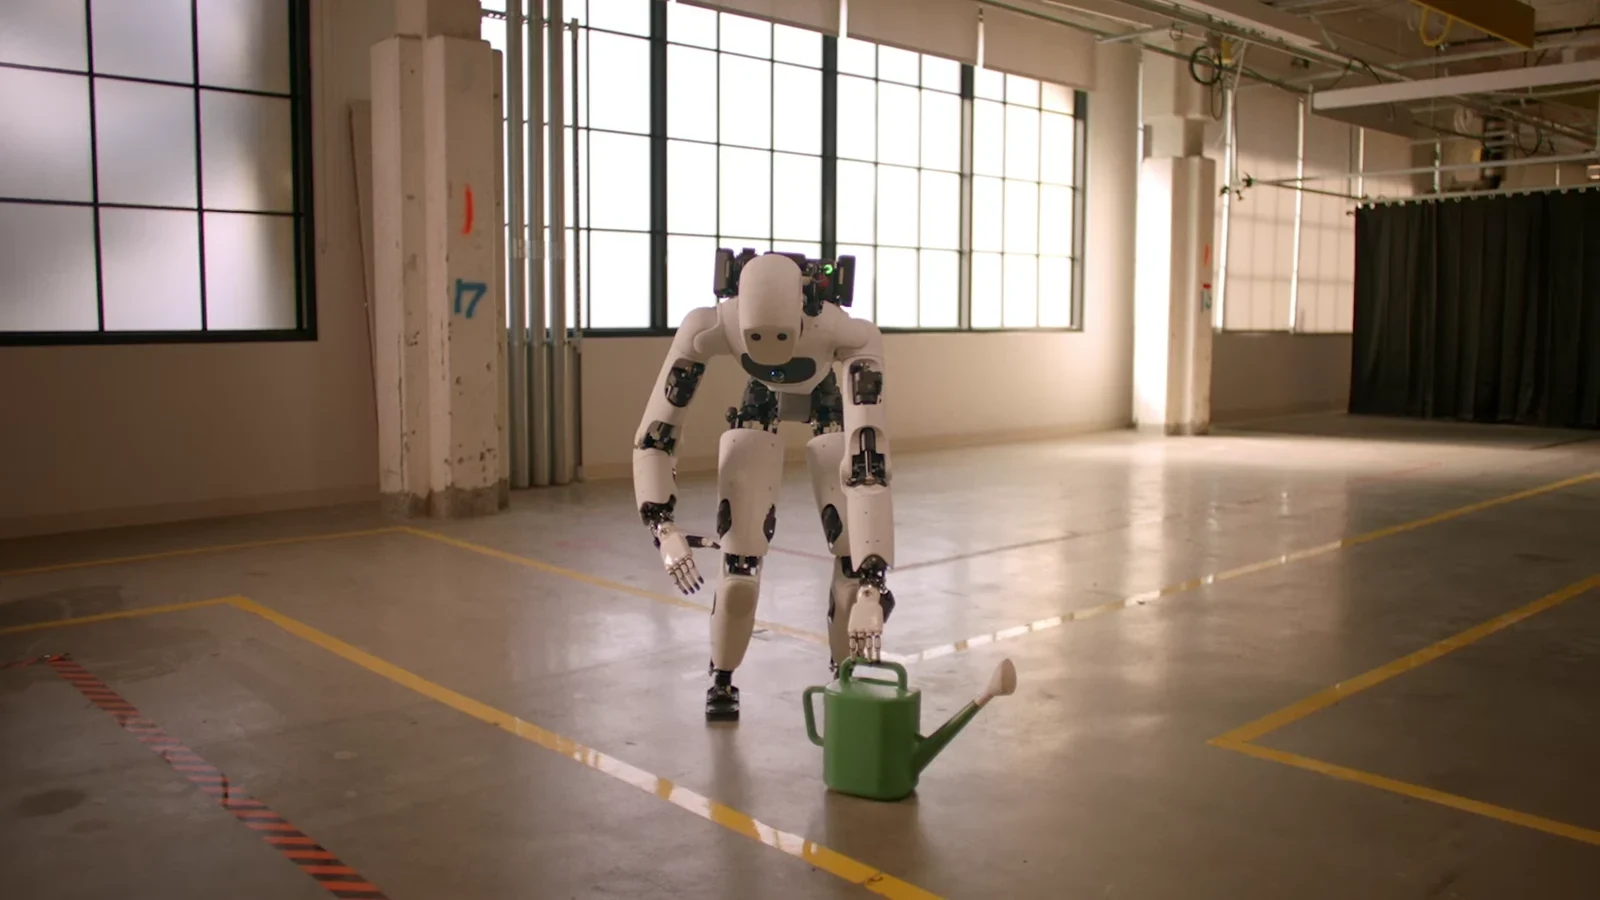
TechniaHQRobot editorial graphic for Flying Excavator Engineering Why the Render Is Hard to Build
Engineering concepts

Flying Excavator Engineering Why the Render Is Hard to Build

An engineering analysis of the flying excavator concept, covering payload, rotor wash, energy demand, stability, control and construction-site safety.

Read article
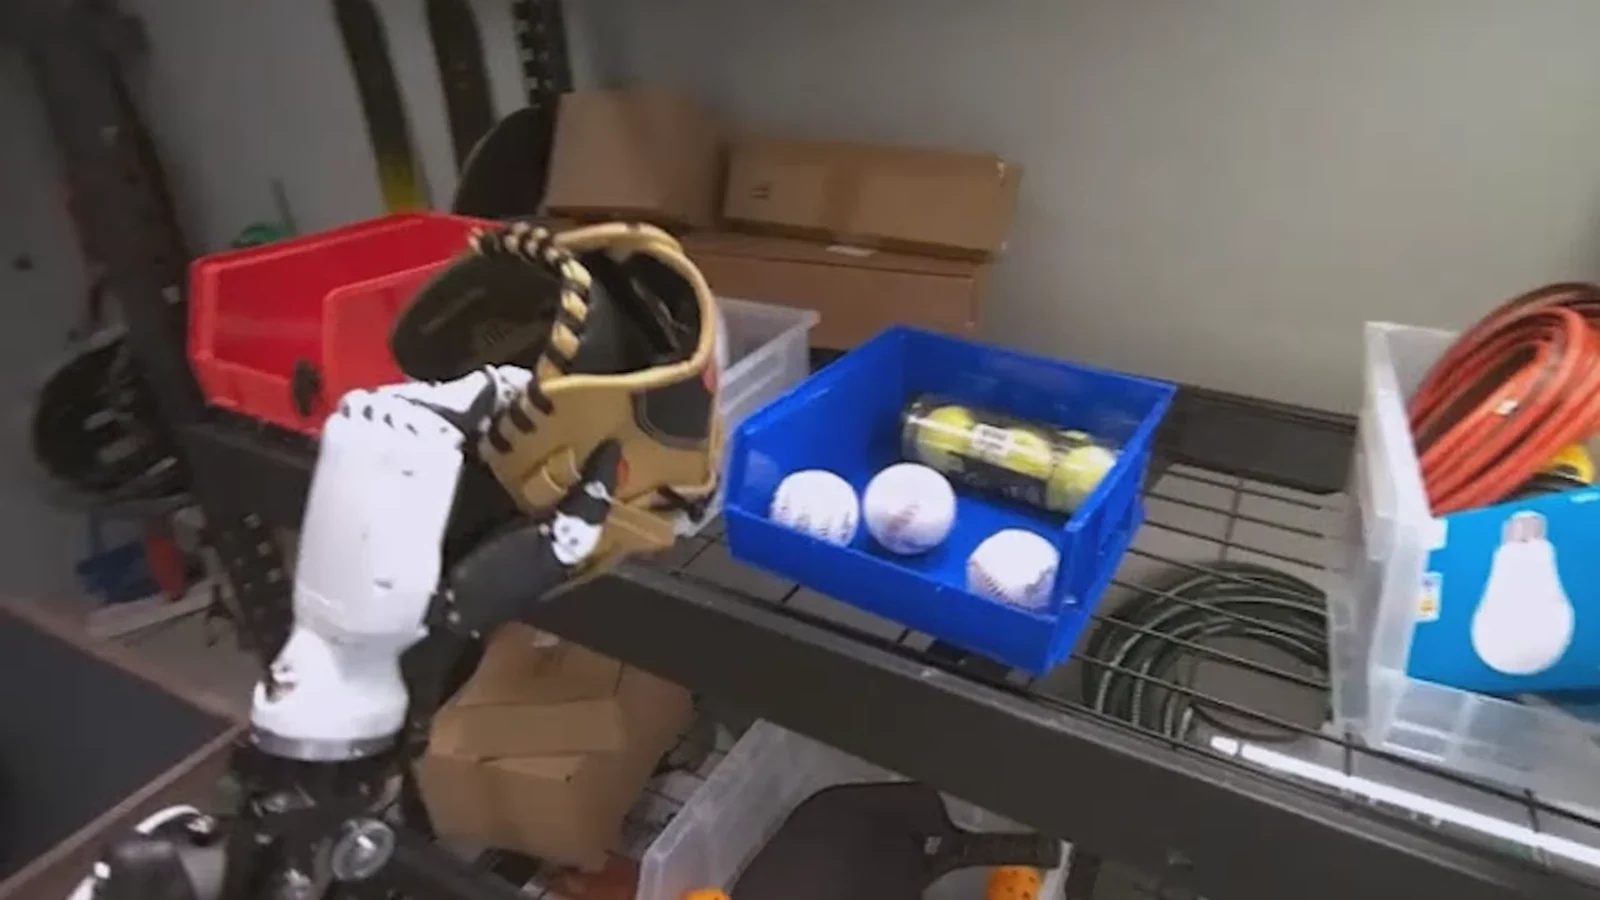
TechniaHQRobot editorial graphic for What Humanoid Robot Mass Production Requires in Practice
Robot manufacturing

What Humanoid Robot Mass Production Requires in Practice

A practical guide to humanoid mass production, from repeatable assembly and supplier capacity to testing, failure rates, maintenance and unit economics.

Read article
TechniaHQRobot editorial graphic for Humanoid Robots Developed in Spain Verified Projects Guide
Humanoid robots by country

Humanoid Robots Developed in Spain Verified Projects Guide

A verified guide to Spanish humanoid robotics, including PAL Robotics, TALOS, KANGAROO, REEM-C and UC3M RoboticsLab’s TEO research platform.

Read article
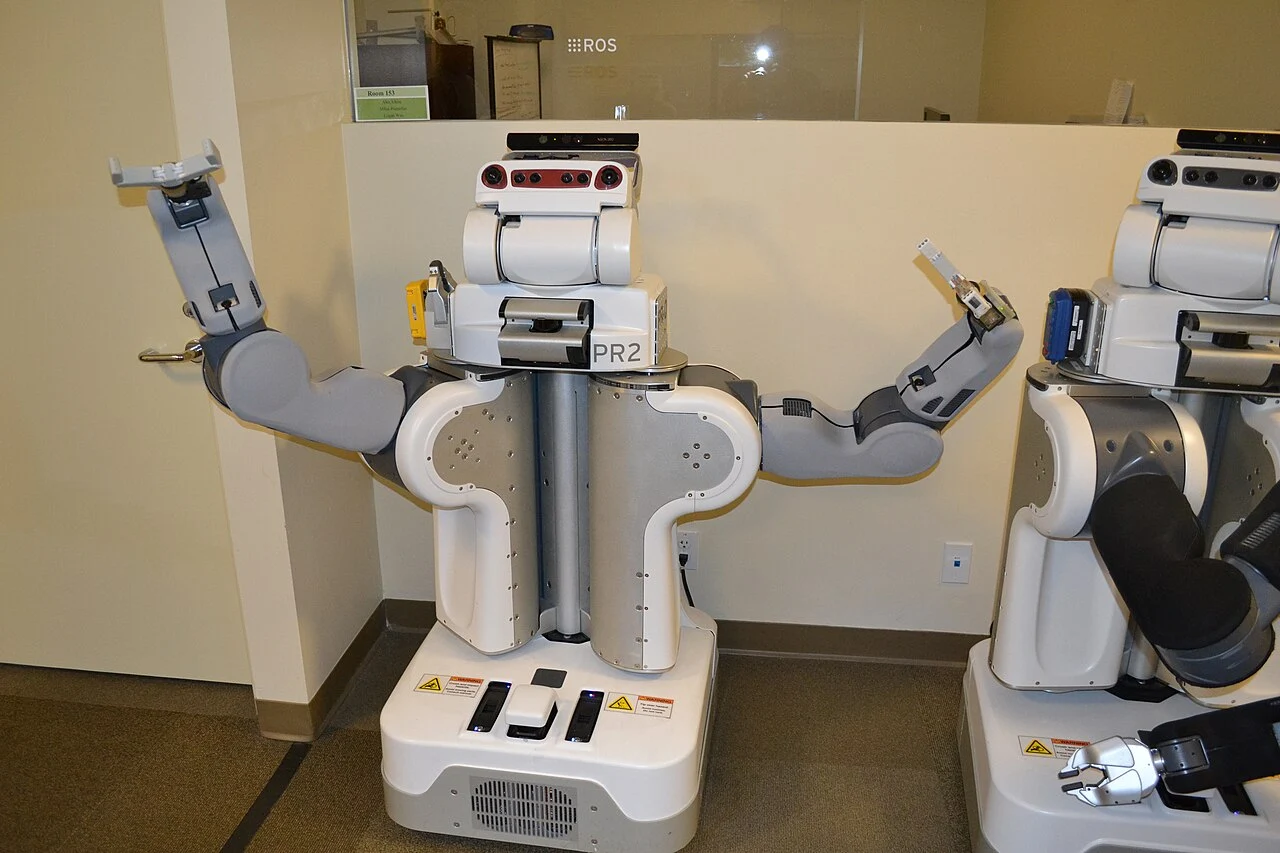
TechniaHQRobot editorial graphic for How Humanoid Robots Performed Teleoperated Laparoscopic Surgery
Medical robotics

How Humanoid Robots Performed Teleoperated Laparoscopic Surgery

A close reading of the UC San Diego humanoid surgery study, including teleoperation, laparoscopic tools, porcine procedures and barriers to clinical use.

Read article
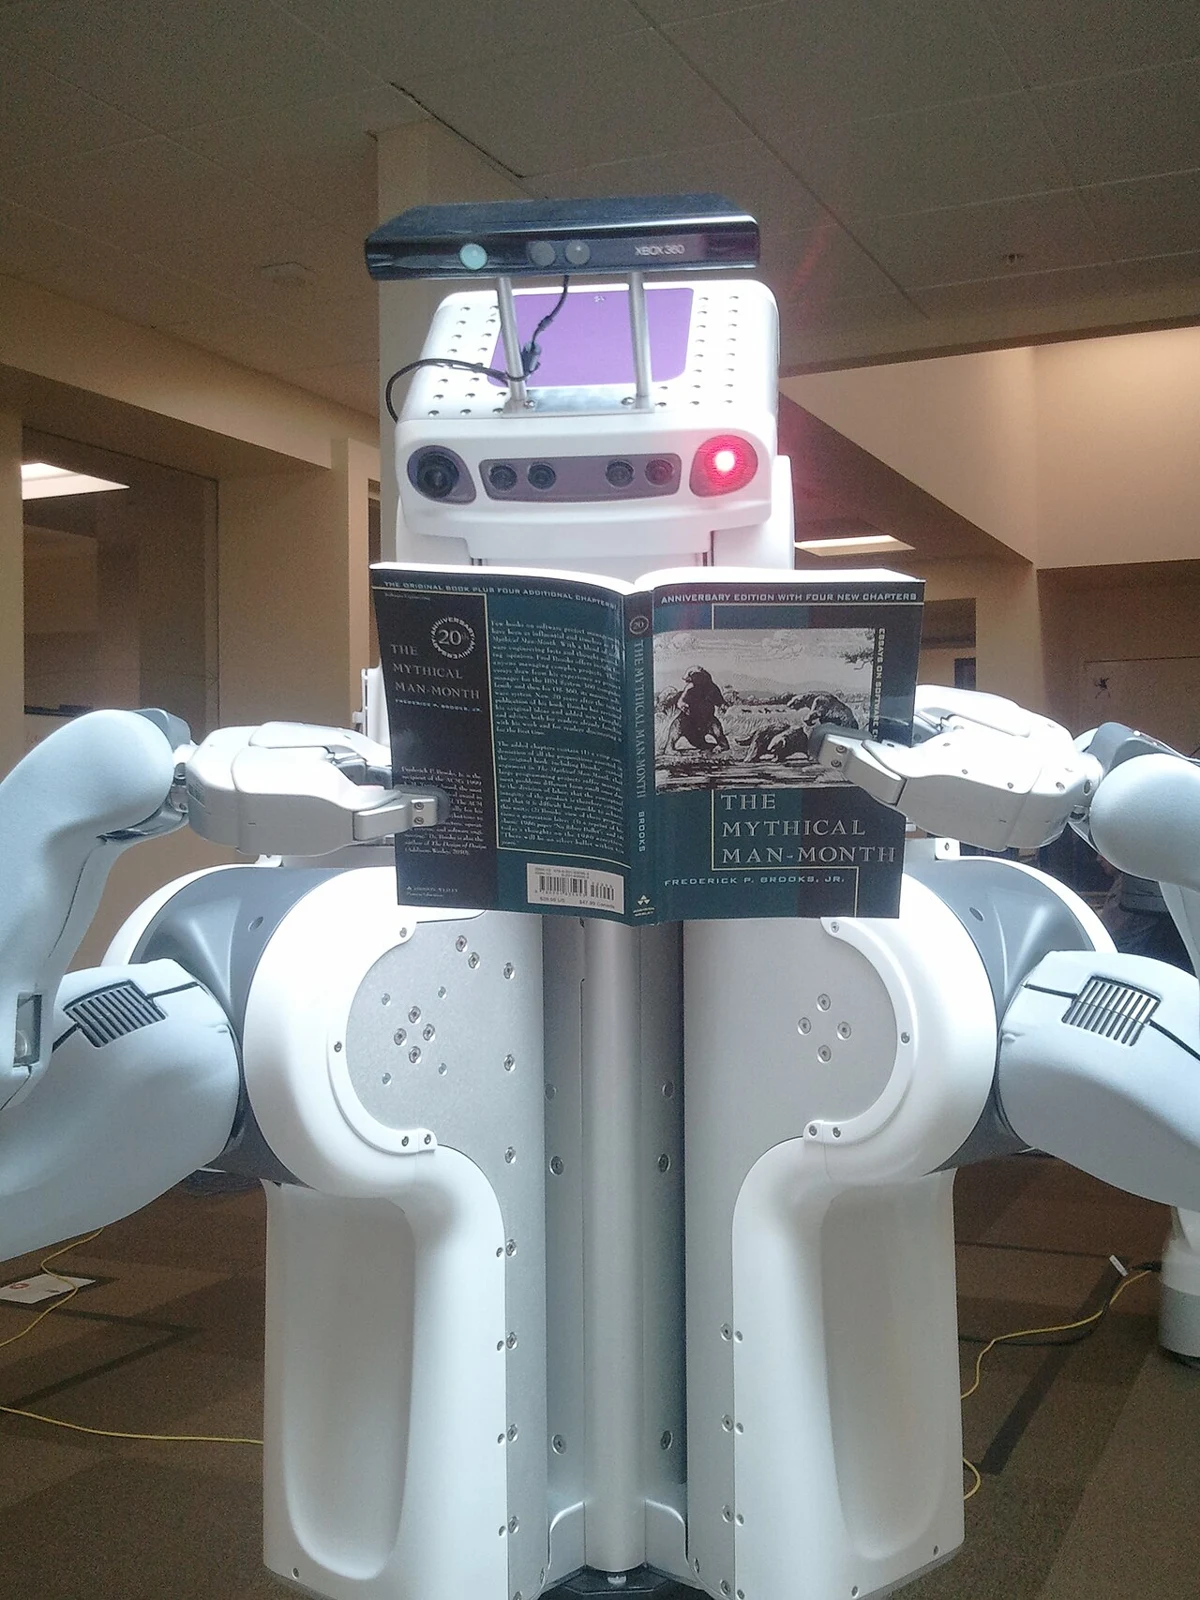
TechniaHQRobot editorial graphic for What UBTECH Revealed at Its 2026 Global Robotics Launch Event
Robot launches

What UBTECH Revealed at Its 2026 Global Robotics Launch Event

A measured report on UBTECH’s 2026 launch, separating confirmed UWorld U1 companion models from industrial Walker claims and promotional language.

Read article
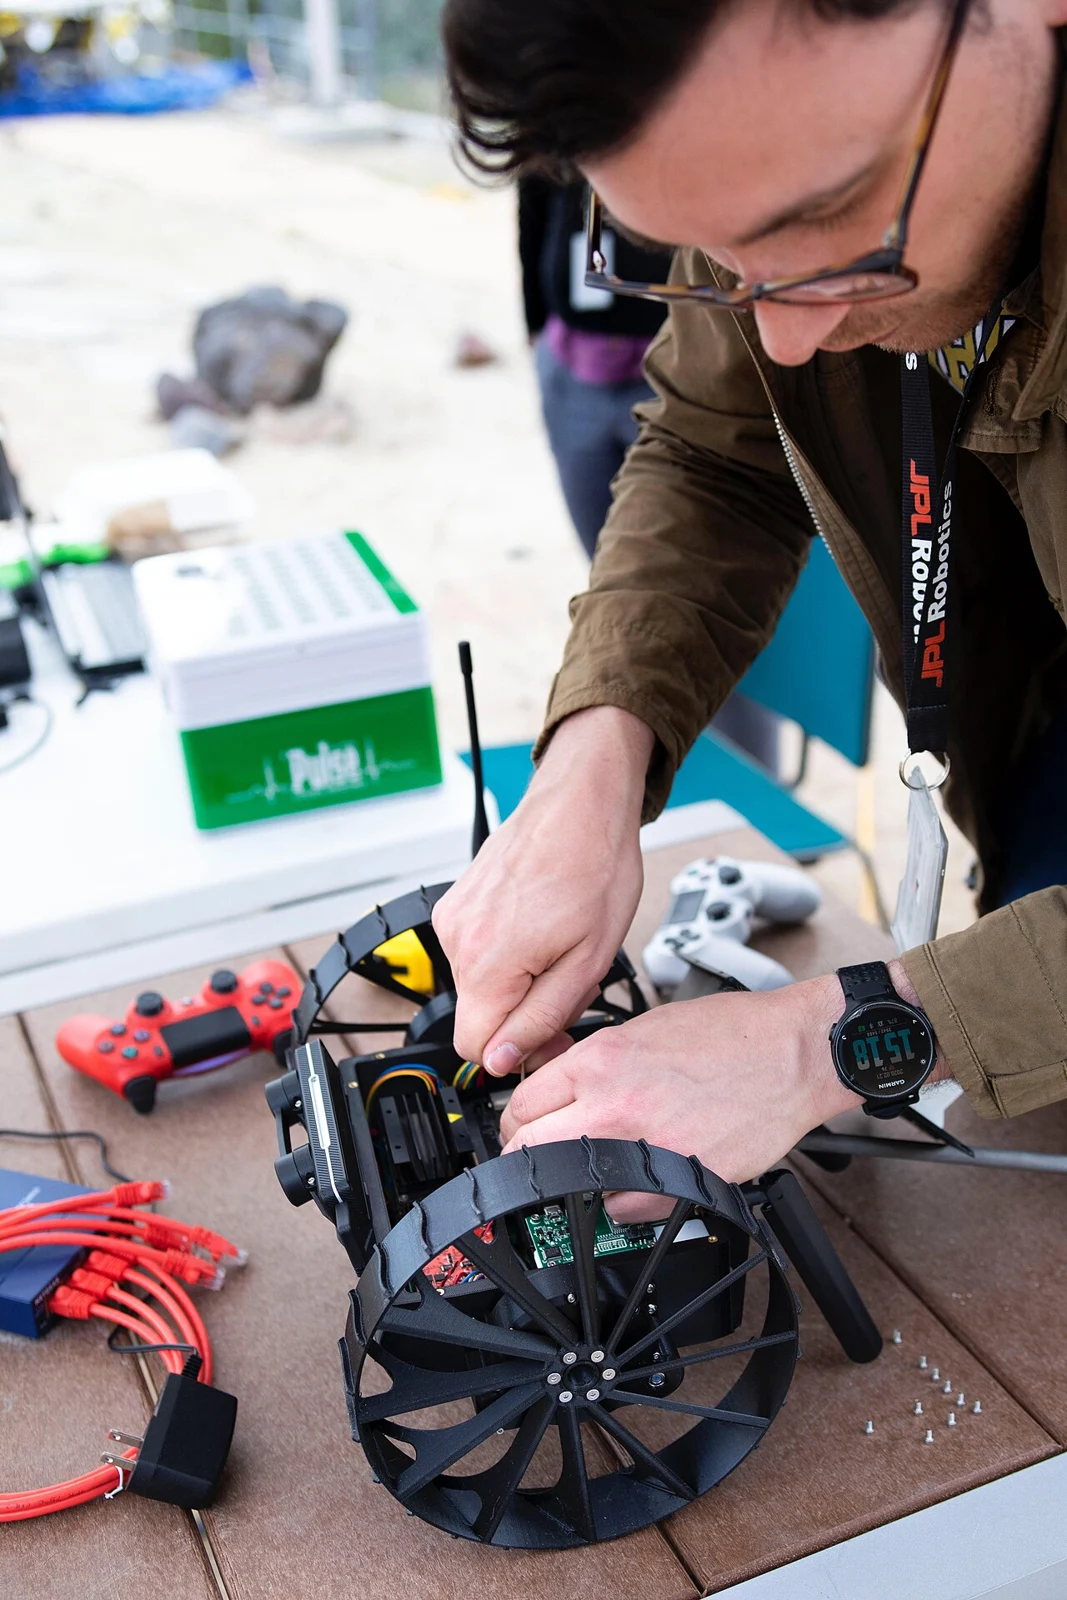
TechniaHQRobot editorial graphic for Why Robot Vision Fails on Glass, Mirrors and Reflective Objects
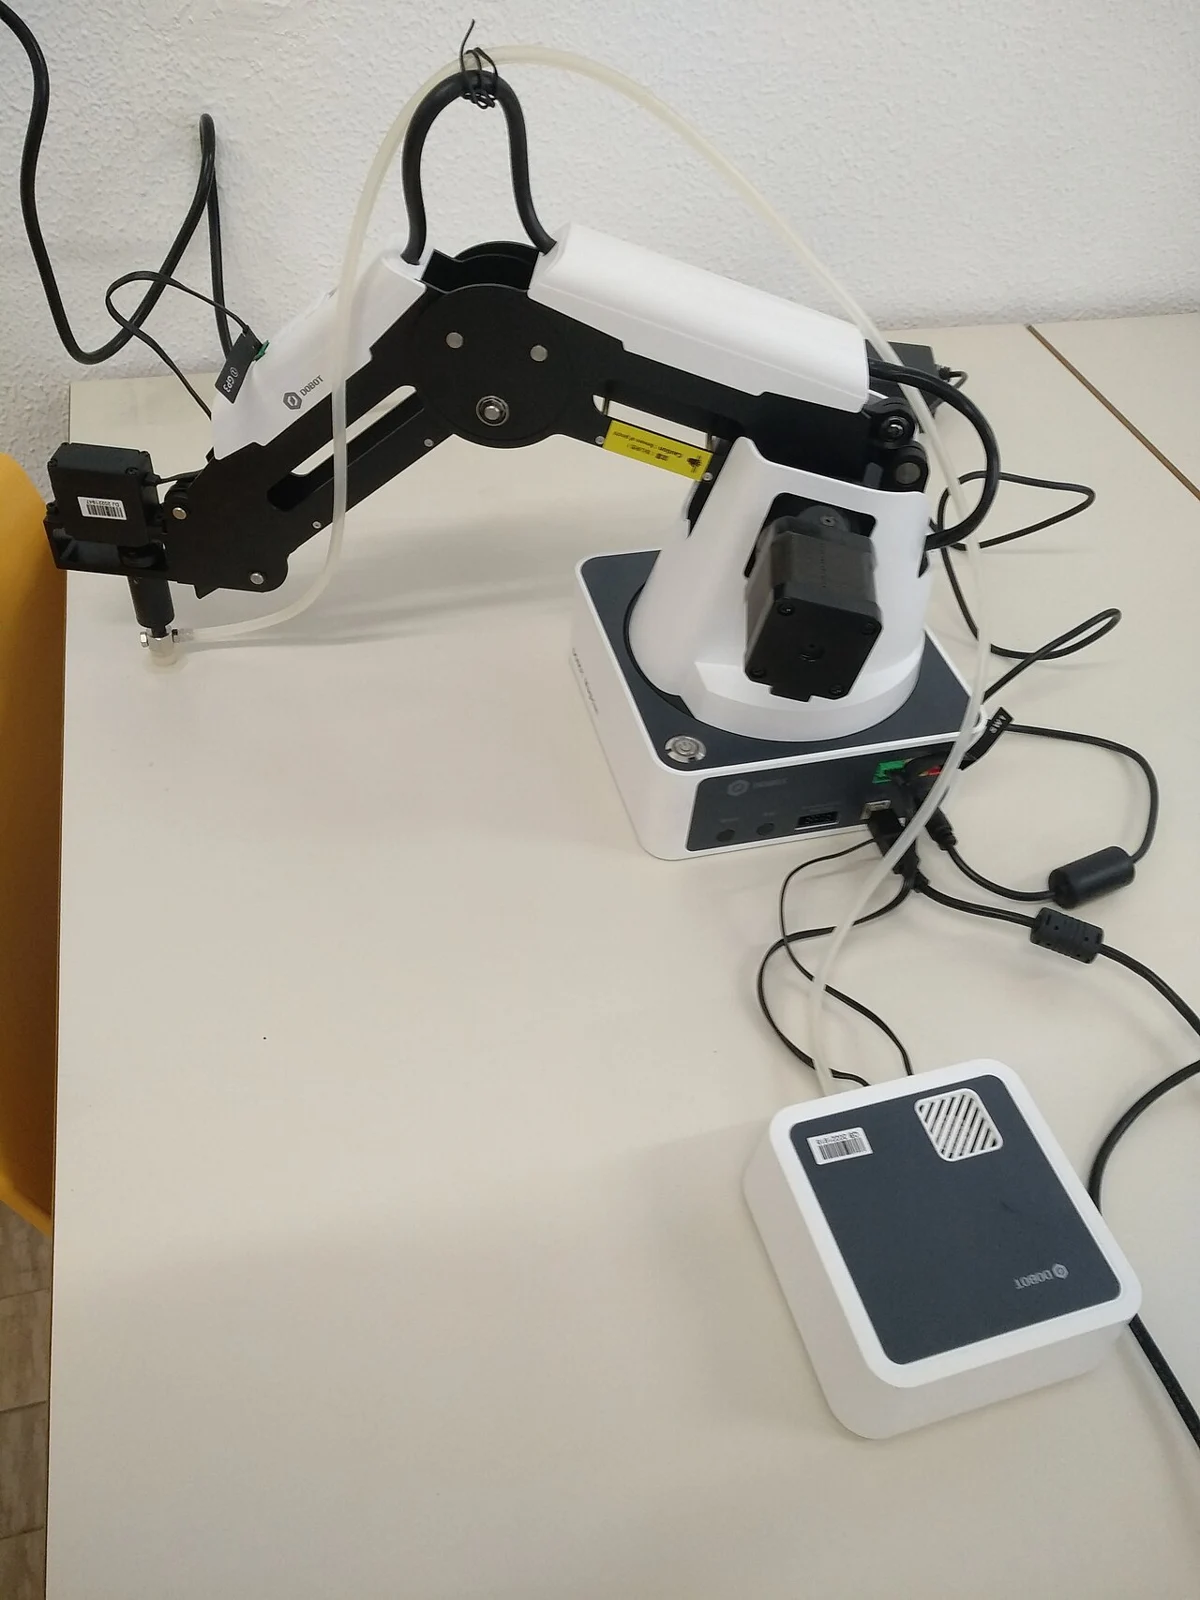
Robot perception

Why Object Recognition Is Not Enough for Robot Manipulation

A robot can correctly label a cup and still fail to grasp it. Manipulation requires geometry around the rim, glass edge, shadows, occluded gaps, transparent surfaces and safe gripper contact regions.

Read article
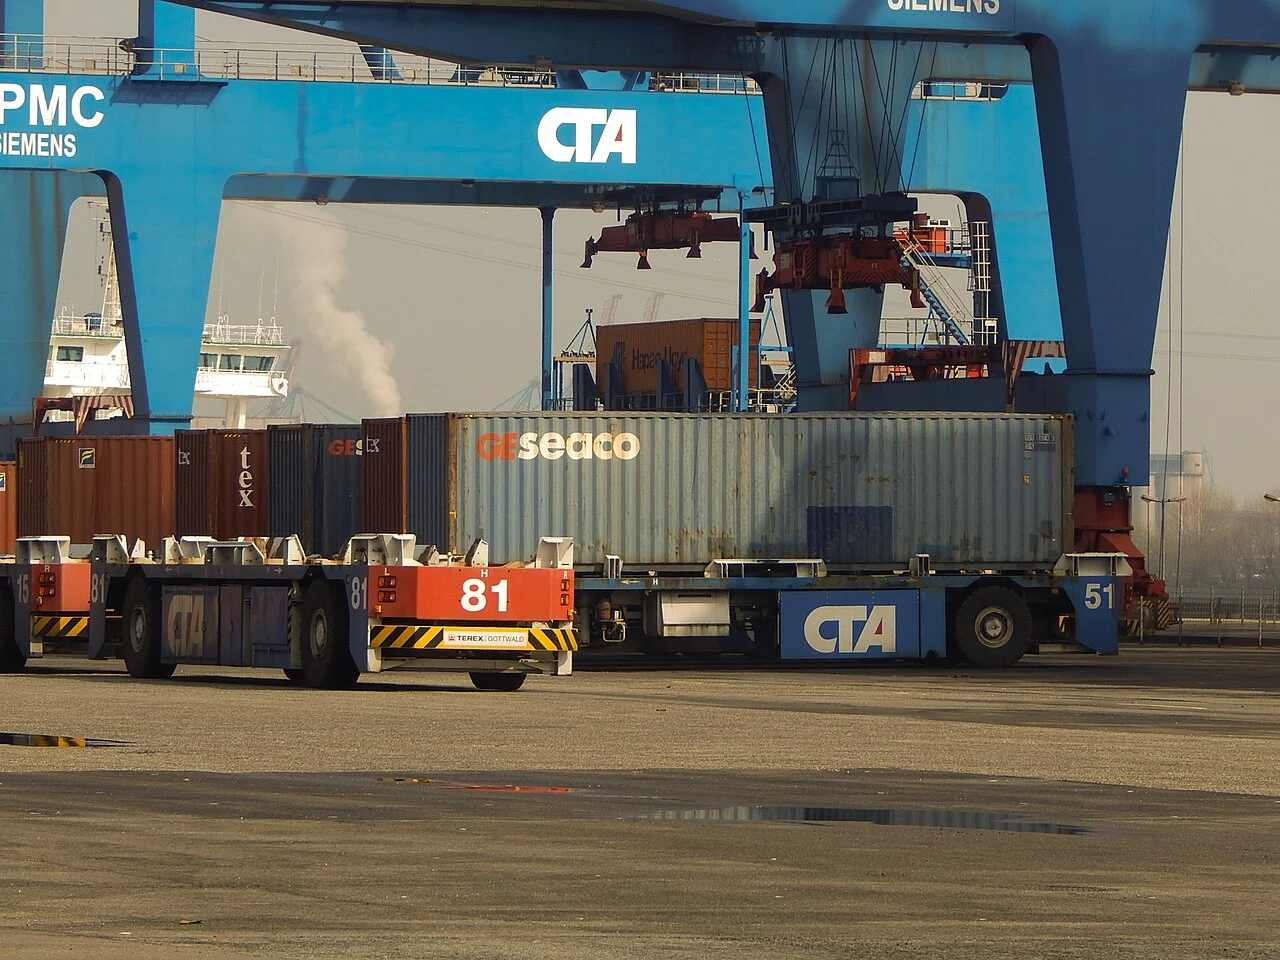
TechniaHQRobot editorial graphic for How Yaskawa High-Speed Delta Robots Handle Fast Pick-and-Place
Industrial robots

How Yaskawa High-Speed Delta Robots Handle Fast Pick-and-Place

How Yaskawa parallel robots achieve fast pick-and-place motion, including low moving mass, vision tracking, payload limits and model-identification caveats.

Read article
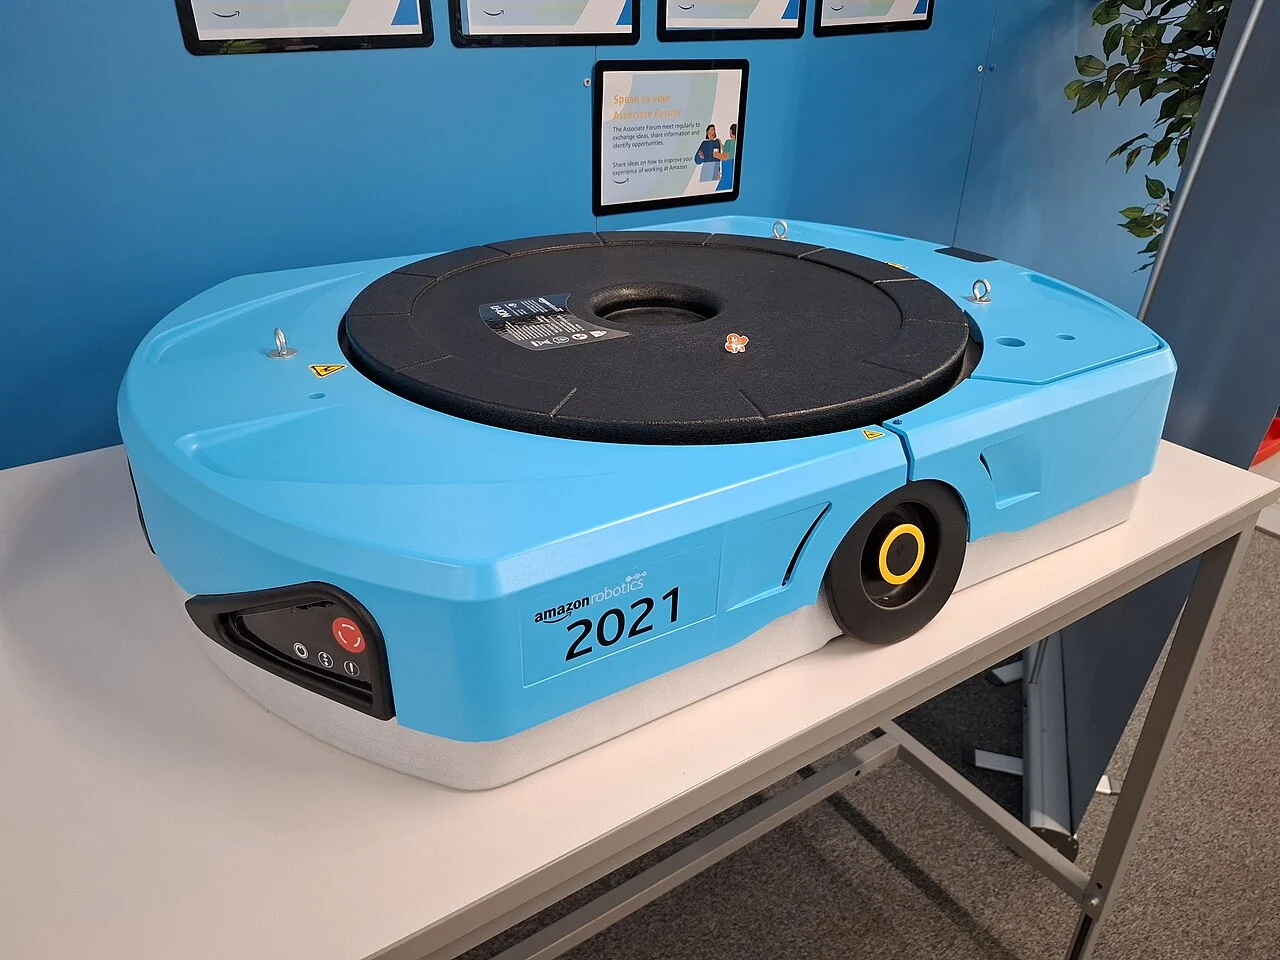
TechniaHQRobot editorial graphic for DJI Drone Range Comparison Cameras, Flight Time and Best Uses
Drones

DJI Drone Range Comparison Cameras, Flight Time and Best Uses

A fact-checked DJI comparison covering Neo, Mini 4 Pro, Air 3S, Avata 2 and Mavic 4 Pro cameras, flight time, sensing, storage and use cases.

Read article
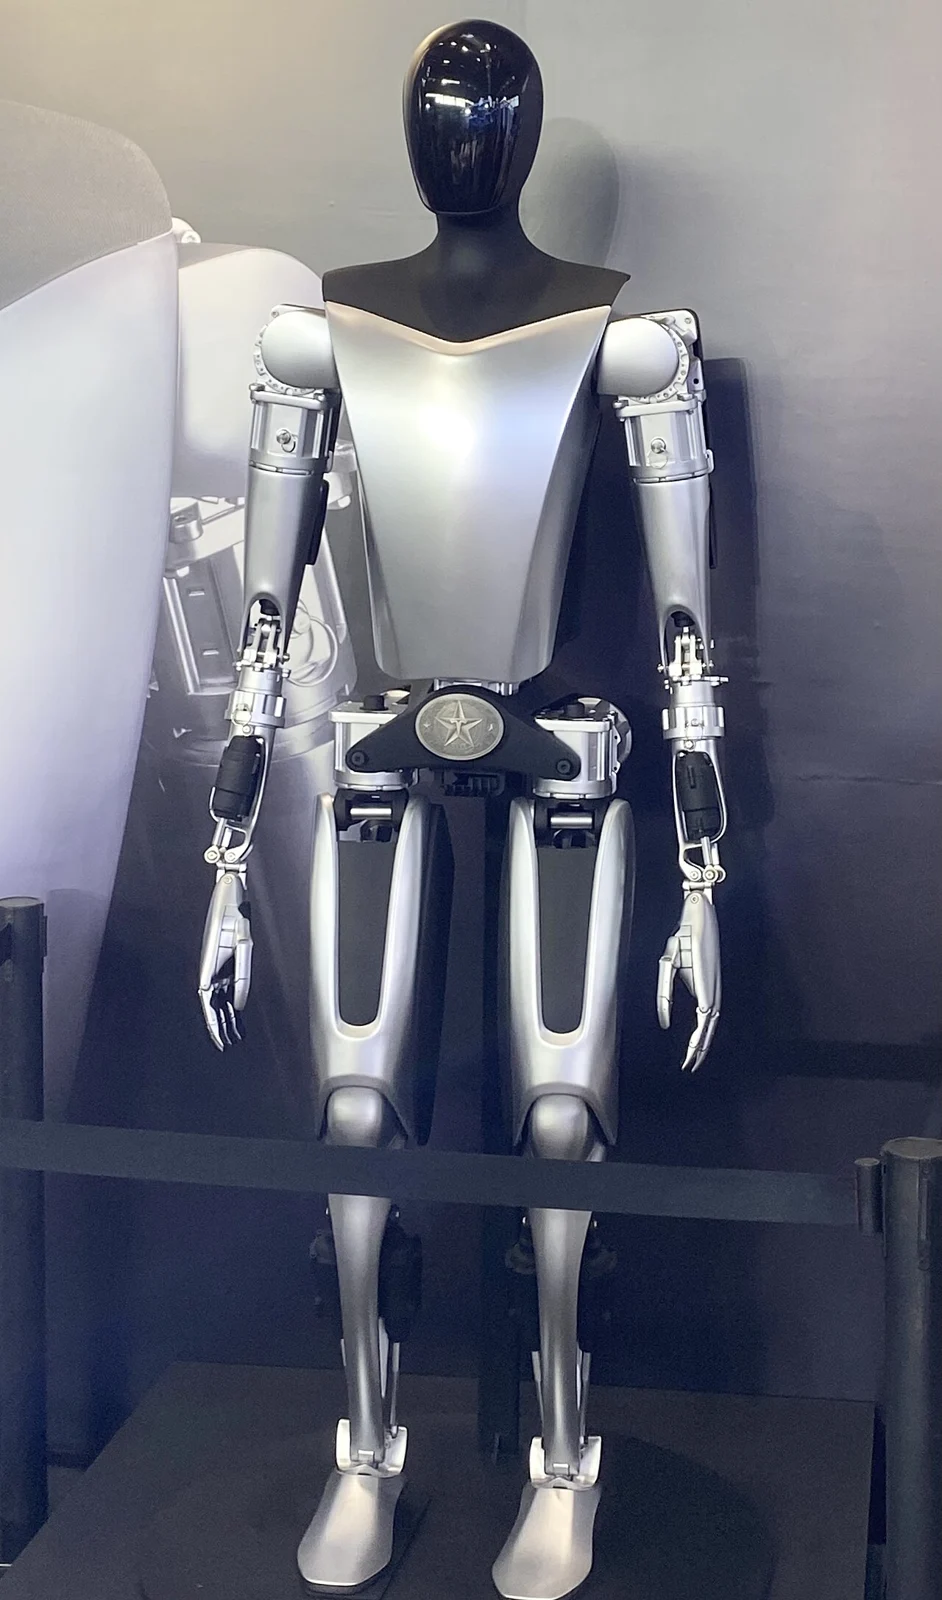
TechniaHQRobot editorial graphic for Humanoid Robots Developed in France Verified Projects Guide
Humanoid robots by country

Humanoid Robots Developed in France Verified Projects Guide

A verified map of French humanoid robotics, covering Wandercraft, Pollen Robotics, Enchanted Tools, NAO and the limits of broad humanoid labels.

Read article
TechniaHQRobot editorial graphic for Wandercraft Calvin 0.5 What the Prototype Proves
Industrial humanoids

Wandercraft Calvin 0.5 What the Prototype Proves

A fact-checked profile of Wandercraft Calvin 0.5, its industrial task target, Renault Group relationship, development pace and remaining limits.

Read article
TechniaHQRobot editorial graphic for Unitree Robot Dog Modified Into an Experimental Mobility Platform
Quadruped robots

Unitree Robot Dog Modified Into an Experimental Mobility Platform

An engineering review of a wheeled Unitree quadruped modified with a seat, covering balance, terrain, control, safety and medical-device limits.

Read article
TechniaHQRobot editorial graphic for EngineAI T800 Confirmed Specs, Demos and Limits
Humanoid robot profiles

EngineAI T800 Confirmed Specs, Demos and Limits

A measured technical profile of EngineAI’s T800 humanoid, separating reported height, mass, joints, battery and demonstrations from unverified claims.

Read article
Pepper robot image from the local TechniaHQRobot image library
Robotics

Pepper by SoftBank Robotics The Social Humanoid That Defined an Era

Pepper shaped social-robot design through speech, gestures and a chest display. This review covers its real use cases, interaction limits and continuing research value.

Read article
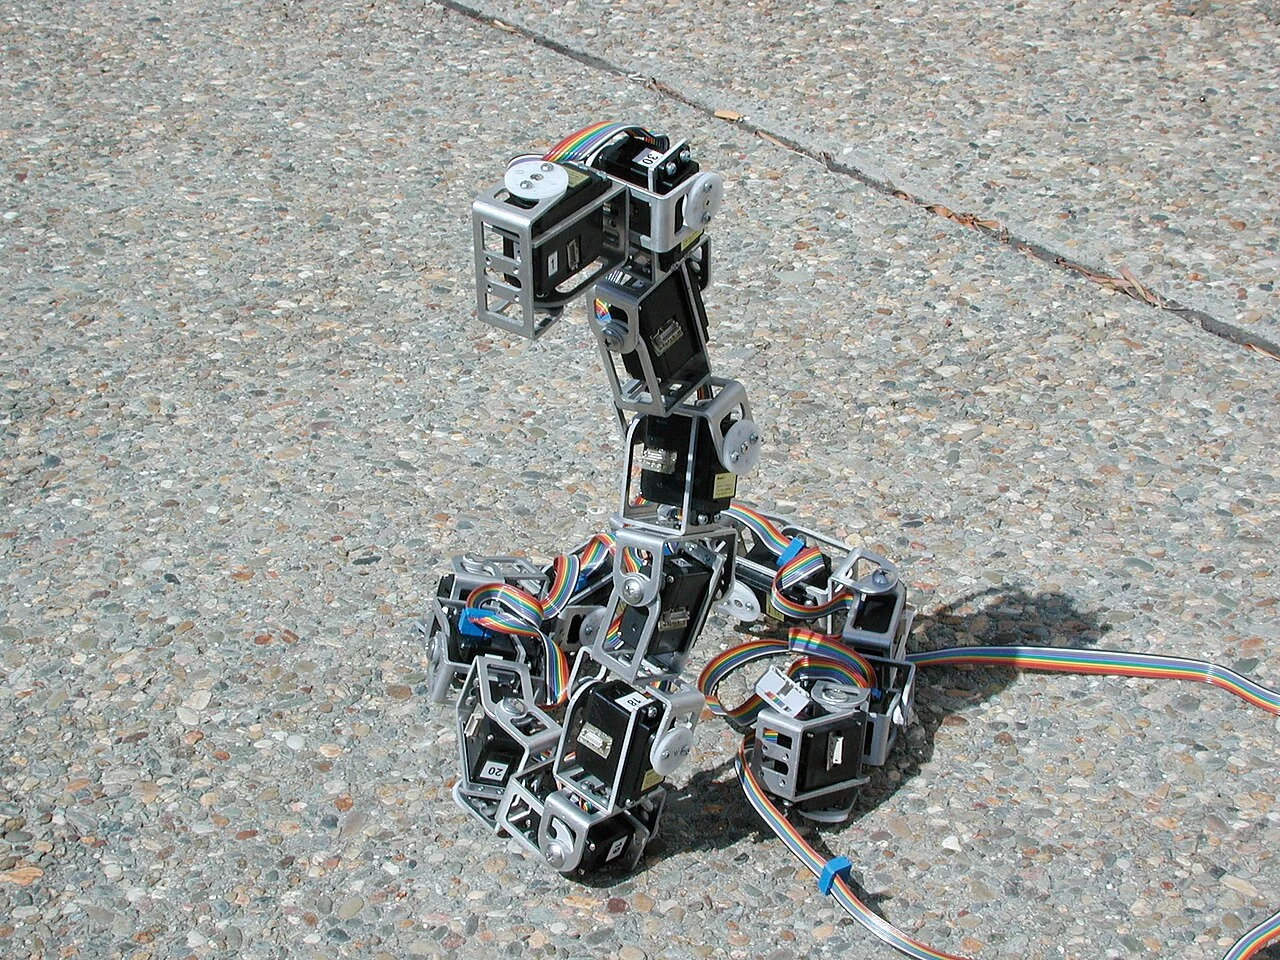
NASA Robonaut image from the local TechniaHQRobot image library
Robotics

Rice and NASA iMETRO Dynamic Simulation Open-Source Space Robotics for Spacecraft Interiors

Rice University’s iMETRO simulator studies robots moving and manipulating inside spacecraft. This review covers model fidelity, reproducibility and hardware validation.

Read article
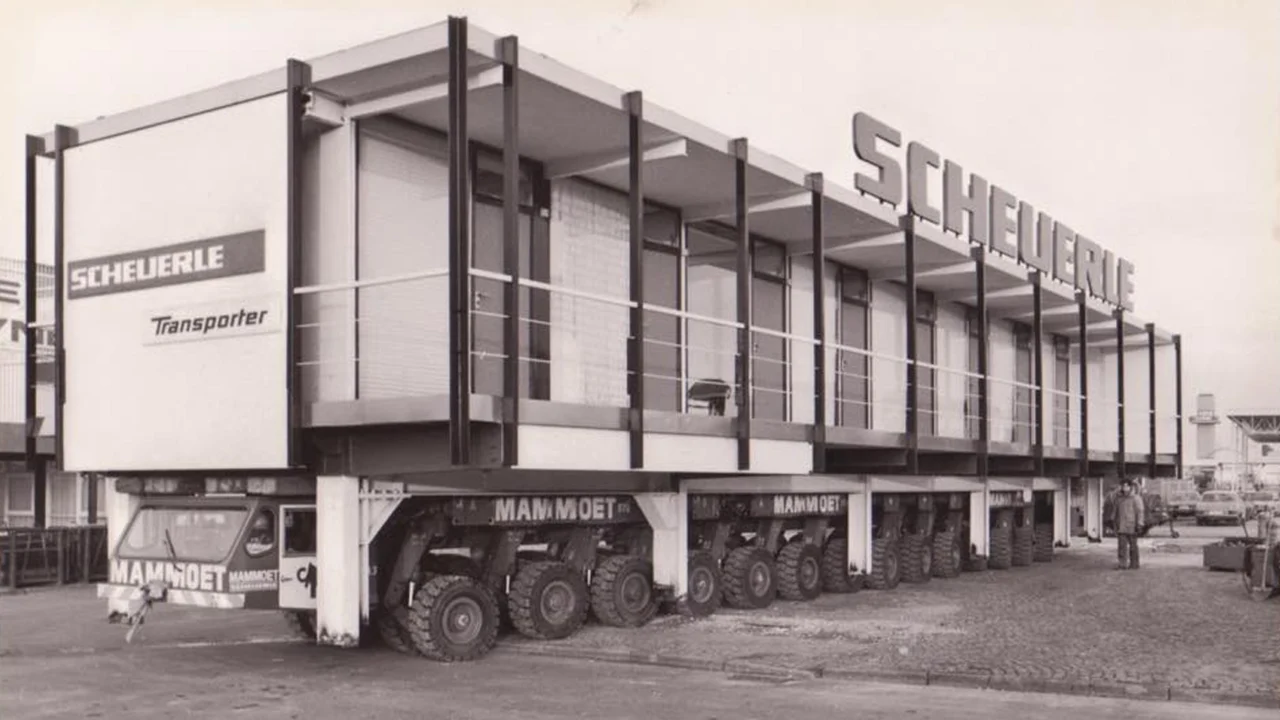
UBTECH humanoid image from the local TechniaHQRobot image library
Robotics

UBTECH Ultra-Bionic Humanoid Robot What the Clip Shows and What Still Needs Proof

A TechniaHQRobot article on an ultra-bionic UBTECH humanoid robot clip and how to read lifelike humanoid demos carefully.
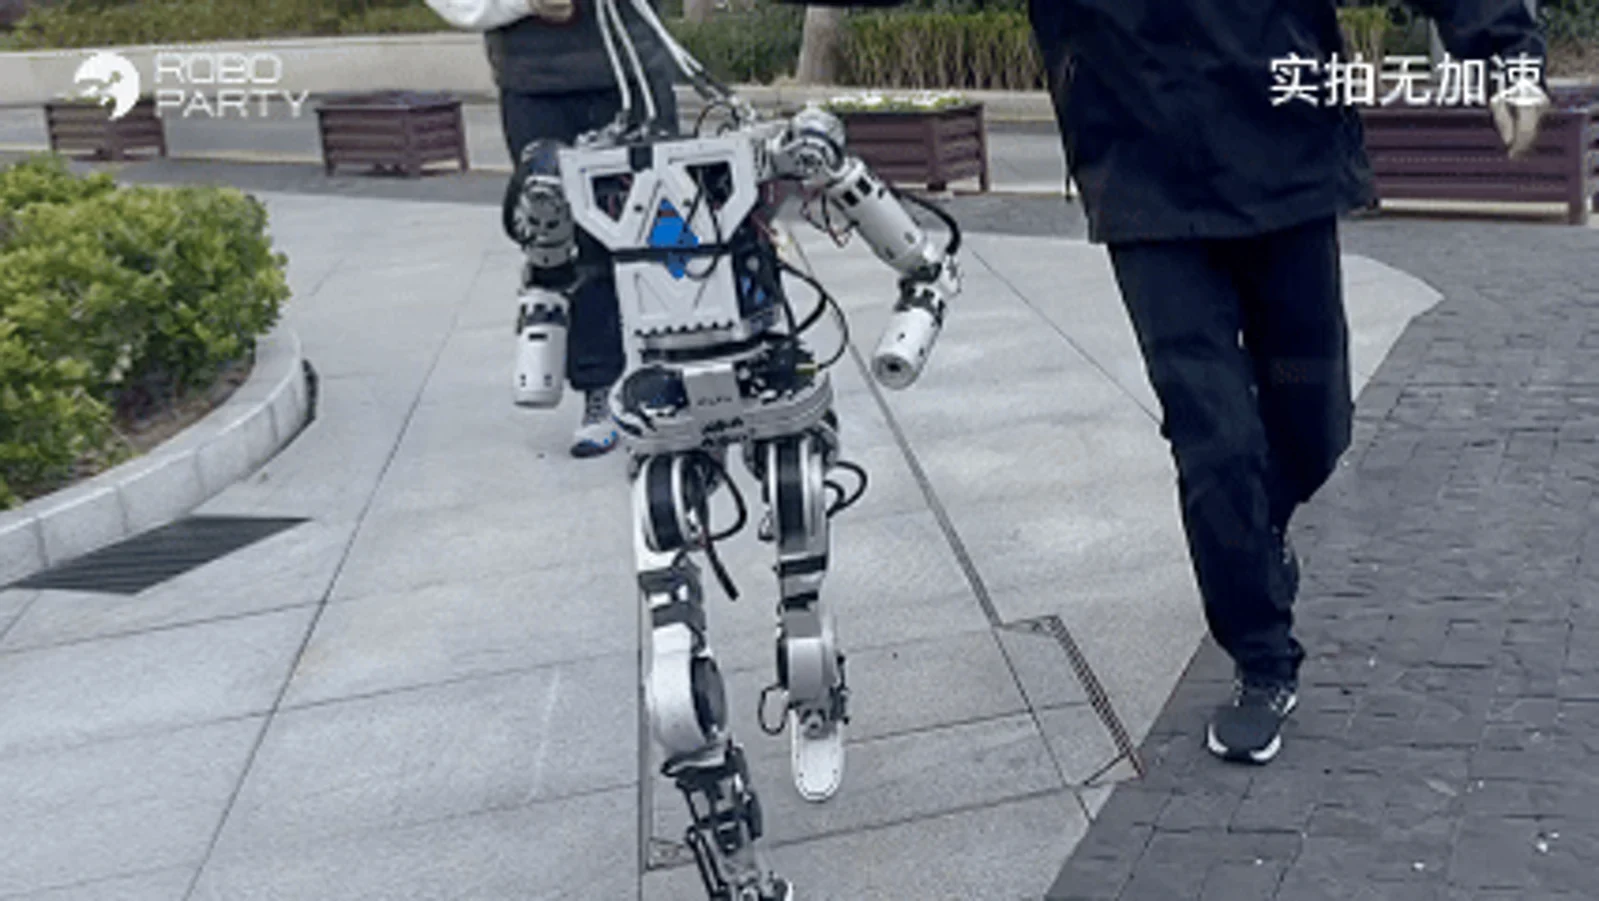
Read article
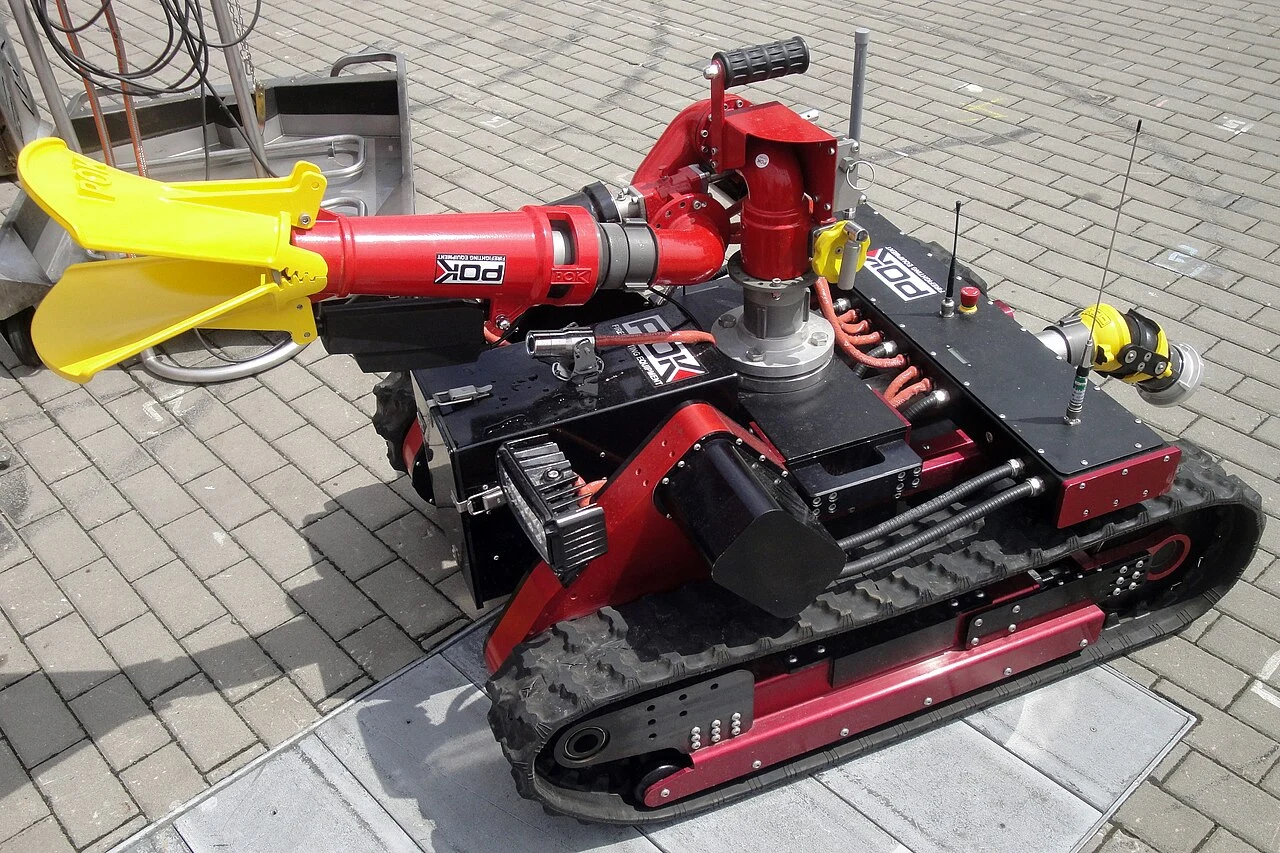
AgiBot humanoid image from the local TechniaHQRobot image library
Robotics

AgiBot Humanoid Robot Hardware Teardown EtherCAT, DCU Boards and Motor Control

A TechniaHQRobot article on an AgiBot humanoid hardware teardown, including EtherCAT, DCU boards, power cards and motor control sections.
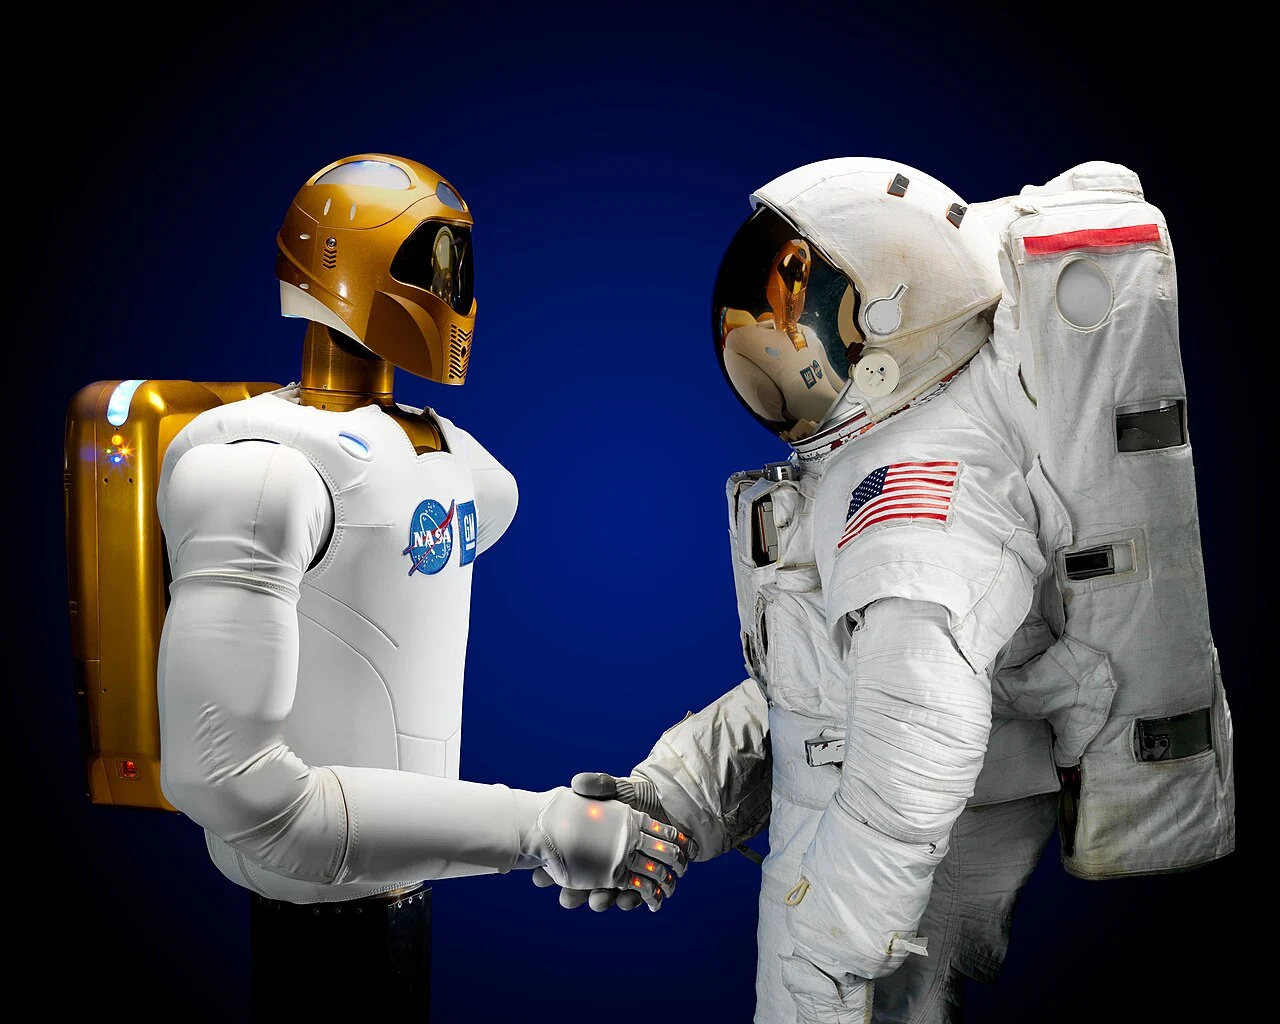
Read article
Force and tactile sensor icon used as a local visual marker for soft robotics research
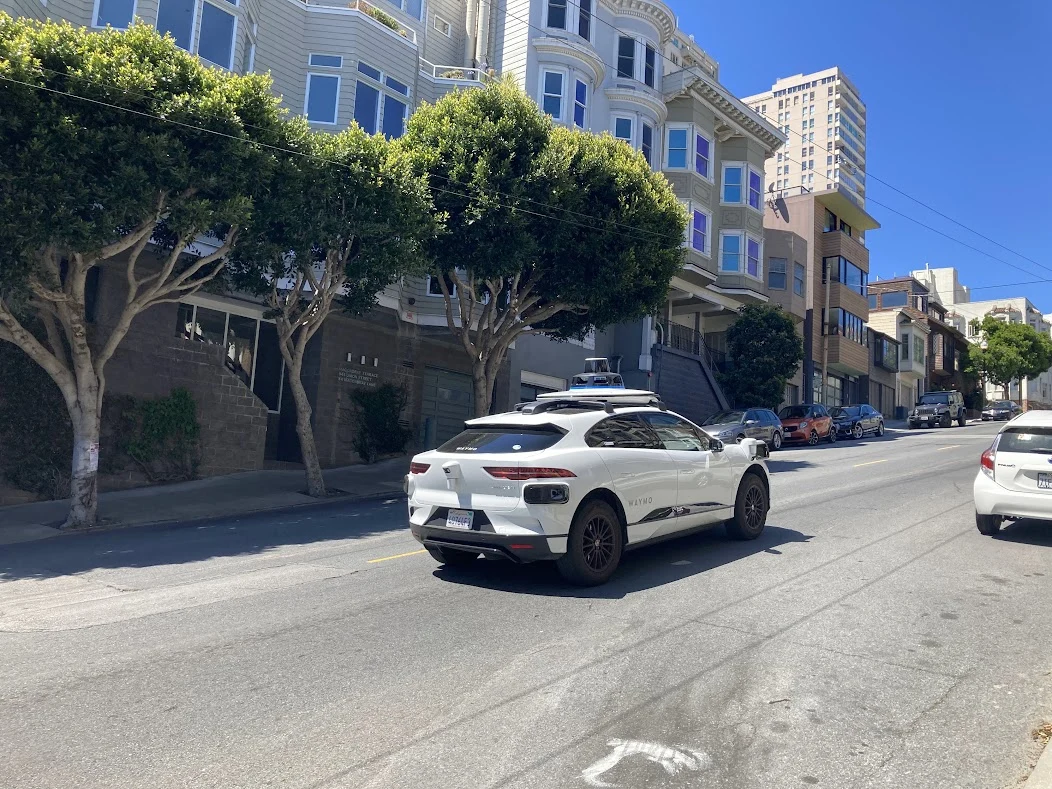
Robotics

University of Bristol Soft Robot Uses a Liquid Metal Droplet to Boost Artificial Muscle Pumps
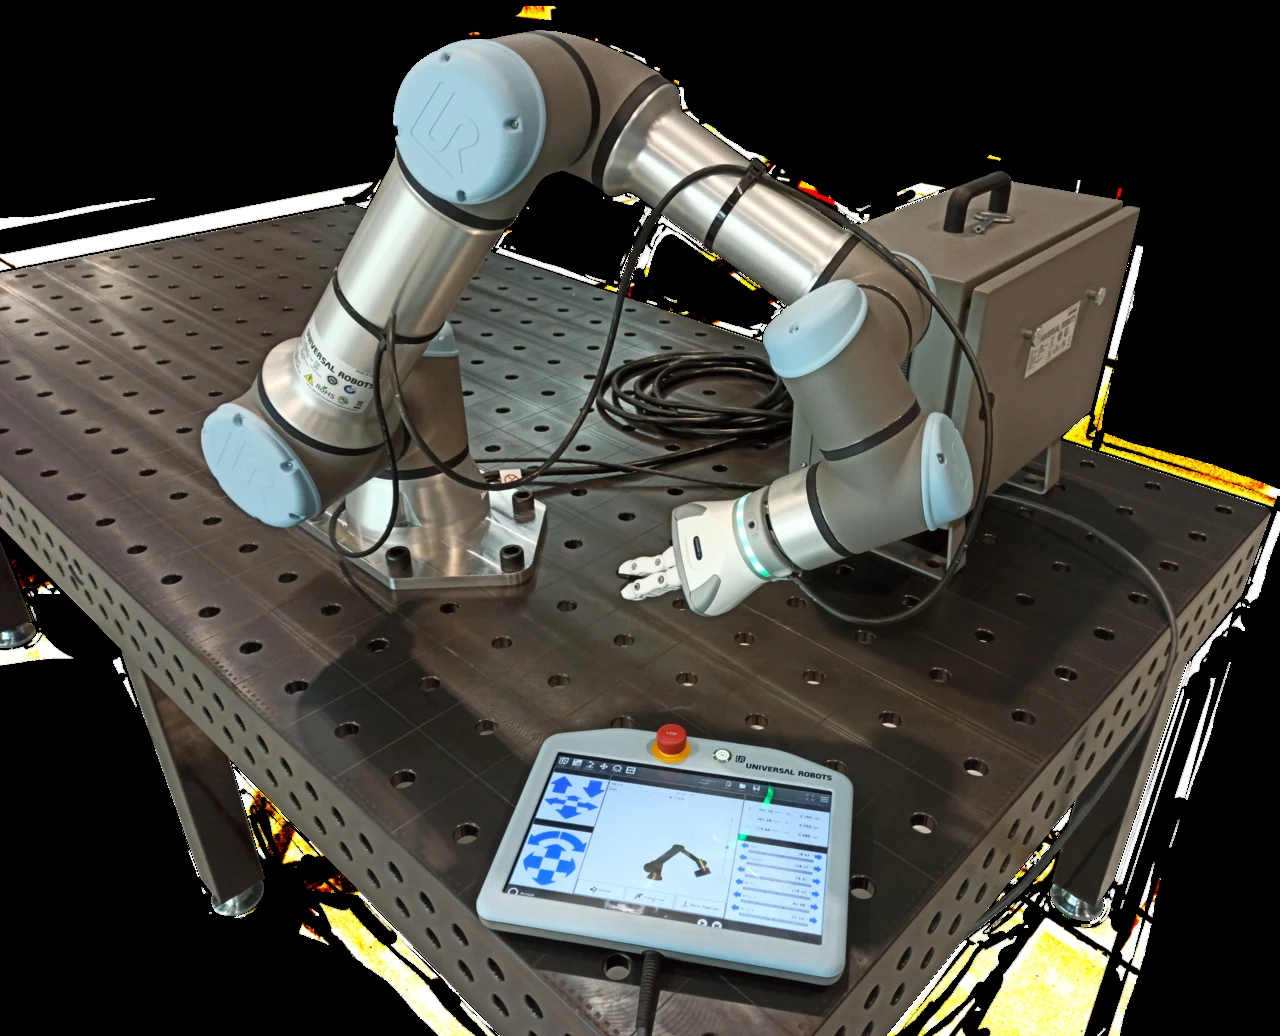
Bristol researchers adjust a liquid-metal droplet’s surface tension to increase pump output. This review explains the mechanism, reported energy gain and remaining durability questions.

Read article
Humanoid robot image from the local TechniaHQRobot image library used for regional robotics coverage
Robotics

How to Read Humanoid Robot Company Counts by Continent

A guide to checking regional humanoid company lists, including inclusion rules, headquarters, product status and the difference between company counts and deployments.

Read article
Humanoid robot data

Apptronik Apollo 2 turns Robot Park into a data factory for humanoid robots

How Apptronik uses Apollo 2, teleoperation, simulation and customer sites to collect humanoid robot data, plus the limits of its Robot Park evidence.

Read article
Humanoid robot demos

The T800 humanoid demo raises the real question what would make people feel safe near this robot?

A source-checked look at the EngineAI T800, separating high-dynamic demonstrations from published hardware specifications, production claims and the safety evidence needed for operation around people.

Read article
Robot tactile sensing

NRE-Skin gives robots a local protective reflex and injury detection

A source-checked explanation of NRE-Skin, the PNAS neuromorphic electronic skin that encodes touch into pulse trains, triggers local protective reflexes and detects damaged skin regions.

Read article
Robot demos

Unitree humanoid concert glitch what the video actually shows

Technical analysis of a Unitree humanoid concert glitch, the performer response, possible failure classes, stage safety and what the clip cannot prove.

Read article
Humanoid robots

LingBot 2.0 shows why embodied intelligence is harder than one clean robot demo

A source-checked look at the LingBot 2.0 family and the supplied multi-task teaser, separating visible chess, water-handling and sorting sequences from published LingBot-VLA 2.0 model evidence and undisclosed demo conditions.

Read article
Robot hardware

Inside a Humanoid Robot: Actuators, Cabling, Bearings and Thermal Design

TechniaHQRobot breaks down why humanoid robots are dense mechanical systems made of machining, bearings, electronics, sensors, cabling and thermal constraints before software even takes control.

Read article
Domestic robots

What a Plant-Watering Robot Clip Can and Cannot Show

A plant-watering robot clip illustrates a bounded household task. This review separates the visible sequence from unverified autonomy, sensing, spill handling and recovery claims.

Read article
Robot safety

Pain-like feedback could make humanoids more durable, not more human

A technical guide to pain-like protective feedback in robots, separating tactile danger detection, local reflexes and hardware damage sensing from claims about biological pain or consciousness.

Read article
Humanoid deployment analysis

Humanoid robot maps need to separate documented pilots from demo visibility

How to separate humanoid factory deployments, commercial pilots, customer trials and public demonstrations, using current Figure and Agility records as documented examples.

Read article
Robot design

Robot Design Around the World: How Form Follows the Job

An engineering guide to robot form factors using selected systems from a 40-design collection, with concrete criteria for reach, payload, mobility, safety, tooling and maintenance.

Read article
TechniaHQRobot editorial graphic for Why Humanoid Robot Hardware Is Still So Expensive to Build
Humanoid hardware

Why Humanoid Robot Hardware Is Still So Expensive to Build

Humanoid robot hardware cost is concentrated in repeated joint modules, dexterous hands, precision transmissions, sensing, power, compute and the manufacturing work needed to calibrate and validate the complete body. Public bill-of-material estimates are useful only when they state the robot configuration and exclude software, tooling, warranty and field support.

Read article
Global robotics analysis

Robotics Across 22 Countries: Industry, Research and Robot Platforms

In-depth analysis of the countries shaping global robotics through industrial robots, humanoids, drones, medical robotics, agriculture, defense, logistics, components and Physical AI.

Read article
DIY robotics

How to Build Your First Robot from Scratch on a Limited Budget

A practical guide to choosing a realistic first robot and comparing Arduino, ESP32, Raspberry Pi, Jetson, motors, drivers, sensors, batteries, software, safety, budget and the practical limits of a low-cost robotics project.

Read article

Robotics editorial guides

Start with the robot system, then choose the article

TechniaHQRobot groups robotics coverage around working systems the robot body, the sensor stack, the software layer, the deployment environment and the evidence that a machine can repeat a task outside a polished demo.

Robot software architecture

Understand how ROS 2, SLAM, perception, planning, simulation, safety layers and fleet dashboards fit together in a working robot stack.

Open guide

Robot components and hardware

Compare actuators, reducers, encoders, batteries, controllers, sensors and end effectors through the lens of real deployment limits.

Open guide

Robotics companies by category

Separate humanoid builders, AMR vendors, industrial arm makers, drone teams, medical robotics firms, software platforms and component suppliers.

Open guide

Robotics data collection

Learn what a useful robot dataset records cameras, actions, force, failures, operator interventions, task context and environment changes.

Open guide