
Rice and NASA iMETRO Dynamic Simulation Open-Source Space Robotics for Spacecraft Interiors
The iMETRO simulator matters because space robots need to be tested in tight, human-built interiors before they touch real spacecraft hardware.
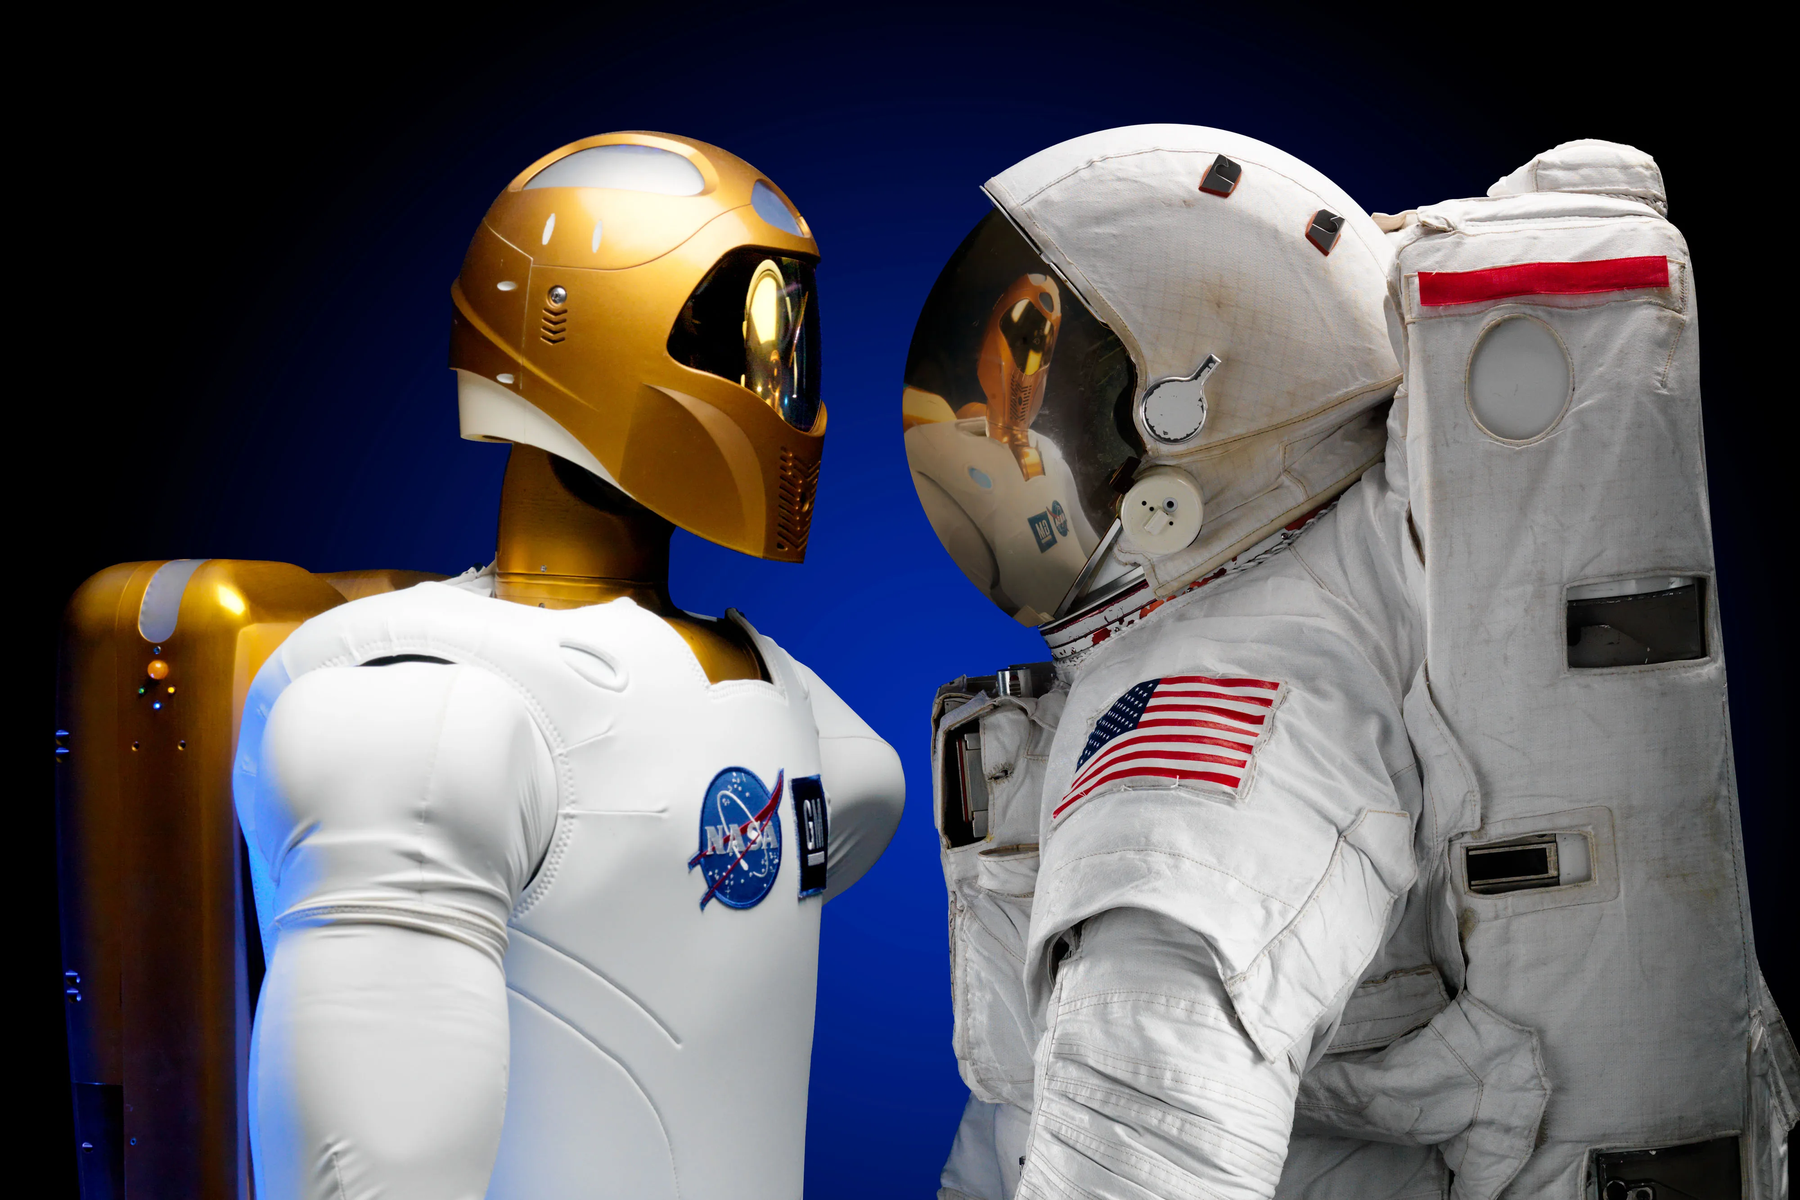
Rice University’s iMETRO simulator studies robots moving and manipulating inside spacecraft. This review covers model fidelity, reproducibility and hardware validation.
The post covers Rice University and NASA’s iMETRO Dynamic Simulation.
The simulator is framed around robots for spacecraft interiors and indoor habitats.
The strongest value is safer, repeatable testing before real hardware deployment.
Simulation results still need real-world validation.
Original X post
Open on XLoading the full X post…
What happened
The TechniaHQRobot post highlights Rice University and NASA’s iMETRO Dynamic Simulation as an open-source robotics simulator for spacecraft interiors. The core idea is to give researchers a digital environment before robots operate around real space hardware.
That matters because space interiors are tight, expensive and unforgiving. A robot that fails in a warehouse can be reset on the floor. A robot that fails inside a spacecraft can threaten hardware, mission time and crew safety.
Why it matters
Space robotics needs simulation because the real environment is hard to access. Researchers need to test navigation, contact, perception and manipulation around walls, handles, storage areas and human-designed constraints.
An open-source simulator can make that work more accessible. It lets more teams build, test and compare approaches without needing direct access to a physical spacecraft mockup.
Technical details
- Robot / Project
- iMETRO Dynamic Simulation
- Company / Lab
- Rice University and NASA Johnson Space Center
- Country
- United States
- Main task
- simulation for robots inside spacecraft and indoor space habitats
- Hardware details
- Example 8-DoF manipulator in a model of NASA’s physical iMETRO test facility
- Sensors
- simulated sensors depend on the model configuration
- Mobility
- simulation can support indoor robotic systems; exact platforms should be checked in project documentation
- Hands / gripper
- platform-specific
- Deployment environment
- spacecraft interiors, space habitats and lab digital twins
- Autonomy level
- simulation and development tool, not a deployed robot by itself
- Confirmed limitations
- simulation cannot replace physical validation in real spacecraft-like conditions
Technical details
The NASA technical report describes a model of the physical iMETRO facility with an example eight-degree-of-freedom manipulator. MuJoCo supplies the dynamic simulation, and ROS 2 hardware-control interfaces connect robot software to the model.
A model-conversion tool lets the same robot models be used in ROS 2 and MuJoCo. This helps compare command paths, geometry and contact behavior before moving an application to the physical testbed.
Use cases
Likely use cases include training indoor space robots, testing navigation inside habitat-like structures, evaluating teleoperation workflows, preparing manipulation tasks and generating repeatable benchmark scenarios.
The strongest early users are researchers, NASA teams and robotics labs working on intravehicular robots, not consumer developers looking for a general robot simulator.
Limitations
Every simulator has a reality gap. Contact, cable behavior, lighting, sensor noise, microgravity effects and human movement can differ from the model. That means simulation can reduce risk but cannot remove physical testing.
The useful standard is whether iMETRO helps teams catch failures earlier and transfer lessons to hardware more safely.
Published transfer test and code access
The authors report transferring an application from simulation to the physical iMETRO facility in less than a day. This is a team-reported testbed result; it provides no measure of reliability on a space mission.
NASA’s report links the simulation resources under NASA-JSC-Robotics. It also identifies ros-controls/mujoco_ros2_control as the current home of the MuJoCo and ROS 2 integration tools. Check each repository’s license, dependencies and hardware assumptions before reuse.
Related robotics context
iMETRO sits beside NASA’s long history with Robonaut, Valkyrie and remote operation research. It also connects to the wider robotics trend before robots can work in dangerous or expensive environments, they need better digital testbeds.
Verification notes
- The example manipulator, software interfaces, repository locations and transfer result were checked against NASA technical report 20260001395 on October 11, 2026. No simulator or hardware trial was run for this article.
Explore the technical topic
Share this article
Share the current TechniaHQRobot article page.
Sources
By @techniahqrobot
About the publication · Sources and editorial policy · Report a correction